# Calculations of Hydrodynamic Cavitation Devices
## Abstract
Hydrodynamic cavitation devices generate controlled vapor and gas vapor
cavities by imposing a local pressure depression followed by pressure
recovery. Reliable design therefore requires more than a single
cavitation threshold or dimensionless index. This article presents a
calculation framework for static, vortex, and dynamic hydrodynamic
cavitation devices and integrates hydraulic sizing, pressure reference
selection, dimensionless analysis, energy input, residence time, cavity
collapse, uncertainty, mechanical integrity, materials selection, scale
translation, and commissioning. Static device calculations address
orifices, nozzles, slits, Venturi passages, bluff bodies, and multistage
arrangements. Vortex device calculations combine tangential inlet sizing
with radial equilibrium screening and finite core limitations. Dynamic
device calculations include rotor tip speed, rotational Reynolds number,
cavitation number, power number, torque, rotor stator clearance, feature
passage frequency, stress, vibration, and thermal growth. Worked
examples demonstrate preliminary sizing for an eight hole orifice plate,
an ideal Venturi throat, a finite core vortex chamber, and a rotor
stator operating point. The analysis emphasizes that local pressure
history, cavity structure, process response, and erosion cannot be
inferred reliably from global pressure drop alone. Calibrated
coefficients, validated computational fluid dynamics, representative
pilot testing, and measured operating maps are required to establish a
defensible design envelope and service life.
## 1 Introduction
Hydrodynamic cavitation occurs when the pressure history experienced by
a flowing liquid permits preexisting nuclei to expand into vapor filled
or gas vapor cavities and subsequently subjects those cavities to
sufficiently rapid pressure recovery. In static devices, this pressure
history is produced by acceleration through a fixed restriction, flow
separation, jet expansion, wake formation, or swirl. In dynamic devices,
rotors, rotor stator clearances, pin arrays, cavities, grooves, or
moving blades repeatedly create regions of reduced pressure followed by
recovery. Although the governing physical principles are common,
calculation procedures cannot be transferred directly among device
families [1–7].
Three recurring design errors should be avoided. First, cavitation
should not be treated as a binary condition. A local pressure below
vapor pressure indicates the potential for vapor formation, but it does
not define cavity population, cloud structure, residence time, collapse
intensity, process response, or erosion rate. Second, the measured
upstream to downstream pressure difference should not be interpreted as
the local minimum pressure. A wall tap averages pressure over a finite
region and may not detect conditions at a vena contracta, separated
shear layer, vortex core, rotor cavity, or transient blade passage.
Third, no single dimensionless group constitutes a complete scale up
criterion. Reynolds number, Euler number, Weber number, cavitation
number, flow coefficient, power number, and residence time each preserve
only part of the coupled system behavior [3–12].
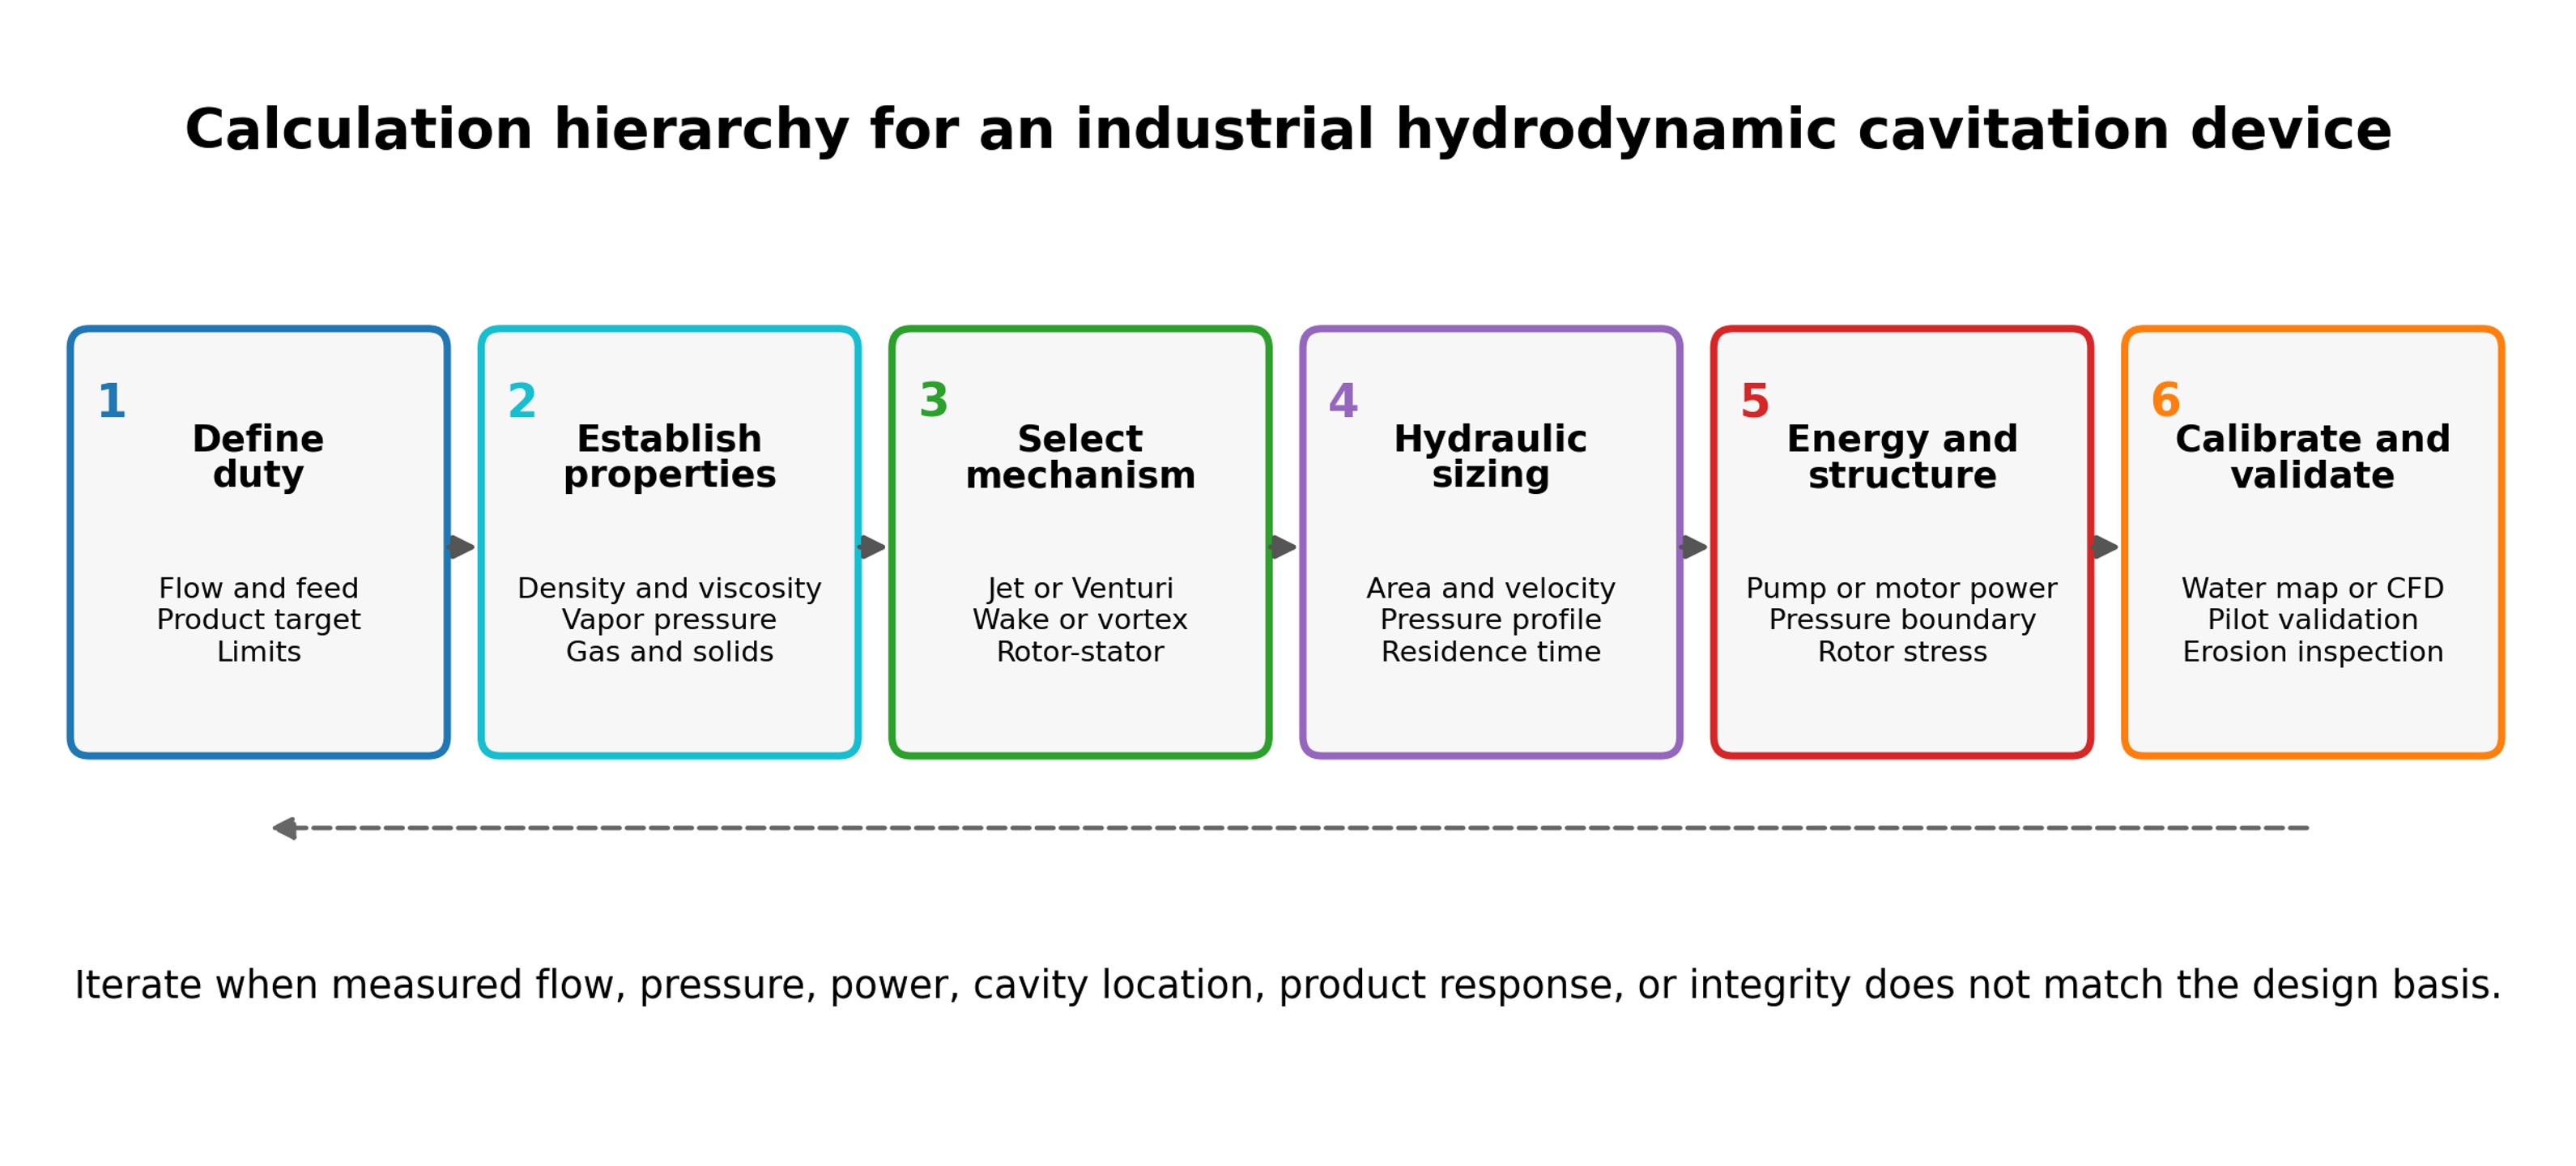
A defensible design calculation is therefore organized into four levels.
The first level is a transparent one dimensional or lumped parameter
screening model that establishes required flow area, mean velocity,
pressure drop, power, nominal residence time, pressure boundary load,
and a preliminary cavitation regime. The second level applies calibrated
discharge, loss, recovery, power, or circulation coefficients obtained
from water testing or a geometrically similar device. The third level
uses validated computational fluid dynamics when local pressure, vapor
fraction, recirculation, or rotor stator interaction cannot be
represented adequately by a lumped model. The fourth level is pilot
confirmation in the actual process fluid because viscosity, vapor
pressure, dissolved gas, suspended solids, non Newtonian behavior,
interfacial tension, reaction kinetics, and contamination limits can
shift the useful operating window [5, 7, 10–15].
Figure 1.1. Calculation hierarchy for an industrial hydrodynamic cavitation device [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 1.1](#figure-1-1). Calculation hierarchy for an industrial hydrodynamic cavitation device [32].*
The objective of the calculation is not to predict every individual
bubble. It is to establish a traceable design basis and identify the
assumptions that require calibration or experimental confirmation. The
calculation record should answer the following questions:
- What flow rate and feed property envelope must be processed?
- Which absolute pressure is expected at the active cavitation location?
- Where will cavities grow, and where should they collapse?
- What pump or motor power is required at the selected operating point?
- What exposure, residence time, number of stages, or number of passes
is delivered?
- Which part is the pressure boundary, which part is a wear insert, and
which parts must be hygienic or chemically inert?
- How will the hydraulic state, product response, erosion,
contamination, and uncertainty be verified?
This article uses SI units unless stated otherwise. All pressures used
in vapor pressure and cavitation number calculations are absolute. Gauge
pressure is used only after explicit conversion. Correlations should not
be transferred between geometries without a stated technical basis, and
calculated values should be reported with sufficient significant figures
for reproducibility without implying unrealistic precision.
## 2 Calculation Basis and Design Workflow
This section defines the consolidated calculation and reporting
framework used throughout the article. Subsequent sections apply
consistent definitions for absolute pressure, cavitation number,
hydraulic and electrical energy, residence time, exposure, uncertainty,
and scale translation. Equations are repeated only when a specialized
derivation or interpretation is required.
### 2.1 Required design inputs
The calculation begins with the process duty rather than a preferred
device configuration. The minimum data set in Table 2.1 separates
properties required for hydraulic sizing from variables required for
process validation and mechanical design. A single nominal density and
viscosity are insufficient when temperature, composition, gas content,
or solids loading varies during operation.
*Table 2.1. Minimum design inputs for hydrodynamic cavitation
calculations.*
| **Category** | **Required information** | **Calculation affected** |
|-----------------------|----------------------------------------------------------------------------------------------------------------------|---------------------------------------------------------------------------|
| Capacity | Minimum, normal, and maximum volumetric or mass flow; batch and loop volume; required turndown | Flow area, velocity, pump or motor size, residence time, parallel modules |
| Pressure | Suction pressure, upstream pressure, downstream pressure, backpressure, allowable pressure drop, relief set pressure | Local pressure screen, cavitation number, pressure boundary, pump duty |
| Temperature | Minimum, normal, and maximum temperature; allowable temperature rise | Density, viscosity, vapor pressure, seal compatibility, thermal growth |
| Liquid properties | Density, dynamic viscosity, vapor pressure, speed of sound, surface tension where relevant | Reynolds number, cavitation inception, collapse, pressure transients |
| Multiphase properties | Gas content, gas solubility, solids loading and size, dispersed phase fraction, rheology | Nucleation, blockage, wear, phase separation, model selection |
| Product objective | Reaction conversion, droplet or particle distribution, cell disruption, contaminant removal, heating, gas dispersion | Required exposure, passes, energy, sampling and acceptance limits |
| Geometry constraints | Pipe size, available length, cleanability, minimum passage, allowable rotor diameter and clearance | Device family, throat or hole size, diffuser length, rotor layout |
| Materials environment | pH, chloride, oxidants, solvents, acids, caustic, abrasive solids, hygiene requirements | Alloy, coating, elastomer, corrosion allowance, surface finish |
| Utilities | Electrical supply, pump curve, cooling duty, nitrogen or gas injection, instrumentation | Installed power, control strategy, heat exchanger and interlocks |
| Reliability | Inspection interval, permitted metal contamination, spare strategy, acceptable downtime | Replaceable inserts, erosion allowance, monitoring and lifecycle cost |
Material properties should be evaluated at each relevant operating
state. For water like liquids, vapor pressure changes rapidly with
temperature and can dominate the cavitation margin. For viscous oils,
concentrated suspensions, polymer solutions, and emulsions, apparent
viscosity may be shear dependent and pressure losses outside the
cavitation element may no longer be negligible. The design envelope
should therefore include startup, shutdown, cleaning, upset, and maximum
temperature conditions rather than only the nominal process state.
### 2.2 Pressure references and measurement stations
Pressure must be placed on an absolute basis before it is compared with
vapor pressure:
(2.1)
where is absolute pressure, is gauge pressure, and
is local atmospheric pressure. A vacuum gauge reading requires
the corresponding sign convention. Barometric variation is usually small
relative to a high pressure device, but it can be important in low
pressure systems and suction calculations.
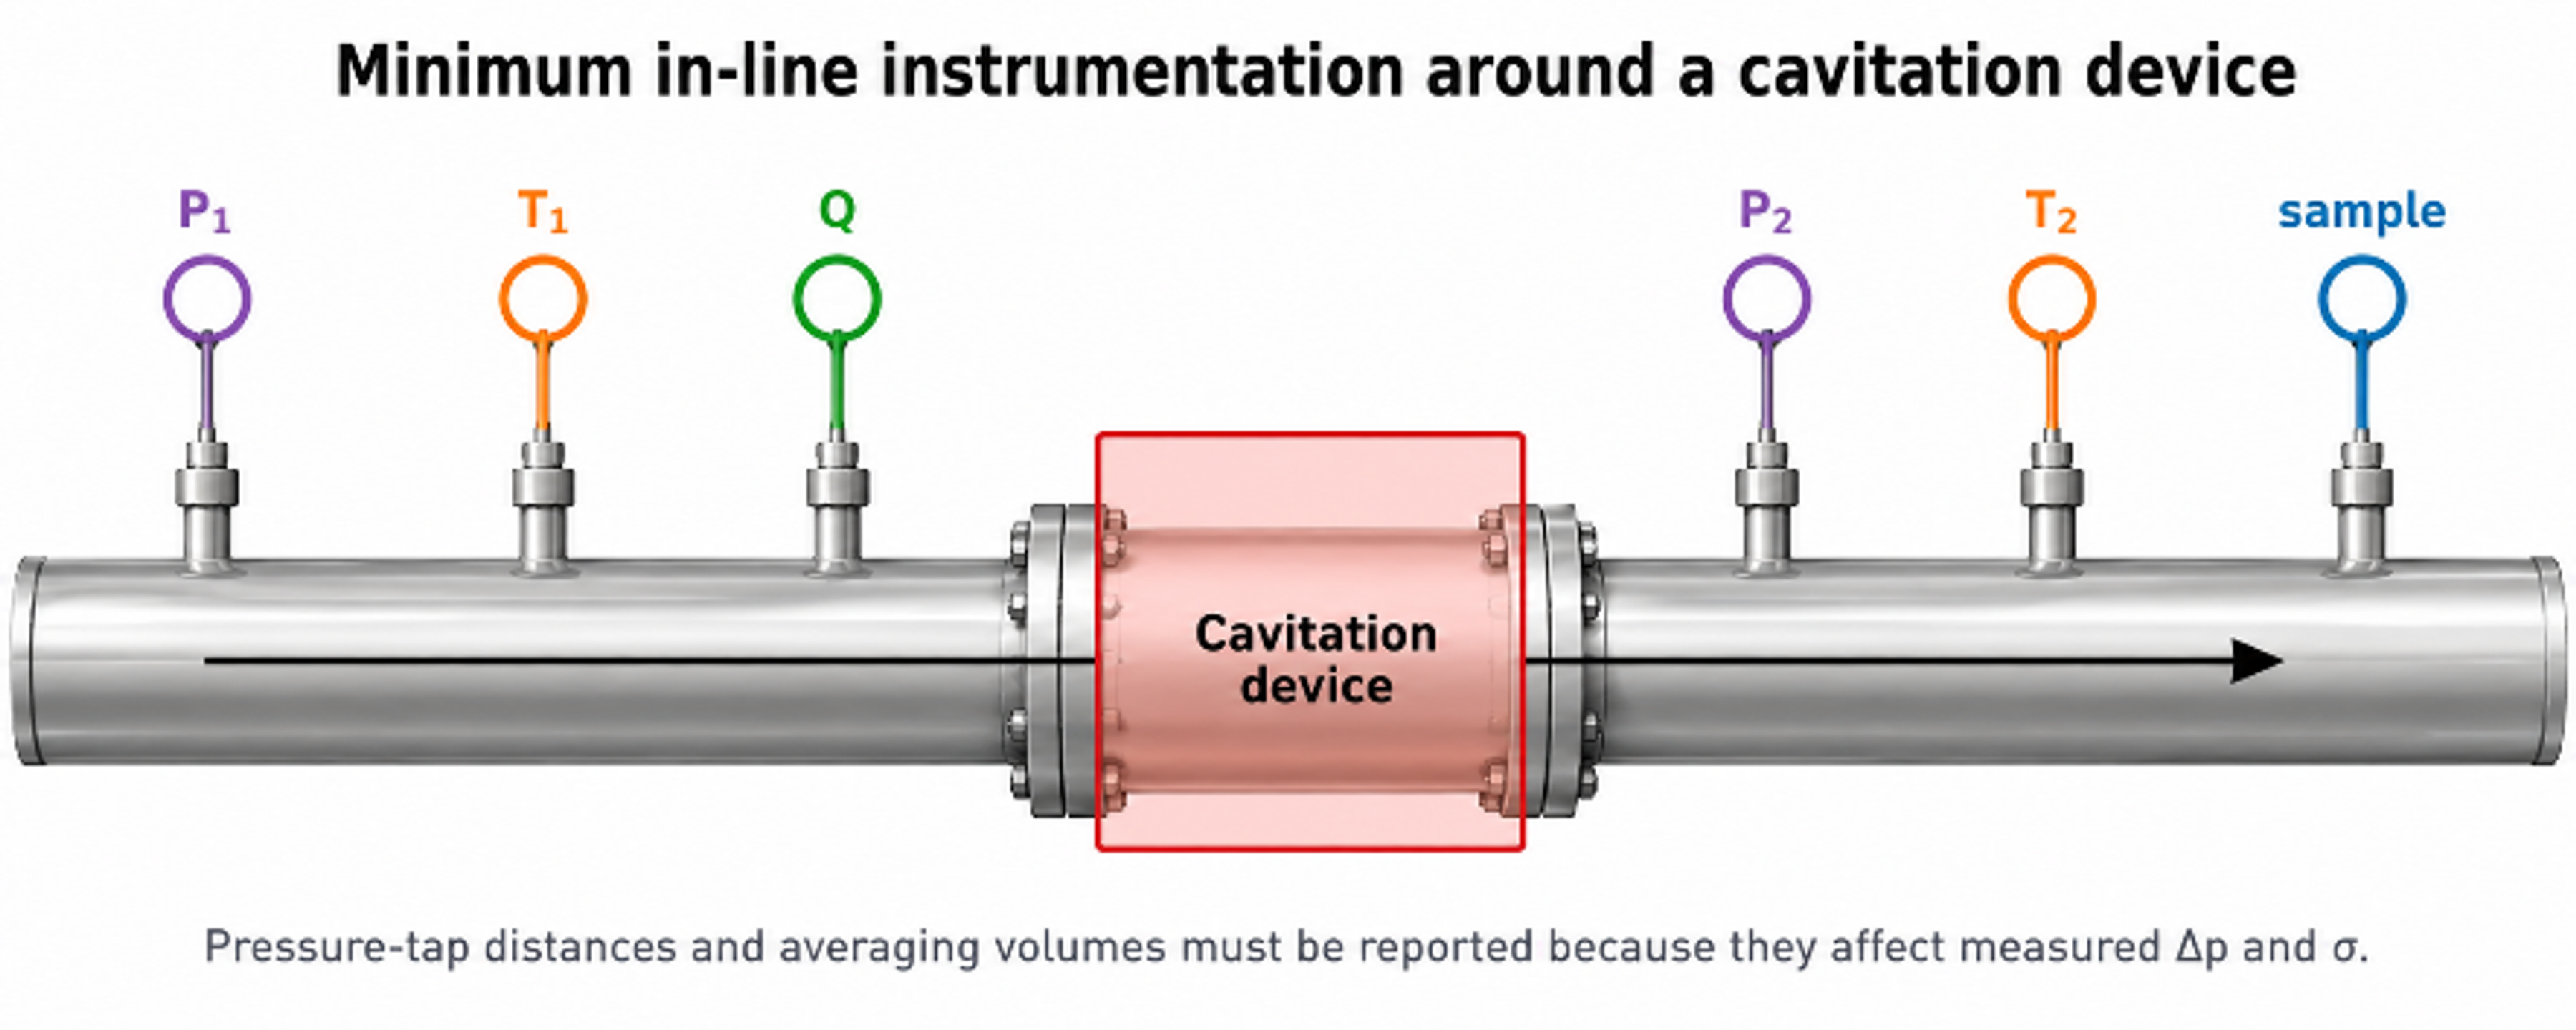
The instrumentation arrangement should establish reproducible pressure
stations upstream and downstream of the cavitation element while
recognizing that these taps do not normally measure the local minimum
pressure. Rapid pressure pulsation may require high frequency
transducers in addition to conventional process transmitters. Tap
diameter, distance from the element, pipe diameter, straight length,
tubing volume, transducer range, and sampling frequency should be
documented [2,4–6].
Figure 2.1. Minimum instrumentation around the flow through cavitation element [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 2.1](#figure-2-1). Minimum instrumentation around the flow through cavitation element [32].*
For an incompressible stream, volumetric flow and mass flow are:
(2.2)
(2.3)
where is volumetric flow rate, is cross sectional area,
is mean velocity, is mass flow rate, and is
density.
A practical mechanical energy balance between stations 1 and 2 is:
(2.4)
where is gravitational acceleration, is elevation, is
head added by a pump within the control volume, is irreversible
head loss, and is the kinetic energy correction factor. For a
short horizontal element with no pump between the taps, the elevation
and pump terms are omitted. The equation remains an averaged energy
balance; it does not resolve the local pressure depression inside a
separated, swirling, or transient flow.
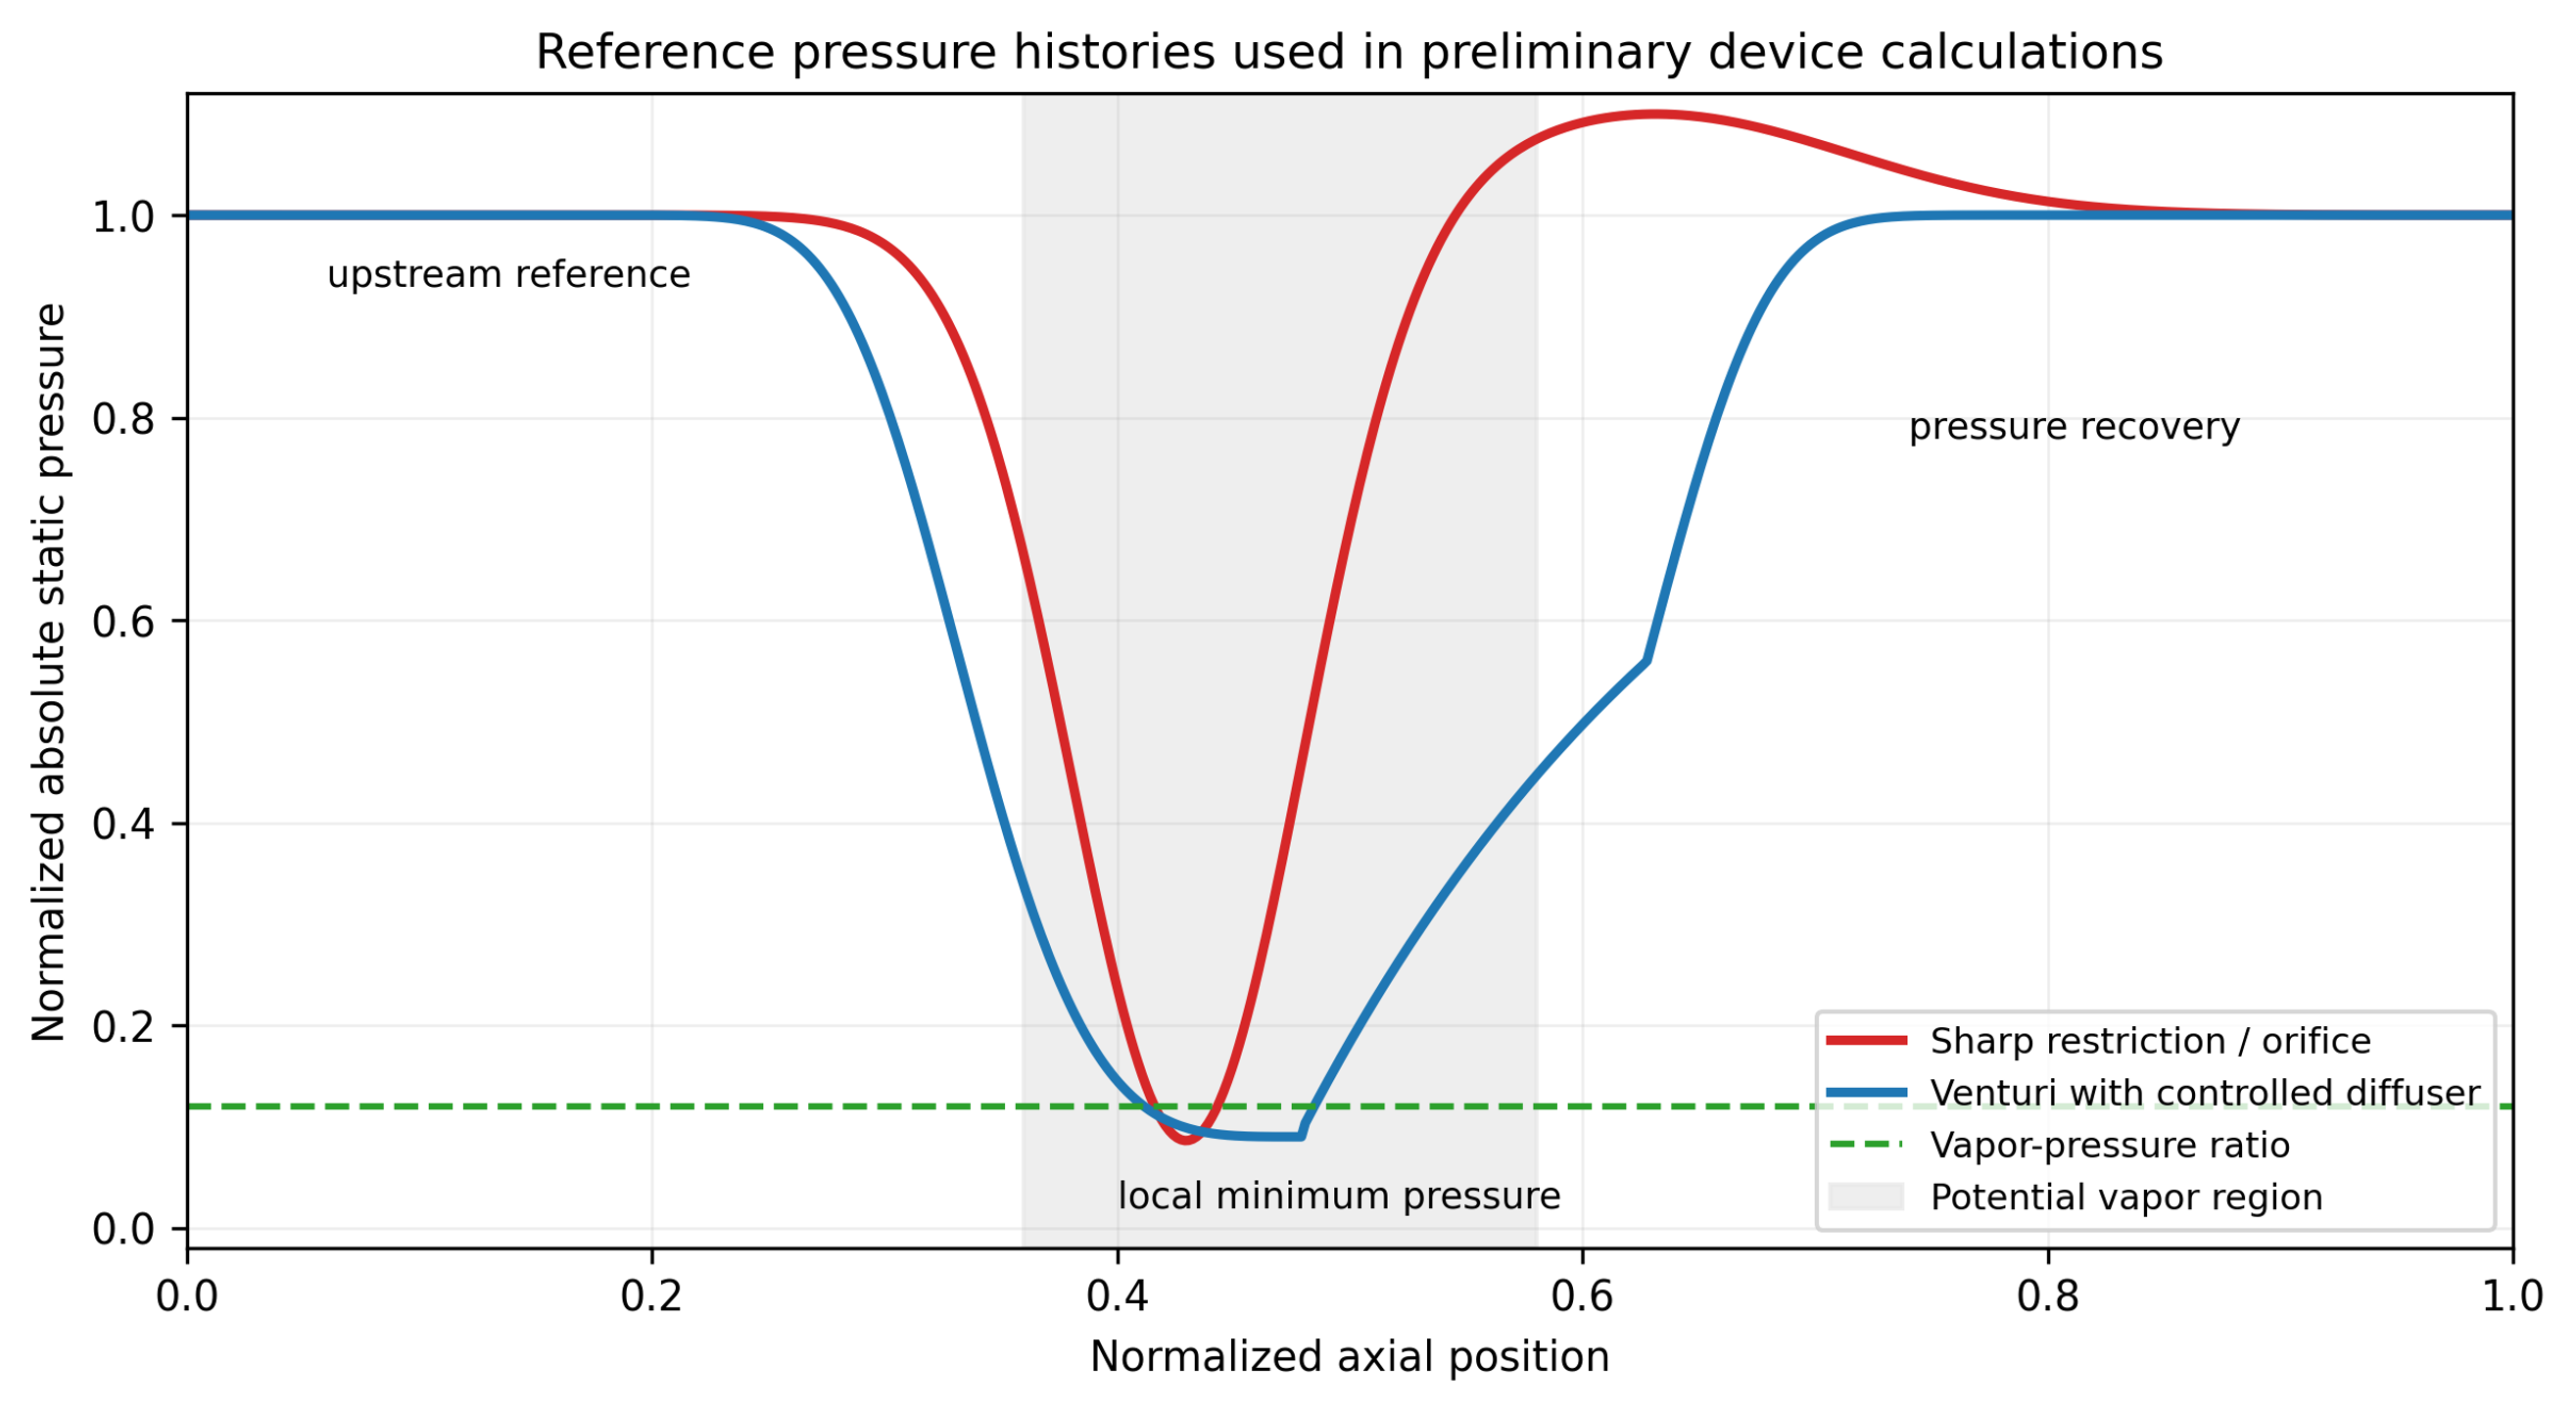
[Figure 2.2](#figure-2-2) illustrates the importance of local pressure history. A sharp
restriction may generate a short, steep pressure minimum followed by
highly dissipative recovery, whereas a well designed Venturi can provide
a longer low pressure region with more controlled recovery. These
conceptual profiles do not replace calibrated pressure measurements, but
they inform throat length, diffuser geometry, and the placement of
downstream surfaces.
Figure 2.2. Conceptual absolute pressure histories for a sharp restriction and a Venturi with controlled recovery [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 2.2](#figure-2-2). Conceptual absolute pressure histories for a sharp restriction and a Venturi with controlled recovery [32].*
### 2.3 Dimensionless groups
The Reynolds number based on a stated characteristic length and
velocity is:
(2.5)
where is dynamic viscosity. The Euler number, written here as a
pressure loss coefficient, is
(2.6)
The Weber number is:
(2.7)
where is surface or interfacial tension. For two phase
dispersions, the relevant interfacial tension and characteristic droplet
or jet dimension must be specified.
The general cavitation number is:
(2.8)
where and are explicitly defined reference pressure
and velocity, and is vapor pressure at the local temperature.
Published values are not comparable unless the reference stations and
velocity definition are the same. For an orifice study, may be
downstream pressure and the jet velocity; for a Venturi it may
be throat or downstream pressure and throat velocity; for a rotor it may
be chamber pressure and rotor tip speed [2–6].
A pressure drop cavitation index frequently used in flow through
equipment is:
(2.9)
where and are stated upstream and downstream absolute
pressures. This form is convenient because the denominator is measured
pressure drop, but it still does not resolve the local minimum pressure.
It should be treated as an operating index tied to the test geometry.
The preliminary vapor formation criterion is:
(2.10)
and a preliminary collapse criterion is:
(2.11)
where is the calculated or modeled local minimum pressure and
is the pressure in the intended recovery region. Inception can
occur above equilibrium vapor pressure because of gas nuclei and
unsteady pressure, while a cavity can persist after the mean pressure
has recovered. Equations (2.10) and (2.11) are therefore screening
conditions rather than exact phase boundary laws [1–3].
*Table 2.2. Interpretation and limitations of principal similarity
groups.*
| **Group** | **Principal comparison** | **Must be defined** | **Important limitation** |
|------------|--------------------------------------------------------|------------------------------------------|--------------------------------------------------------------------------------|
| | Inertia relative to viscosity | Velocity and length scale | Does not preserve nuclei, vapor fraction, collapse location, or residence time |
| | Pressure change relative to dynamic pressure | Pressure stations and velocity | Can global pressure loss match while local pressure fields differ |
| | Inertia relative to surface or interfacial tension | Interface and length scale | Relevant to breakup, but not sufficient for recoalescence or chemistry |
| | Pressure margin above vapor pressure | Absolute pressure and velocity reference | Definition varies by device; one value cannot describe a full pressure history |
| | Downstream pressure margin normalized by measured loss | Upstream and downstream taps | Does not directly measure vena contracta, core, or blade passage pressure |
| | Unsteady frequency relative to convection | Characteristic frequency and length | Frequency similarity does not guarantee the same vapor cloud amplitude |
| | Shaft power is relative to rotational inertial scale | Shaft power, speed, rotor diameter | Geometry, clearance, flow coefficient, and gas fraction must remain comparable |
### 2.4 Hydraulic power, electrical power, residence time, and dose
The hydraulic power associated with a measured pressure drop is:
(2.12)
For a pump driven static device, the approximate electrical input
assigned to the cavitation duty is:
(2.13)
where is pump efficiency, is motor efficiency, and
represents drive or transmission efficiency. For a complete
system assessment, auxiliary loads, recirculation losses, cooling, and
control equipment should be included. Measured electrical power is
preferred over nameplate power.
The single pass hydraulic specific energy is:
(2.14)
and the corresponding mass specific electrical energy over a treatment
interval is:
(2.15)
A short device volume has nominal residence time:
(2.16)
For a well mixed recirculation tank of volume , the nominal
number of loop turnovers during time is:
(2.17)
This turnover count does not guarantee that each fluid element has
passed through the device exactly times. A real loop has a
residence time distribution, short circuiting, dead volume, and mixing
effects. For comparison of process results, the report should include
the tank volume, external piping volume, device hold up, flow history,
sample location, and whether the product is withdrawn continuously or
only after recirculation [2–5].
### 2.5 Collapse time and placement of the recovery zone
A useful inertial estimate for the collapse time of an initially
spherical vapor cavity of radius under a constant pressure
difference is the Rayleigh expression:
(2.18)
where is the recovered far field pressure. The
corresponding convective distance is:
(2.19)
where is a representative convection velocity. These equations
do not include dissolved gas, thermal effects, non spherical collapse,
cloud interaction, or wall proximity, but they help place a replaceable
collapse chamber, avoid a vulnerable weld, and estimate whether a long
low pressure zone will carry cavities beyond the intended active region
[1,2].
For example, a water vapor cavity with mm exposed to a
recovered pressure difference of 200 kPa has an inertial collapse time
of approximately 32 microseconds. At a convection velocity of 12 m/s,
the corresponding distance is approximately 0.38 mm. Real clouds can
persist much farther because of gas content, collective shielding,
repeated growth, and spatially distributed pressure recovery. The
calculation is therefore a lower order location screen, not an erosion
life prediction.
### 2.6 Uncertainty and model hierarchy
For a result with
independent input uncertainties, the first order combined standard
uncertainty is:
(2.20)
where is the standard uncertainty of input .
Correlated variables require covariance terms. A design calculation
should separate measurement uncertainty from model form uncertainty. The
latter includes uncertainty in discharge coefficient, pressure recovery
coefficient, vortex core model, power number, two phase closure, and the
relationship between hydraulic state and product response.
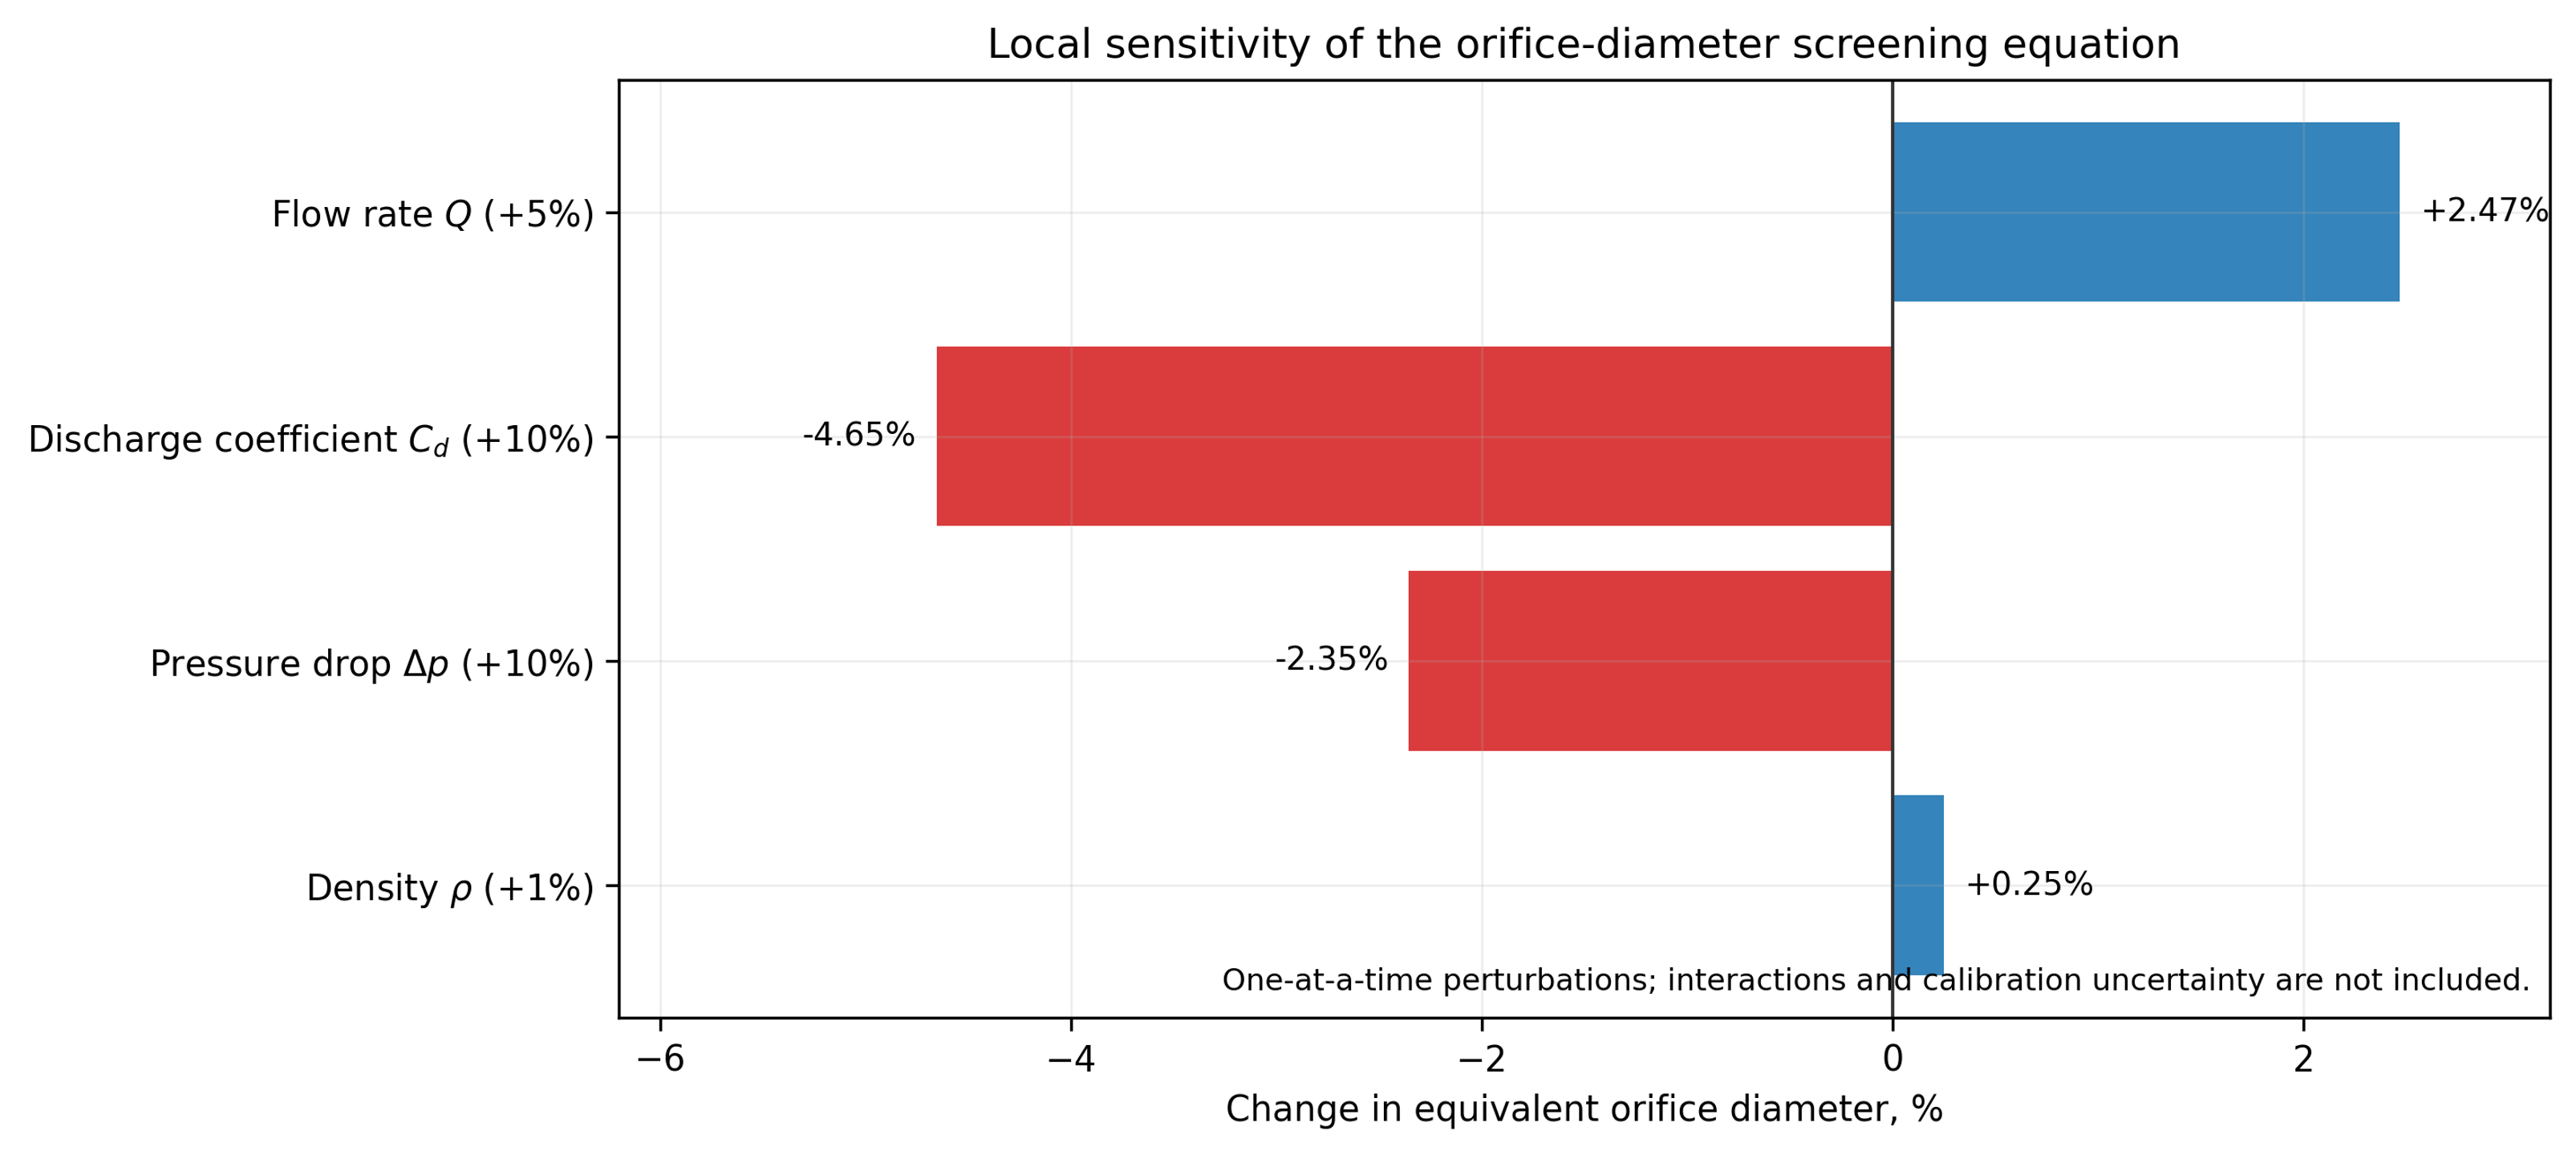
Figure 2.3. Local sensitivity of the preliminary orifice diameter equation to representative input perturbations. The result illustrates parameter sensitivity and does not include model form or interaction uncertainty [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 2.3](#figure-2-3). Local sensitivity of the preliminary orifice diameter equation to representative input perturbations. The result illustrates parameter sensitivity and does not include model form or interaction uncertainty [32].*
*Table 2.3. Recommended model fidelity by design question.*
| **Design question** | **Minimum method** | **Escalation trigger** | **Validation evidence** |
|--------------------------------------|------------------------------------------------------------|-------------------------------------------------------------------------------------|--------------------------------------------------------------------------|
| Required open area and pump pressure | One dimensional continuity and calibrated loss coefficient | Non Newtonian flow, gas fraction, severe choking, uncertain | Flow pressure curve at operating temperature |
| Local cavitation inception | Pressure screen plus calibrated inception map | Geometry has separation, vortex core, multiple jets, or transient rotor interaction | Visualization, acoustic signature, high speed pressure, or validated CFD |
| Cavity extent and collapse location | Empirical map or two phase CFD | Erosion sensitive surface, reaction selectivity, scale change | Imaging, erosion coupons, hydrophone or pressure mapping |
| Rotor power | Calibrated , torque measurement, motor map | Clearance, flow coefficient, gas fraction, or rheology changes | Shaft torque and electrical power over full operating map |
| Product performance | Empirical response surface | Composition, temperature, or scale differs from test | Replicated pilot trials and product analysis |
| Erosion life | Comparative material tests and pilot inserts | Long service interval, toxic metal limit, corrosive abrasive fluid | Periodic mass/thickness loss and contaminant analysis |
The dominant uncertainty is often not the pressure measurement itself
but the assumption that a hydraulic index predicts the required process
response. A pilot program should therefore map hydraulic variables and
product attributes concurrently. A model should be accepted only within
the region where measured flow, pressure, power, temperature, cavity
signature, process response, and equipment integrity remain mutually
consistent.
## 3 Calculations for Static Hydrodynamic Cavitation Devices
Static hydrodynamic cavitation devices contain no moving cavitation
generating element. Pump pressure energy is converted into local kinetic
energy, separated flow, vortex motion, and irreversible pressure
recovery. Principal calculation families include fixed restrictions such
as orifices, nozzles, slit plates, and perforated inserts; Venturi and
converging diverging passages; bluff bodies and jet impingement
elements; and multistage combinations. Vortex chambers are mechanically
static but are treated separately in Section 4 because their calculation
method is distinct.
Static devices offer simple pressure containment, eliminate rotating
seals, permit replaceable inserts, and integrate directly into
pipelines. Their limitations include pump power demand, possible
clogging, sensitivity to edge condition and fouling, and the possibility
that attached cavities collapse near a wall. Static sizing should
therefore determine both nominal hydraulic resistance and the intended
locations of pressure depression and recovery [2–6].
### 3.1 Flow through orifice, nozzle, and slit devices
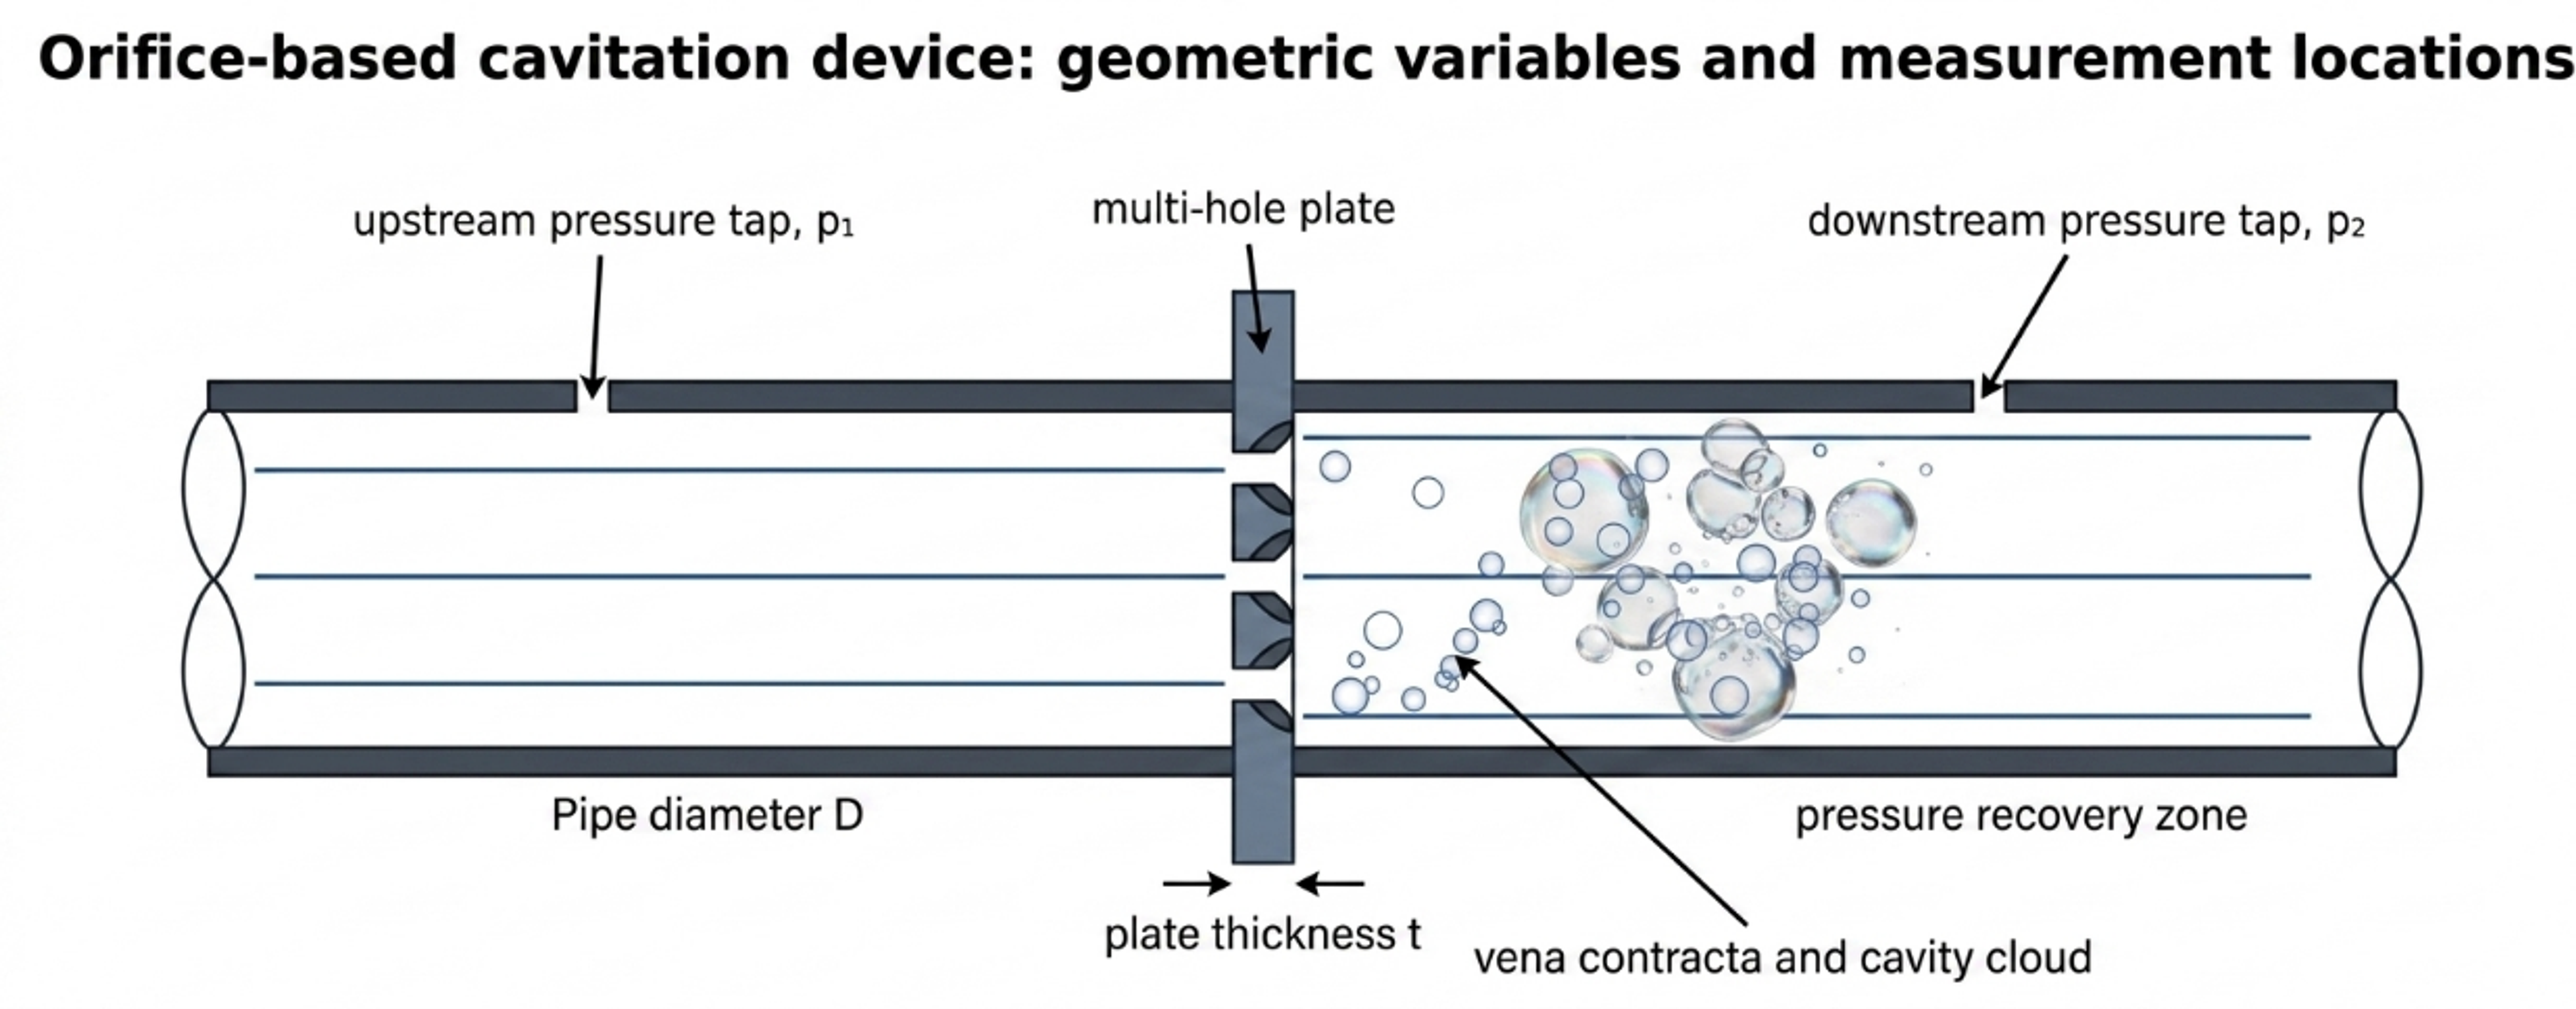
An orifice device divides the flow among one or more apertures. A sharp
edged opening produces a contracted jet downstream of the physical
aperture, and the minimum pressure commonly occurs near the vena
contracta rather than at the downstream pressure tap. A rounded nozzle
reduces separation and can shift inception and recovery. A slit provides
a high perimeter to area ratio and can form a sheet like cavitation
region, but it may be more sensitive to deformation, solids, and edge
wear. Multi hole plates distribute flow among multiple jets and can
increase the number of active regions; however, jet interaction,
ligament thickness, plate thickness, and downstream chamber diameter
become integral design variables [2,4–6].
Figure 3.1. Flow through orifice geometry, principal dimensions, and pressure stations [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 3.1](#figure-3-1). Flow through orifice geometry, principal dimensions, and pressure stations [32].*
For an incompressible liquid, the basic calibrated relation is:
(3.1)
where is the discharge coefficient, is total open area,
and is the pressure difference associated with the stated
measurement stations. Rearrangement gives the required total area:
(3.2)
For equal circular holes,
(3.3)
where is individual hole diameter. The nominal mean jet velocity
based on the physical open area is:
(3.4)
and the hole Reynolds number is:
(3.5)
Two geometric ratios should be reported. The total open area fraction
is:
(3.6)
where is pipe cross sectional area. The equivalent diameter
ratio is:
(3.7)
where is pipe diameter and is the diameter of one
circular opening having the same total area. For a multi hole plate,
does not describe hole spacing, jet interaction, or minimum
ligament. The individual ratio should also be reported.
The vena contracta area can be written , where
is the contraction coefficient. A one dimensional pressure
screen is:
(3.8)
where represents irreversible loss
accumulated before the vena contracta. Both and the local loss
are geometry dependent. Equation (3.8) is useful for identifying whether
the selected pressure drop can plausibly reach vapor pressure, but the
result should not be presented as a measured minimum pressure unless it
has been calibrated.
The pressure loss corresponding to the calibrated orifice relation is:
(3.9)
This quadratic dependence means that flow redistribution, fouling, edge
damage, or partial blockage can change pressure drop sharply. A
differential pressure alarm is therefore useful for both process control
and condition monitoring.
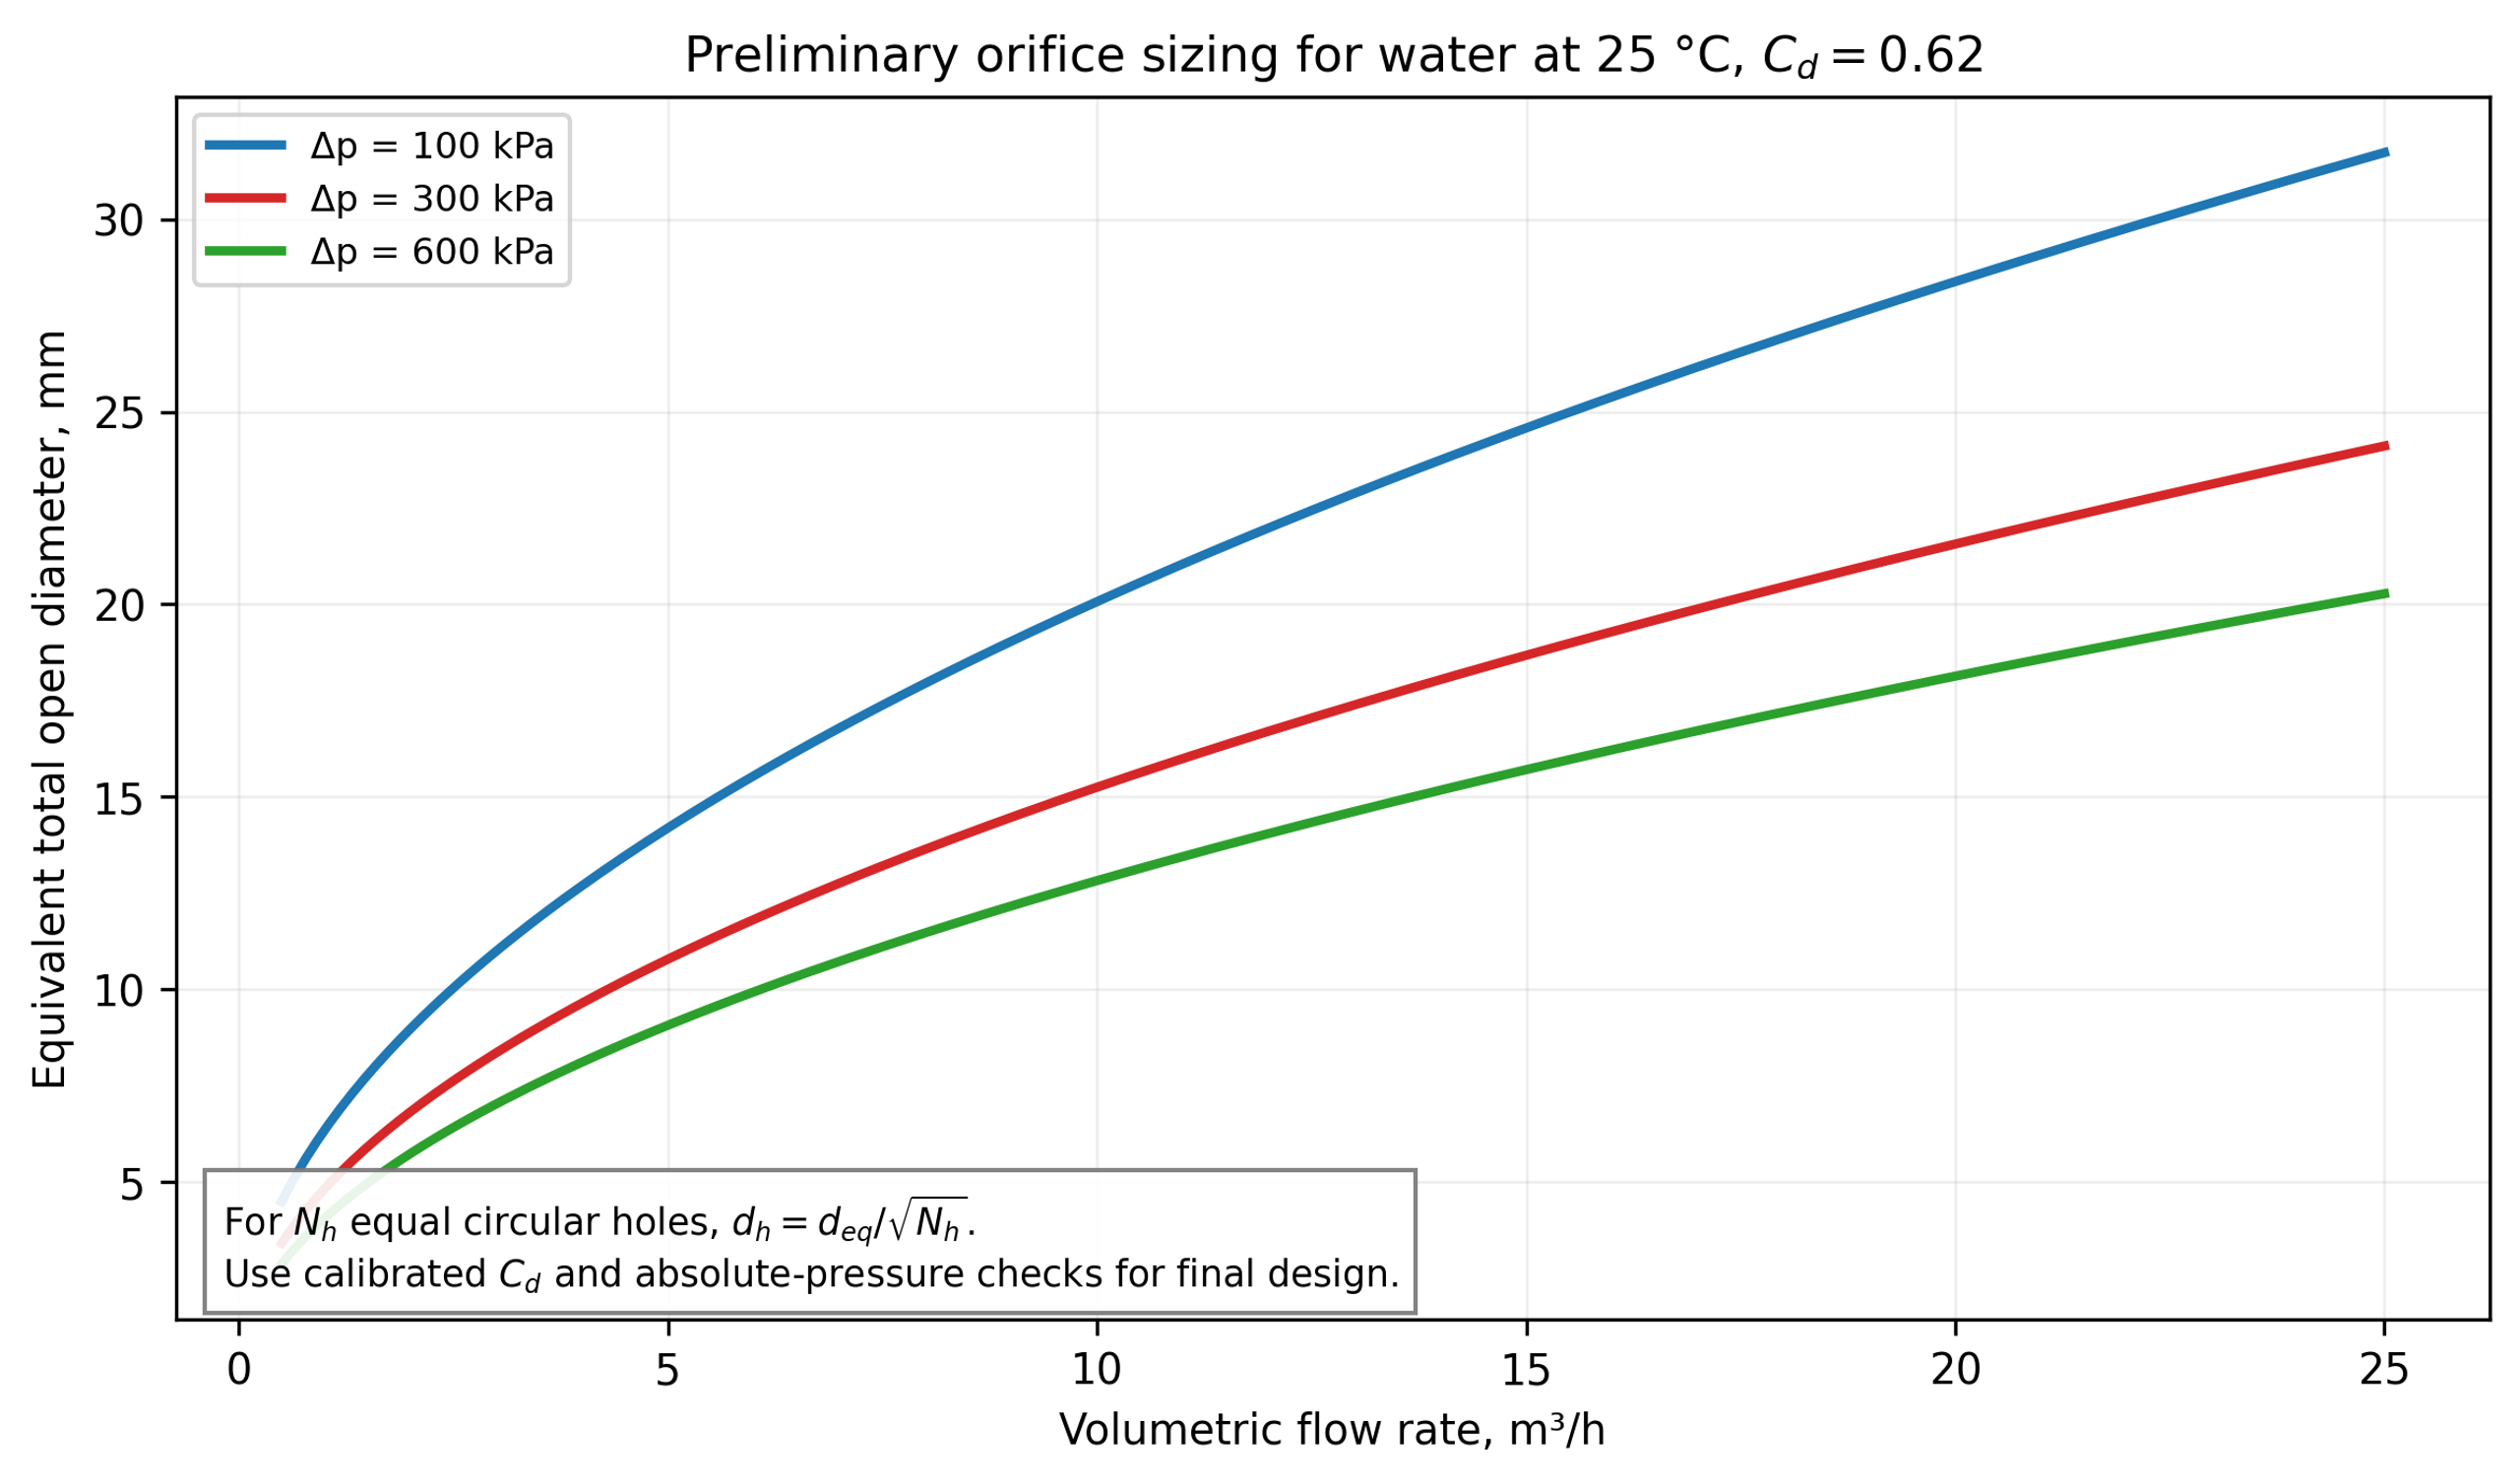
Figure 3.2. Equivalent total open diameter versus water flow for three pressure drops using a preliminary discharge coefficient C_d = 0.62 [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 3.2](#figure-3-2). Equivalent total open diameter versus water flow for three pressure drops using a preliminary discharge coefficient C_d = 0.62 [32].*
#### Selection and calibration of the discharge coefficient
The discharge coefficient is not a material constant. It represents
contraction and energy loss and depends on Reynolds number, plate
thickness to hole ratio, inlet edge radius, chamfer, hole shape, surface
roughness, interaction among multiple holes, upstream velocity profile,
and pressure tap arrangement. Standard differential pressure flow meter
correlations such as ISO 5167 provide useful references for specified
metering geometries, but a cavitating process insert may operate outside
their validated geometry and flow regime [15, 16]. The recommended
procedure is:
- Calculate a preliminary area using a conservative coefficient range.
- Fabricate a replaceable insert with measured dimensions and edge
finish.
- Obtain a non cavitating water flow pressure curve over the intended
Reynolds number range.
- Fit or a direct loss correlation using the exact pressure
stations.
- Increase temperature or reduce backpressure to map cavitation
inception and developed regimes.
- Repeat in the process fluid and check for viscosity, gas, solids, and
rheology effects.
A pressure flow fit is more useful than a single coefficient because it
reveals regime changes. If inferred from Equation (3.1) changes
abruptly, the cause may be two phase choking, gas release, flow
redistribution among holes, measurement dynamics, or a transition in the
cavity structure.
#### Hole pattern and mechanical limits
A multi hole calculation must include more than total open area. Minimum
hole diameter should be checked against the largest credible solid,
fiber, agglomerate, crystal, or cleaning debris. The plate should retain
adequate ligament between adjacent holes and between each hole and the
outer sealing diameter. Plate bending, differential pressure, thermal
shock, fatigue, and stress concentration around openings must be
evaluated according to the applicable pressure code and fabrication
standard. A thin sharp edge can produce a repeatable separated jet but
is more susceptible to erosion and deformation; a thicker insert is
mechanically stronger but alters the jet and may behave as a short tube.
For sanitary service, holes and downstream chambers must be inspectable
and cleanable. A nominally self cleaning high velocity opening can still
retain fibrous solids, crystallized salts, gums, or product in a low
velocity recess. Hydraulic design should therefore be coordinated with
drainability, clean in place velocity, gasket intrusion, and provision
for a bypass or removable cartridge.
*Table 3.1. Variables required to define a flow through restriction.*
| **Variable** | **Symbol or description** | **Design significance** |
|------------------------------|-------------------------------------------|---------------------------------------------------------------|
| Pipe and chamber diameter | , | Upstream velocity, expansion ratio, recovery, jet interaction |
| Number and shape of openings | ; circular, slit, annular, conical | Distribution of jets, perimeter, blockage and cleanability |
| Opening dimension | , slit width and length | Velocity, Reynolds number, minimum particle clearance |
| Total open area | | Primary flow pressure sizing variable |
| Plate or insert thickness | | Short tube behavior, strength, erosion path |
| Edge radius or chamfer | and angle | Separation and contraction coefficient |
| Hole pitch and ligament | , | Jet interaction, plate stress, manufacturability |
| Downstream standoff | | Collapse location relative to wall, baffle, or next stage |
| Pressure tap locations | , | Reproducibility of , , and |
| Surface finish and material | roughness, alloy, coating | Inception, fouling, erosion, contamination |
#### Worked Example 3.1: eight hole orifice plate
Design basis. Water at 25 °C is processed at m³/h through a
40 mm internal diameter pipe. The selected measured pressure drop is 300
kPa. A preliminary discharge coefficient of 0.62 is used for sizing. The
downstream reference pressure is absolute 150 kPa. Eight equal circular
holes are selected. Water properties are kg/m³,
Pa·s, and kPa absolute.
Equation (3.2) gives:
The equivalent single opening is 10.78 mm in diameter. Equation (3.3)
gives an individual hole diameter of 3.81 mm. The nominal jet velocity
from Equation (3.4) is 15.21 m/s, and Equation (3.5) gives
. The pipe area is
m², so the total open area fraction is 0.0727. The ratio of each hole
diameter to pipe diameter is 0.0953; the equivalent total diameter ratio
is 0.2695.
The hydraulic power from Equation (2.12) is 416.7 W. If the aggregate
pump, motor, and drive efficiency is 0.65, the assigned electrical input
from Equation (2.13) is approximately 641 W. The single hydraulic energy
pass from Equation (2.14) is 300.9 J/kg, equivalent to 0.0836 kWh per
metric ton. Using downstream pressure and nominal jet velocity in
Equation (2.8) gives . This value is only a defined
operating index; the vena contracta pressure may be much lower than the
downstream tap pressure.
*Table 3.2. Worked Example 3.1 results.*
| **Quantity** | **Value** | **Design interpretation** |
|------------------------------|------------------------|-----------------------------------------------------------------------------------------------|
| Flow rate | 5.00 m³/h | Normal operating point; turndown and maximum flow also require checks |
| Measured pressure drop | 300 kPa | Determines pump duty and calibrated flow relation |
| Total open area | 91.3 mm² | Preliminary value using |
| Number of holes | 8 | Must be coordinated with pitch and ligament |
| Individual hole diameter | 3.81 mm | Verify solids clearance, tolerance, and erosion allowance |
| Nominal jet velocity | 15.21 m/s | Physical area velocity, not vena contracta velocity |
| Hole Reynolds number | | Turbulent screening condition |
| Total open area fraction | 7.27% | Strong contraction and downstream expansion |
| Hydraulic power | 0.417 kW | Power transferred across the measured pressure drop |
| Estimated electrical power | 0.641 kW | Uses aggregate efficiency 0.65; verify by measured input |
| Single pass hydraulic energy | 300.9 J/kg | Does not specify the fraction delivered as useful collapse energy |
| Defined cavitation number | 1.27 | Based on kPa absolute and ; not directly comparable to other definitions |
This example is a preliminary hydraulic size, not a final plate drawing.
Final design requires the flow pressure curve, absolute inlet and outlet
pressures, hole tolerance, edge profile, plate stress, gasket and flange
details, pressure relief, minimum passage, and a cavitation map. The
example also illustrates why a device can have modest total power yet a
severe local pressure history
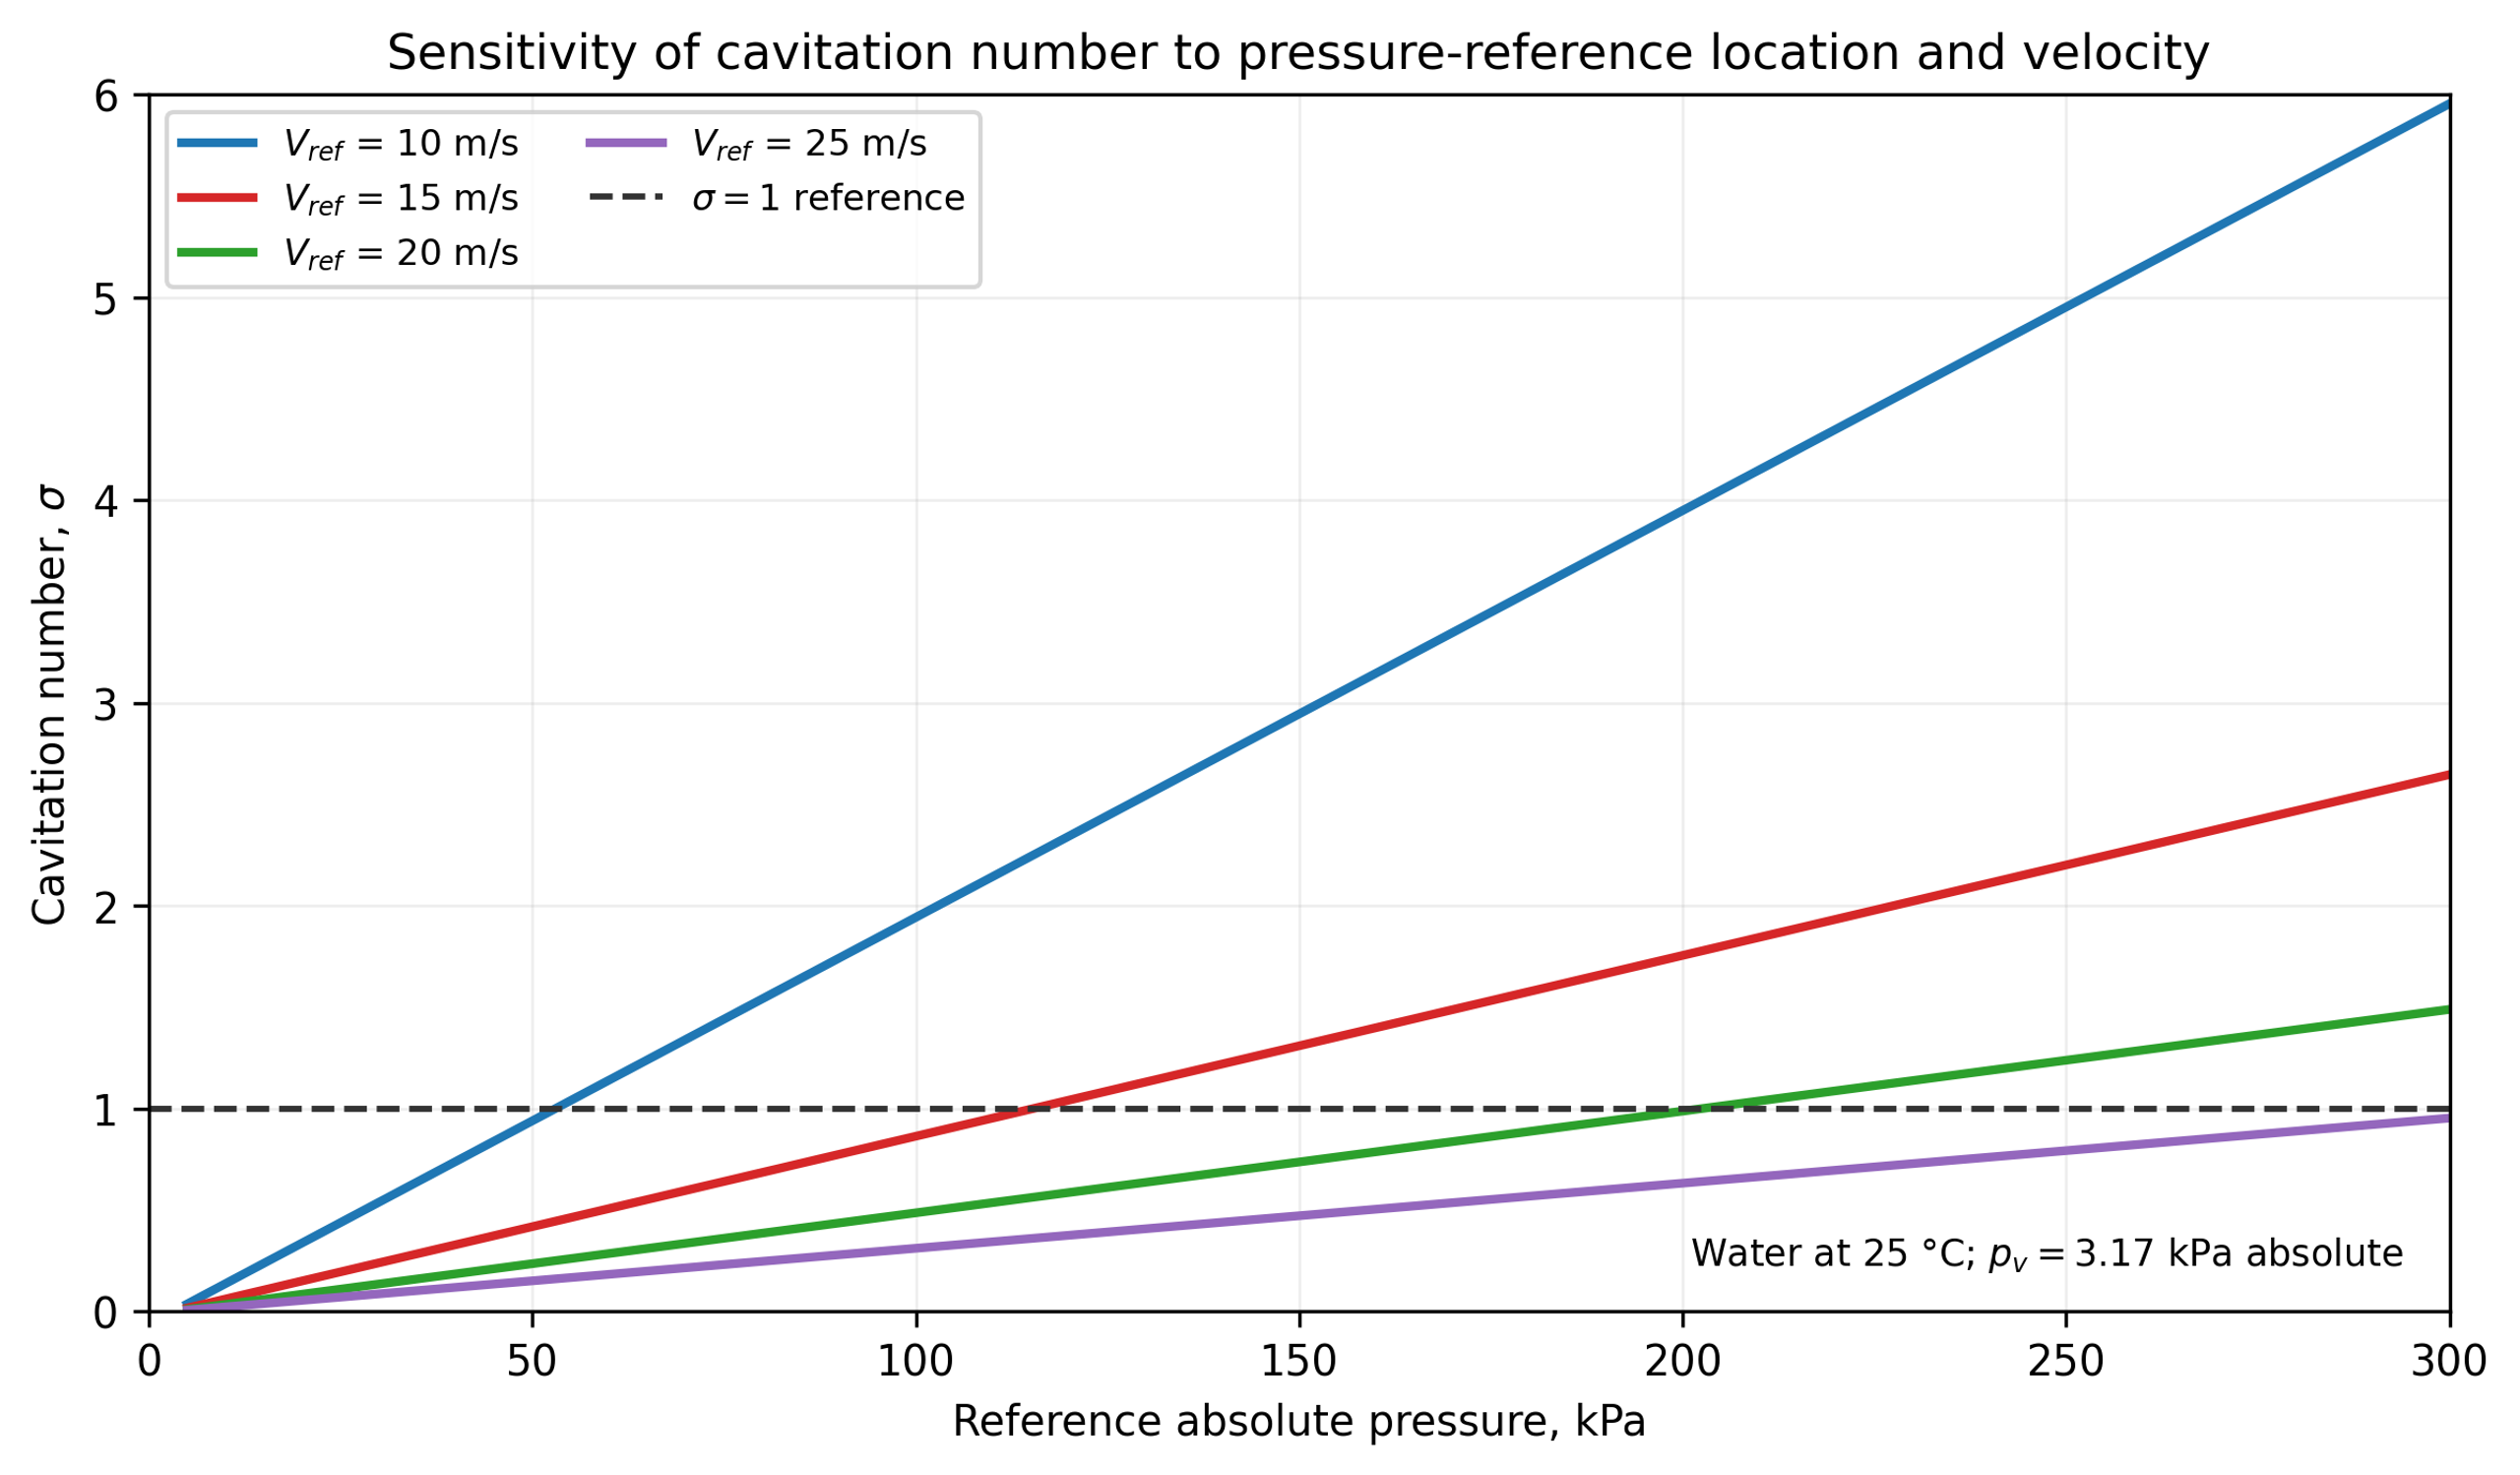
Figure 3.3. Sensitivity of the cavitation number to the selected absolute pressure and reference velocity for water at 25 °C [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 3.3](#figure-3-3). Sensitivity of the cavitation number to the selected absolute pressure and reference velocity for water at 25 °C [32].*
### 3.2 Venturi based flow through devices
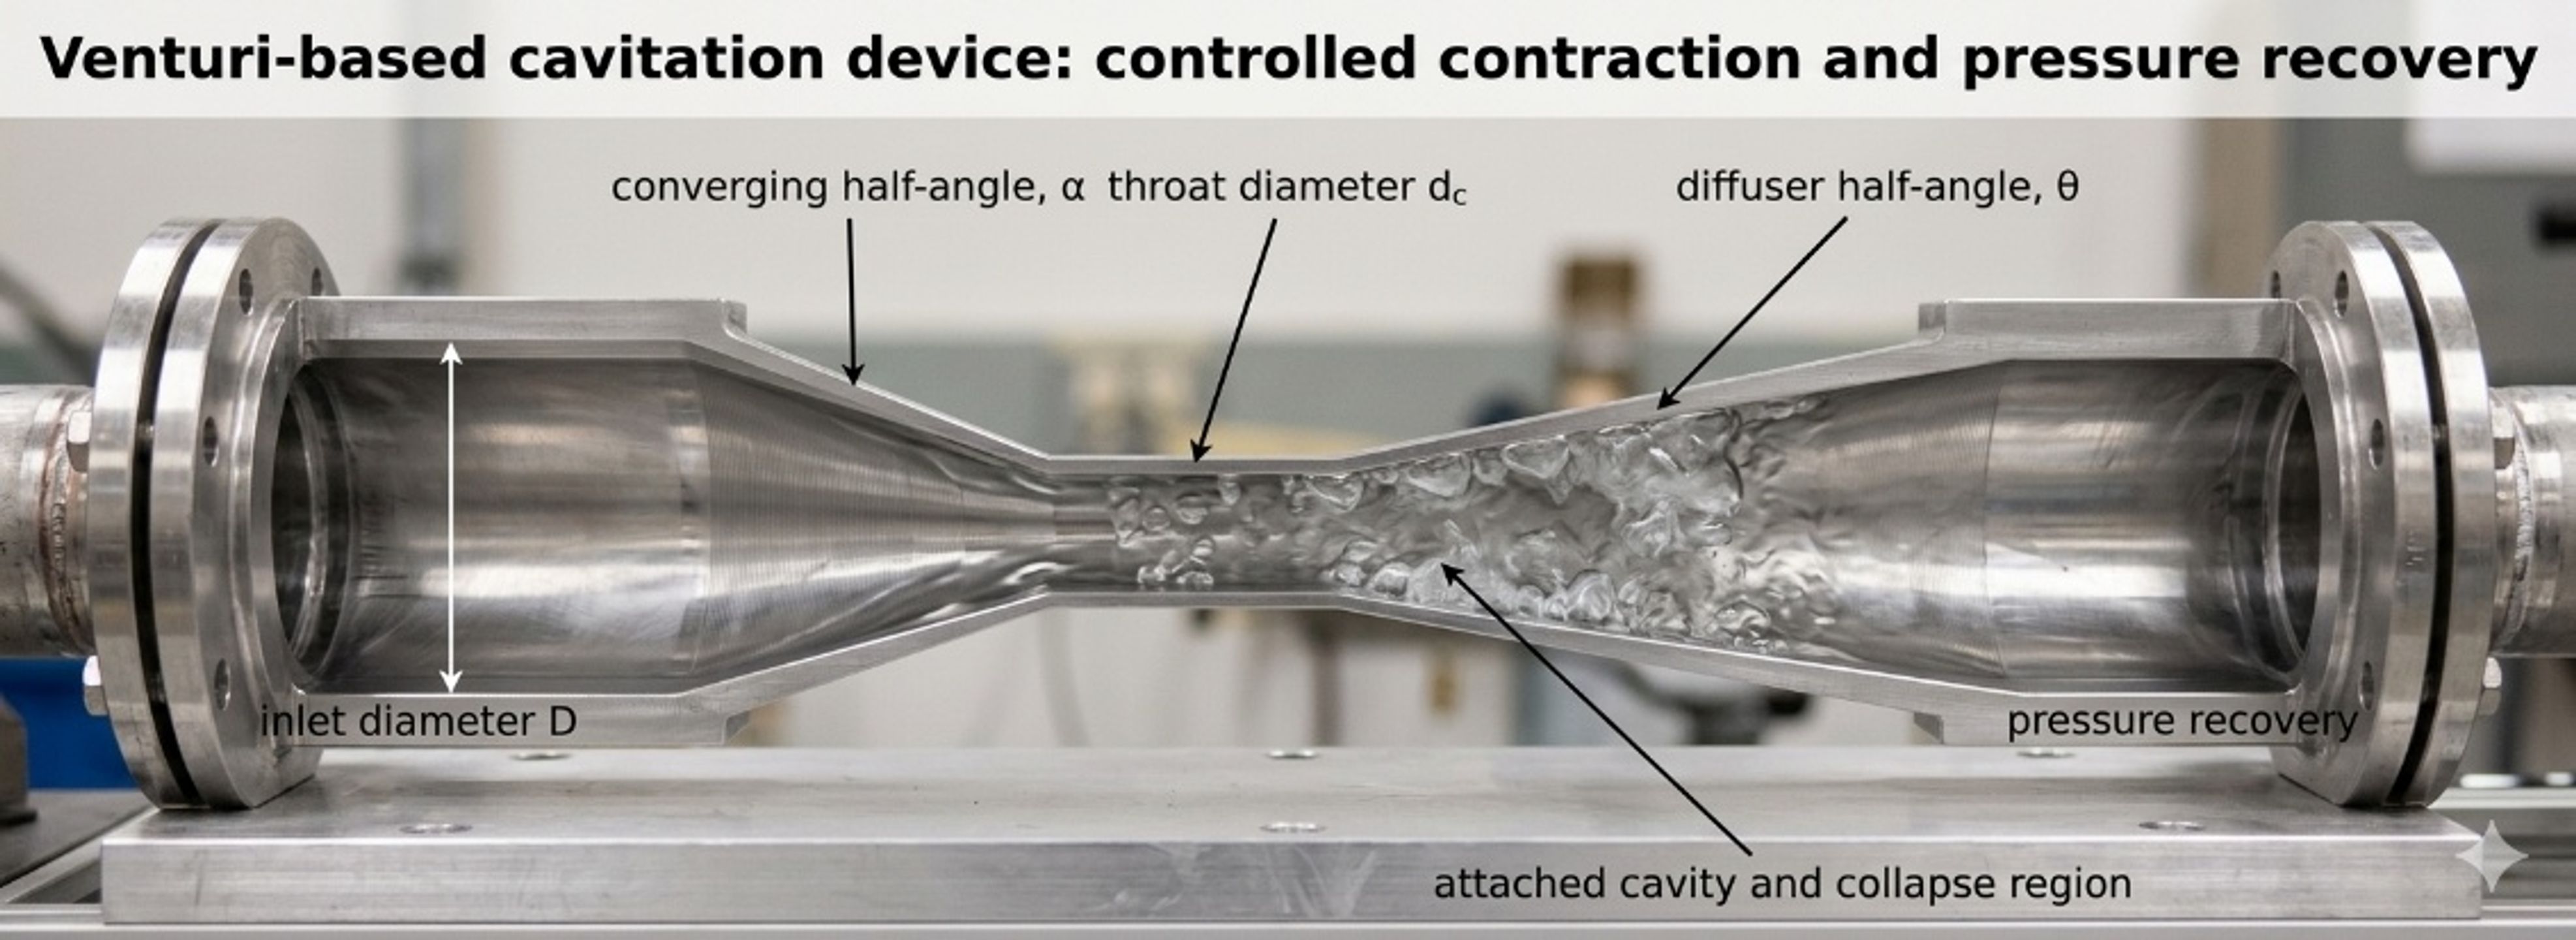
A Venturi cavitator consists of a converging section, a throat, and a
diffuser. The calculation must define the contraction profile, throat
diameter or hydraulic diameter, throat length, diffuser half angle,
outlet diameter, surface finish, and pressure tap locations. Relative to
a sharp orifice, a Venturi can provide a controlled low pressure
residence interval and smoother recovery, although an aggressive
diffuser can separate and generate an unsteady recovery field [4,6].
Figure 3.4. Venturi based cavitation element and principal geometric variables [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 3.4](#figure-3-4). Venturi based cavitation element and principal geometric variables [32].*
If the desired throat velocity is known, throat area is:
(3.10)
A loss free Bernoulli screen for the throat velocity is:
(3.11)
where is the selected throat pressure, usually near but not
necessarily below . This equation neglects contraction loss, wall
friction, turbulence, vapor volume, and two phase choking. It therefore
provides an ideal upper velocity or minimum area screen.
For a circular throat,
(3.12)
and the diameter ratio is:
(3.13)
For a calibrated incompressible Venturi relation,
(3.14)
where is defined between the upstream and throat stations.
The coefficient and tap arrangement must correspond to the actual
geometry. Standard metering correlations should not be extrapolated
automatically into developed cavitation or nonstandard diffuser
geometries [15, 16].
Pressure recovery can be characterized by:
(3.15)
where is the downstream recovered pressure. A larger value
indicates greater static pressure recovery for the defined stations, but
the coefficient does not reveal local oscillation, separation, or
erosion.
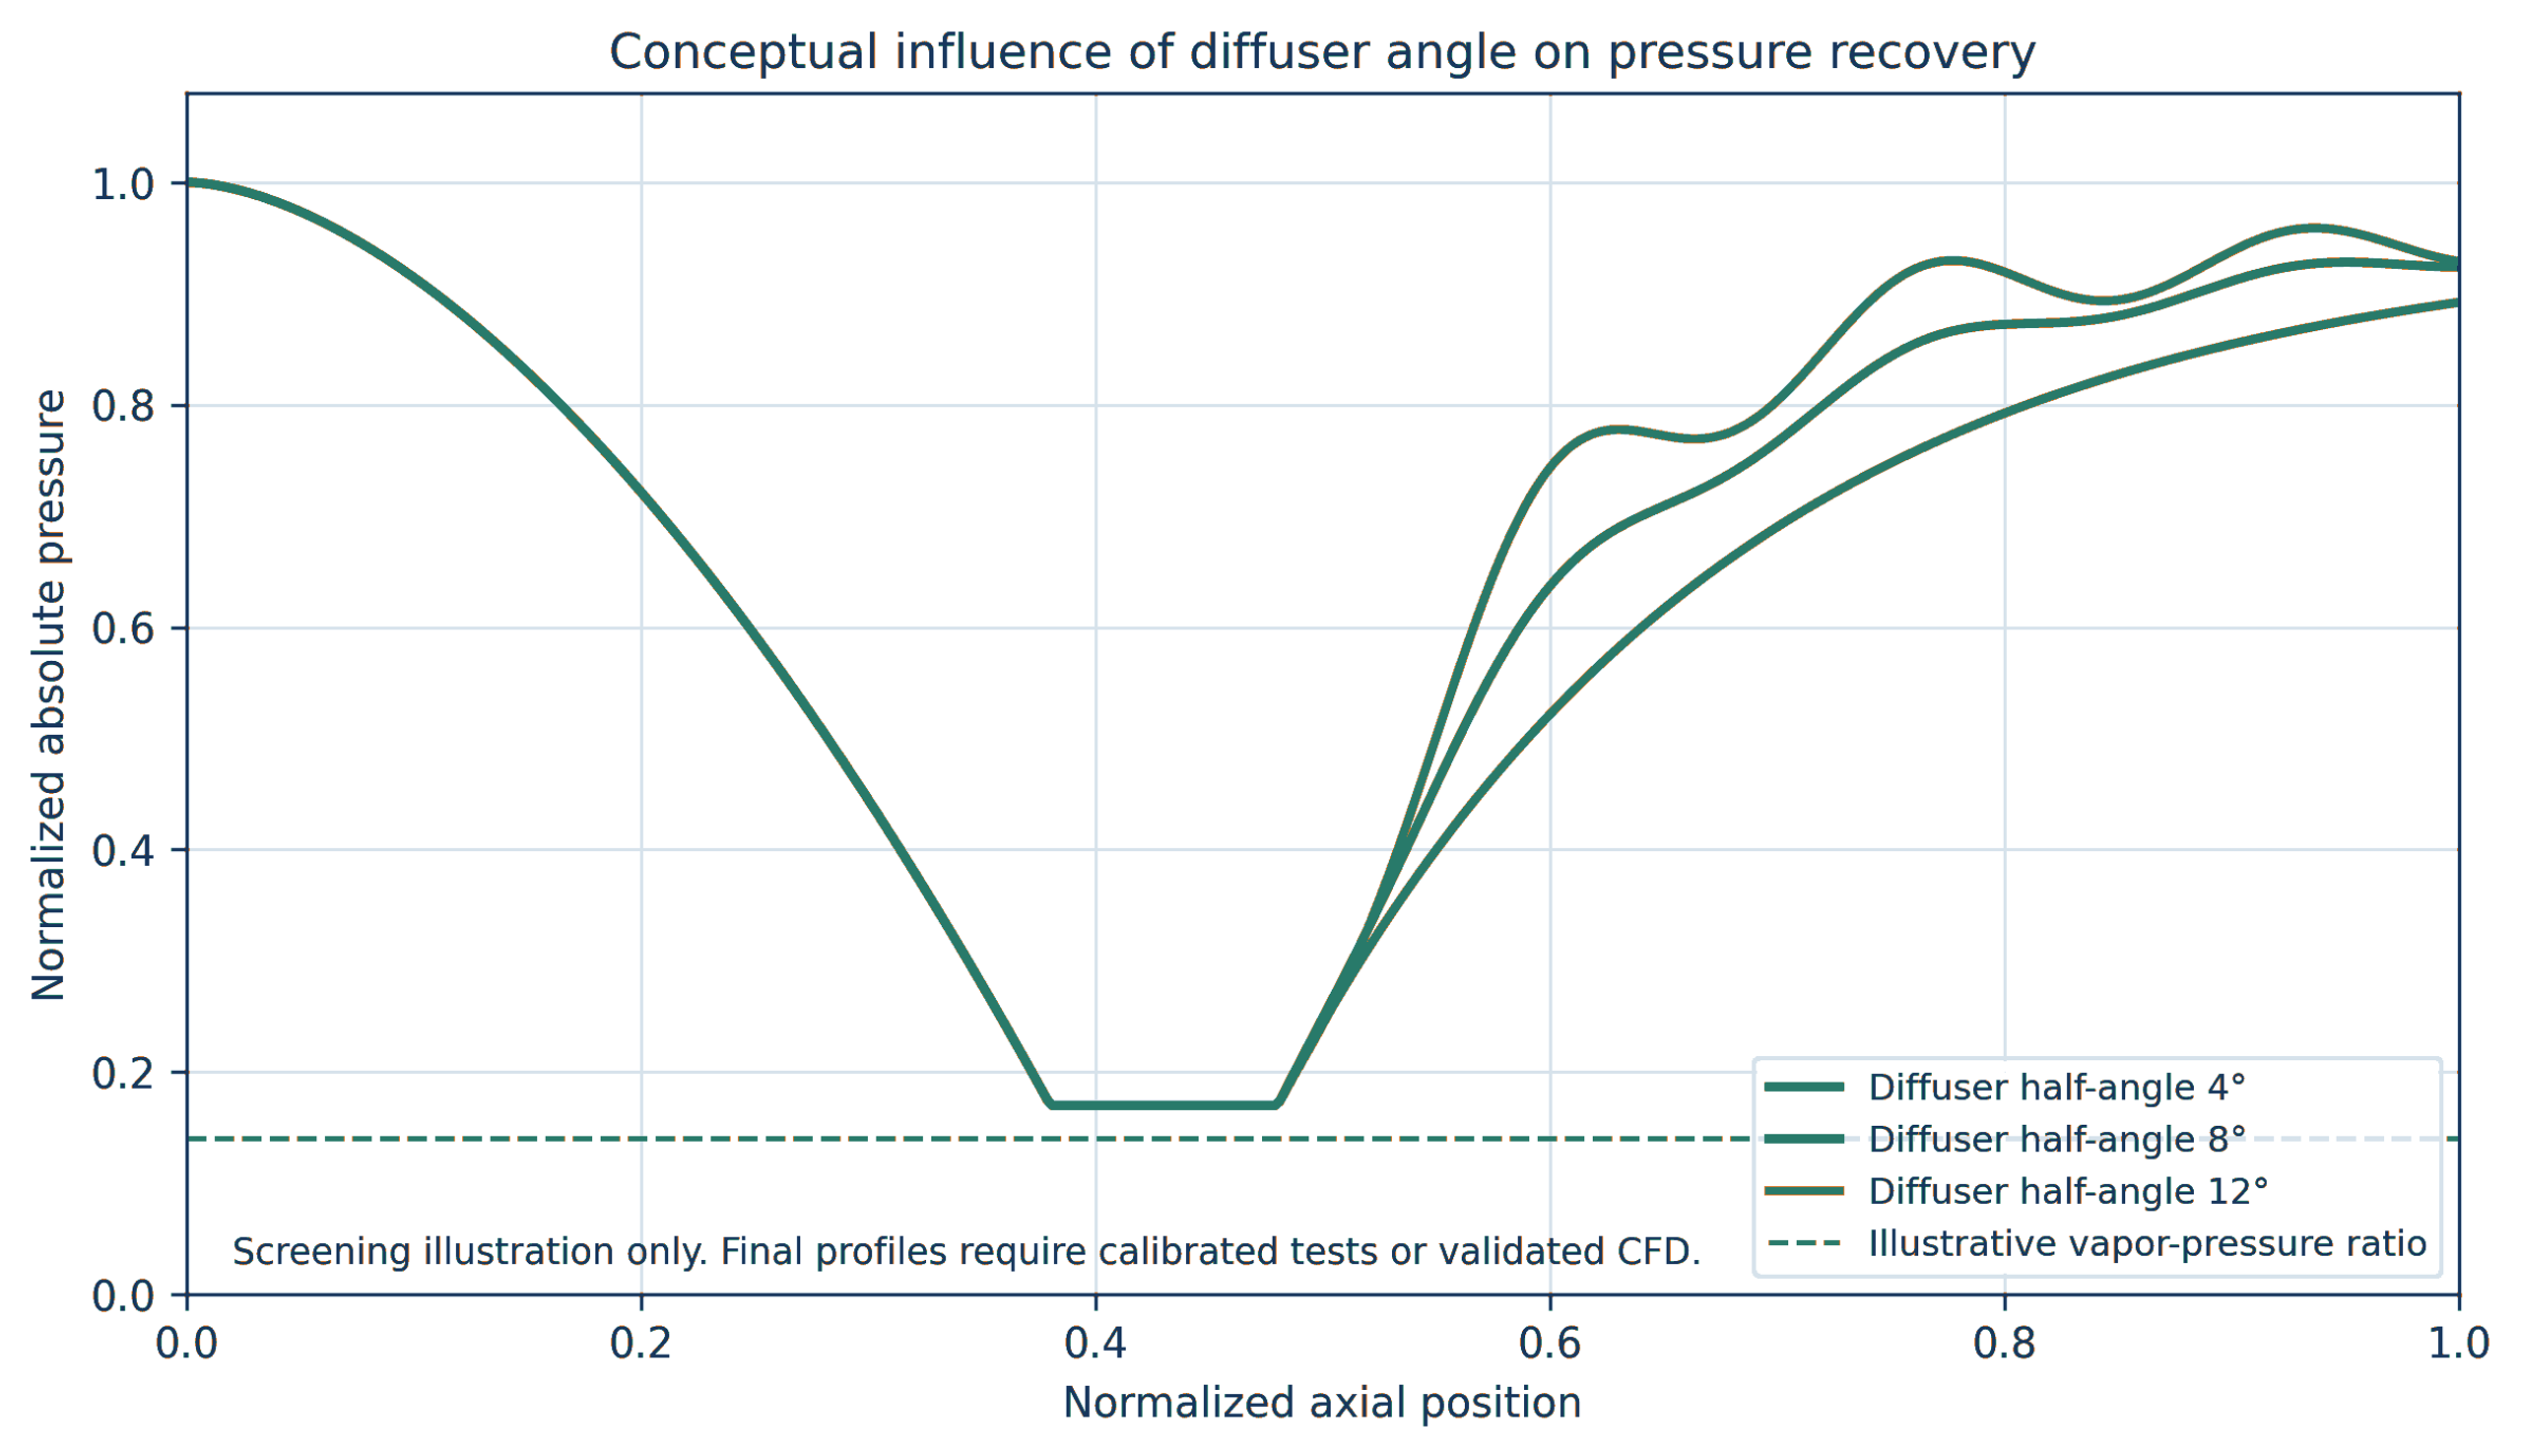
For a conical diffuser with half angle ,
(3.16)
where is the downstream diameter. Small angles require longer
equipment but generally support more gradual recovery. Larger angles
shorten the device but can increase separation. The optimum is geometry
and Reynolds number dependent; final selection should use validated CFD
or a measured recovery map [4,6].
For a noncircular throat, the hydraulic diameter is:
(3.17)
where is wetted perimeter. A slit Venturi may be sized using
for Reynolds number and friction screens, but local corner flow,
aspect ratio, and sidewall effects still require explicit treatment.
Figure 3.5. Conceptual effect of diffuser half angle on pressure recovery [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 3.5](#figure-3-5). Conceptual effect of diffuser half angle on pressure recovery [32].*
#### Worked Example 3.2: ideal throat screen
Design basis. Water at 25 °C flows at m³/h through a 50 mm
inlet. The inlet absolute pressure is 450 kPa. An ideal throat pressure
target of 2.5 kPa absolute is used to screen the minimum throat area.
This target is slightly below the equilibrium vapor pressure and
intentionally signals that a single phase Bernoulli model has reached
its limit.
The inlet velocity is 1.415 m/s. Equation (3.11) gives an ideal throat
velocity of 30.0 m/s. Equations (3.10) and (3.12) give
m² and mm. Equation
(3.13) gives .
For a return to 50 mm diameter, Equation (3.16) gives the following
geometric lengths:
*Table 3.3. Diffuser length screen for Worked Example 3.2.*
| **Diffuser half angle** | **Calculated diffuser length** |
|-------------------------|--------------------------------|
| 4° | 0.280 m |
| 6° | 0.186 m |
| 8° | 0.139 m |
| 10° | 0.111 m |
| 12° | 0.092 m |
The calculation does not imply that a 10.86 mm throat will maintain an
absolute pressure of 2.5 kPa. Once vapor forms, the density field,
momentum exchange, wall friction, compressibility, choking, and pressure
recovery change. The calculated throat should therefore be treated as an
initial geometry, followed by a realistic pressure profile obtained from
a calibrated coefficient or CFD, sufficient throat length for the
required cavity residence time, and testing of multiple diffuser
geometries. Absolute inlet pressure must also be verified at minimum
pump delivery and maximum operating temperature.
#### Venturi design checks
A final Venturi calculation should include:
- inlet and throat Reynolds numbers over the full viscosity range;
- contraction loss and the possibility of inlet separation;
- minimum absolute pressure and vapor fraction, not only inlet to outlet
loss;
- throat residence time ;
- diffuser recovery and separation;
- downstream pressure needed to collapse cavities within a replaceable
chamber;
- pressure pulsation and structural fatigue;
- throat wear, surface finish, and dimensional inspection;
- gas release and two phase choking;
- cleanability and minimum passage;
- pump curve, available suction head, and prevention of unintended pump
cavitation.
### 3.3 Bluff body, wake, impingement, and multistage devices
A bluff body creates separated shear layers and a low pressure wake.
Cavitation may form along the separation region, in periodic vortices,
or where jets impinge and turn. The geometry can be a cone, cylinder,
disk, wedge, baffle, liquid
whistle or opposed jet element. The global pressure drop can be
represented by a loss coefficient, but useful calculation also requires
blockage, wake length, shedding frequency, and the location of solid
surfaces relative to collapse [2,4].
The blockage ratio is:
(3.18)
where is the projected bluff body area. Periodic wake behavior
is characterized by the Strouhal number:
(3.19)
where is shedding frequency and is a characteristic body
dimension. A measured acoustic peak should not be identified
automatically as the shedding frequency because pump pulsation,
structural resonance, cavity cloud oscillation, and blade or valve
frequencies may overlap.
Multistage devices place several restrictions or baffles in series. The
total measured loss is:
(3.20)
where is number of stages and includes
connecting passages, expansions, and manifolds. The corresponding
hydraulic power is:
(3.21)
Equal division of total pressure drop among stages is not guaranteed.
Upstream gas release, temperature rise, changing vapor fraction,
fouling, and different downstream recovery conditions can make nominally
identical stages operate differently. Pressure measurements between
stages or a validated model are required when stage by stage control is
important.
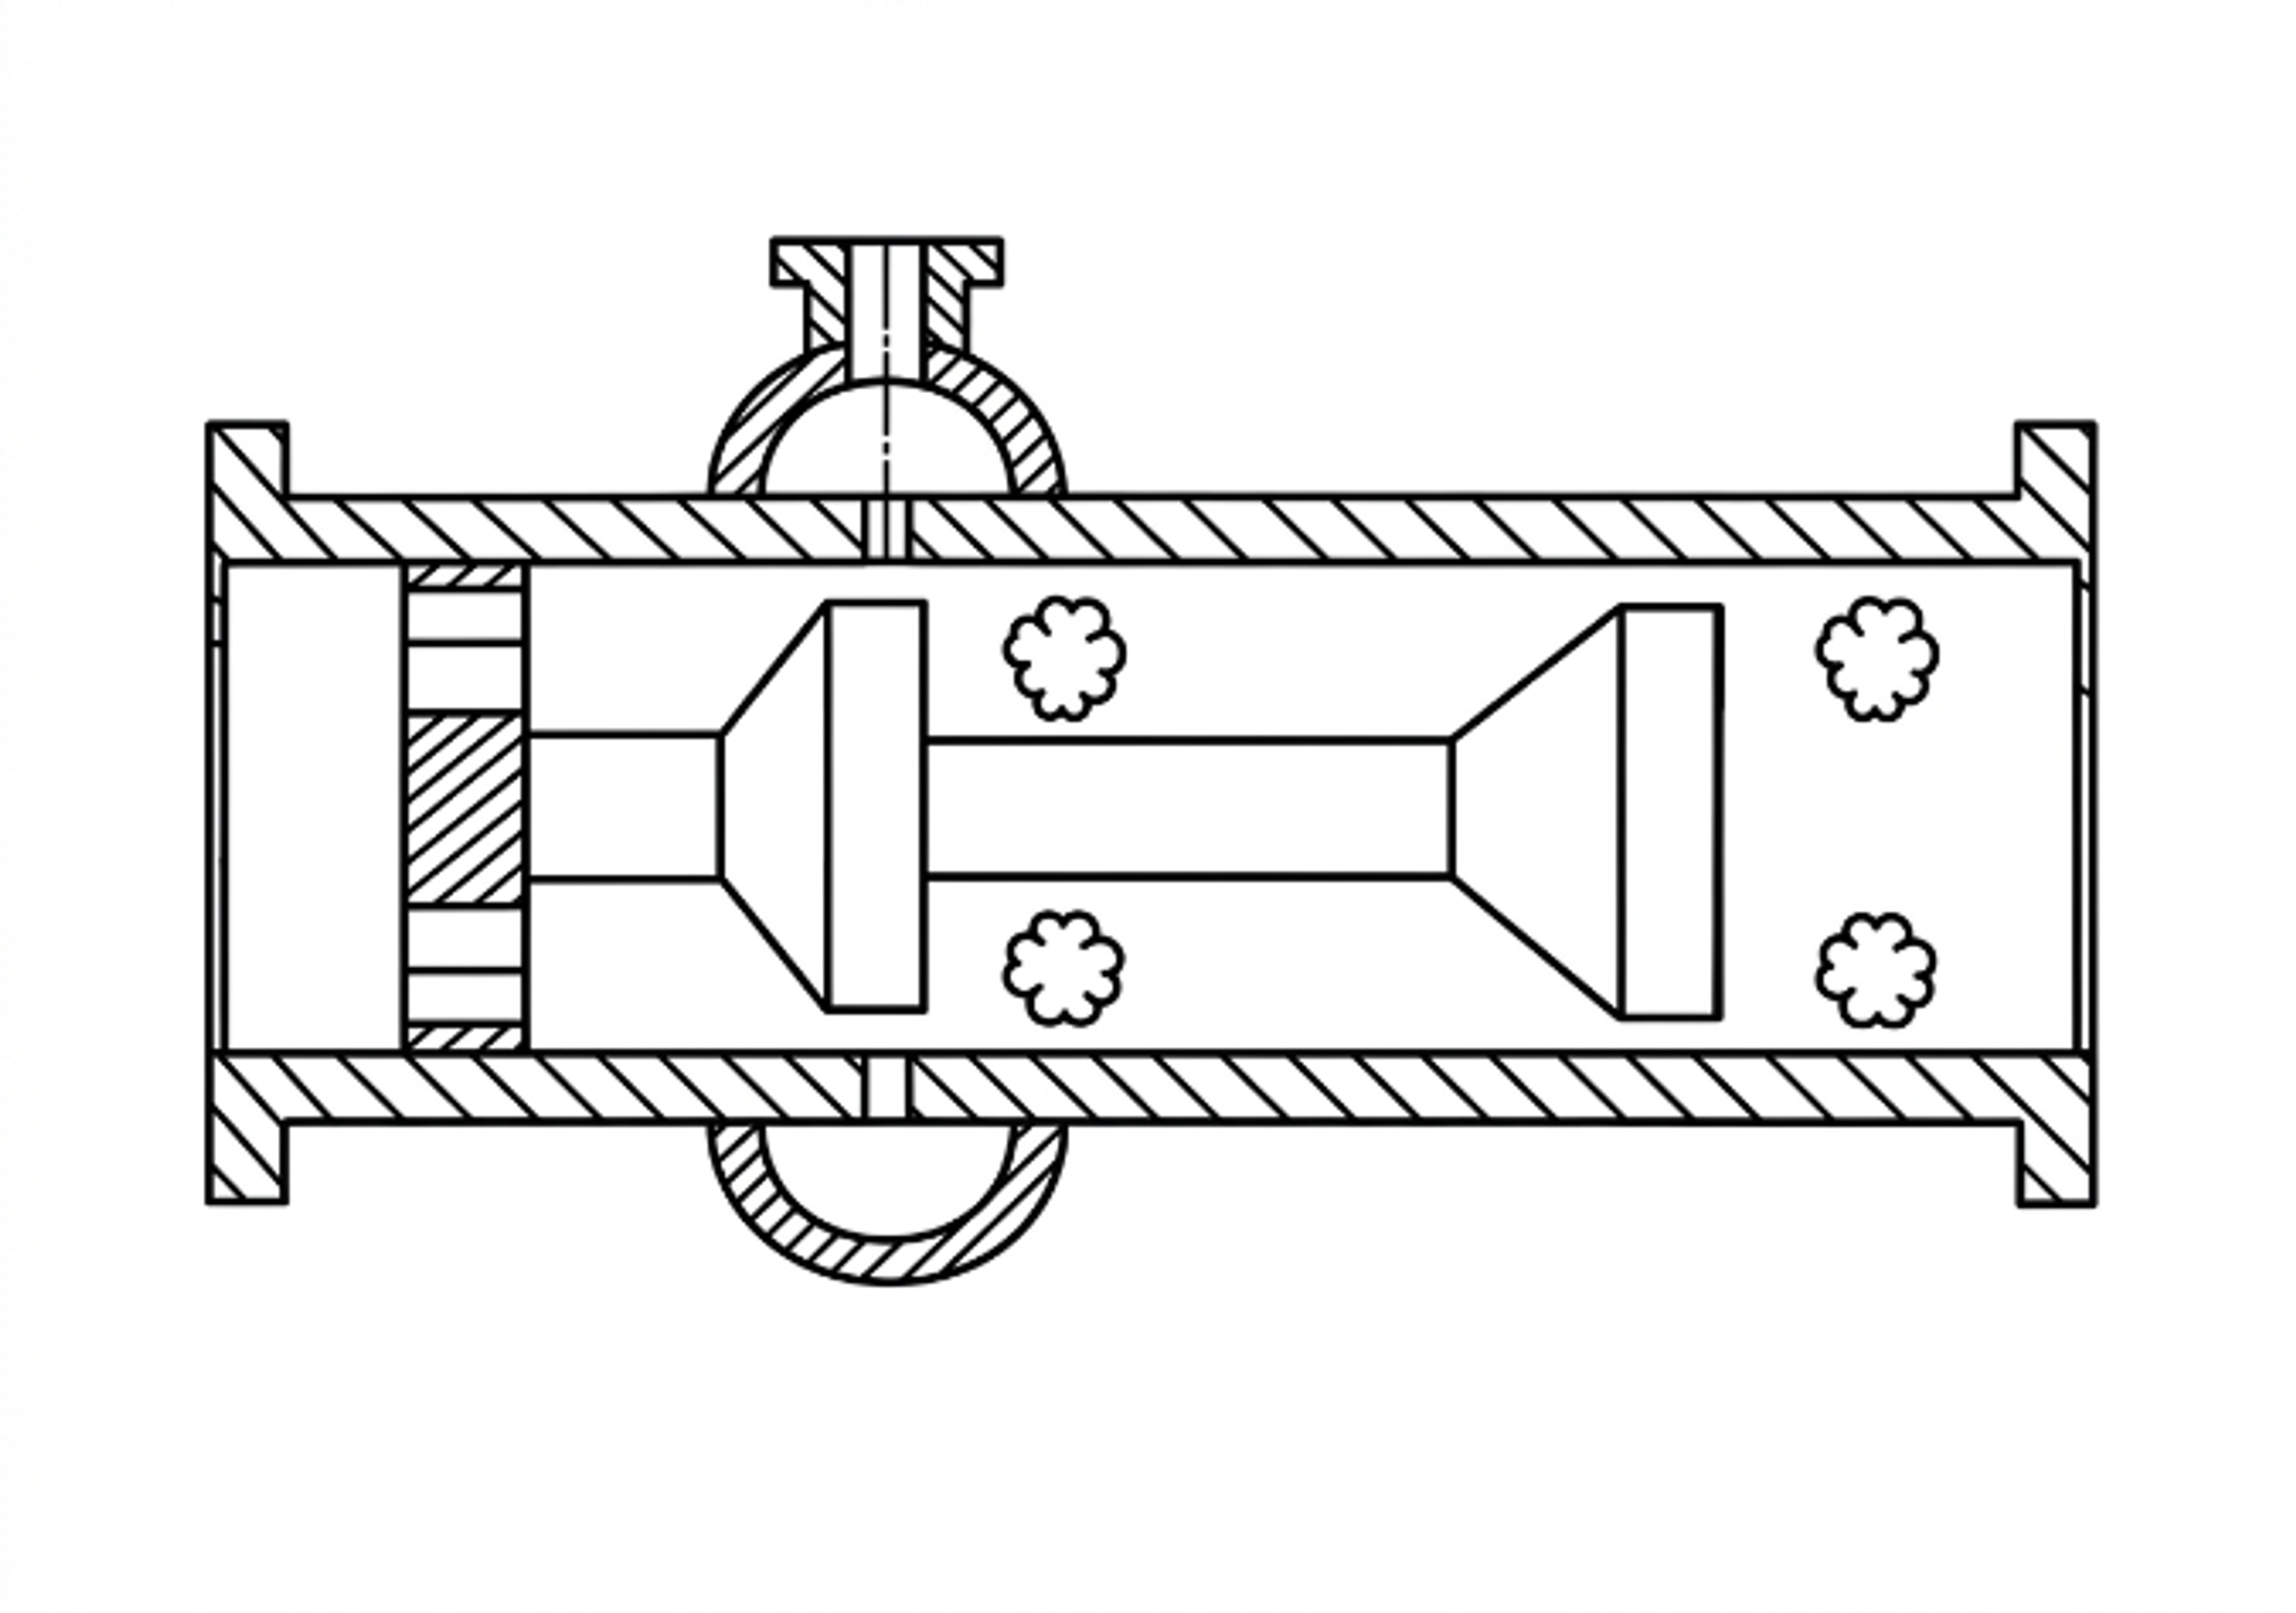
Figure 3.6. Multistage flow through cavitation device with repeated baffle elements. [13]Source: Kozyuk O.V. Device and method for creating hydrodynamic cavitation in fluids. US Patent 7,338,551 B2, 2005.
*[Figure 3.6](#figure-3-6). Multistage flow through cavitation device with repeated baffle elements. [13].*
A multistage design should provide enough pressure recovery before the
next restriction to obtain the intended collapse and regrowth sequence.
If the pressure remains near vapor pressure throughout the device, the
result may be a connected supercavity rather than repeated discrete
collapse zones. Conversely, complete recovery at every stage can impose
high cumulative pressure loss and concentrate erosion at each wall.
Stage spacing, chamber diameter, baffle orientation, and intermediate
pressure are therefore coupled with design variables.
*Table 3.4. Calculation record for a multistage static device.*
| **Stage** | **Restriction geometry** | | **abs.** | **Estimated** **abs.** | **abs.** | | **Residence or spacing** | **Inspection feature** |
|-----------|-----------------------------|----------------|-------------------------------------|-----------------------------------------------------|--------------------------------------|--------------------------------------------|--------------------------|------------------------------|
| 1 | Hole, slit, cone, or baffle | | | | | | | Replaceable insert or coupon |
| 2 | Hole, slit, cone, or baffle | | | | | | | Intermediate tap |
| 3 | Hole, slit, cone, or baffle | | | | | | | Removable collapse chamber |
| | Final element | | | | | | | Downstream thickness monitor |
### 3.4 Static device scale up and scale out
Geometric enlargement of a static device changes absolute hole size, jet
spacing, wall distance, residence time, pressure recovery, and the
population of nuclei passing through each active zone. Keeping
constant does not preserve these quantities. A multi hole device can
often be scaled by increasing the number of validated holes or by using
parallel cartridges, but the manifold must distribute flow uniformly. A
Venturi can be enlarged geometrically, but diffuser behavior and cavity
length may not remain similar at a new Reynolds number and pressure
scale. A bluff body device can change shedding and wake confinement as
blockage and chamber dimensions change [4, 7–10].
The recommended scale up hierarchy is:
- Preserve the active geometric feature and its dimensionless ratios.
- Preserve the pressure history, including the recovery region, rather
than only total pressure drop.
- Match the relevant Reynolds, Euler, Weber, and cavitation number
definitions as closely as practical.
- Preserve or deliberately redesign the exposure time and number of
active zones.
- Verify pressure, flow, cavity signature, product response, specific
electrical energy, and material loss simultaneously.
- Prefer parallel scale out when one large device introduces a new,
unvalidated flow structure.
A static device should be accepted only after the pump and piping system
are considered. The cavitator may be correctly sized while the pump
operates near suction cavitation, the downstream valve creates a second
uncontrolled cavitation zone, or the recirculation line accumulates gas.
The complete hydraulic system curve, pump curve, relief path, maximum
blocked in pressure, and minimum downstream pressure belong in the
calculation package.
## 4 Calculations for Vortex Cavitation Devices
A vortex cavitation device uses tangential momentum to establish a
radial pressure gradient. The lowest mean pressure occurs near the
vortex axis, allowing the principal cavity to remain within the fluid
core rather than attach directly to the outer wall. This arrangement can
reduce direct wall exposure, although collapse may still occur near the
outlet, end plate, core stabilizer, or downstream recovery chamber.
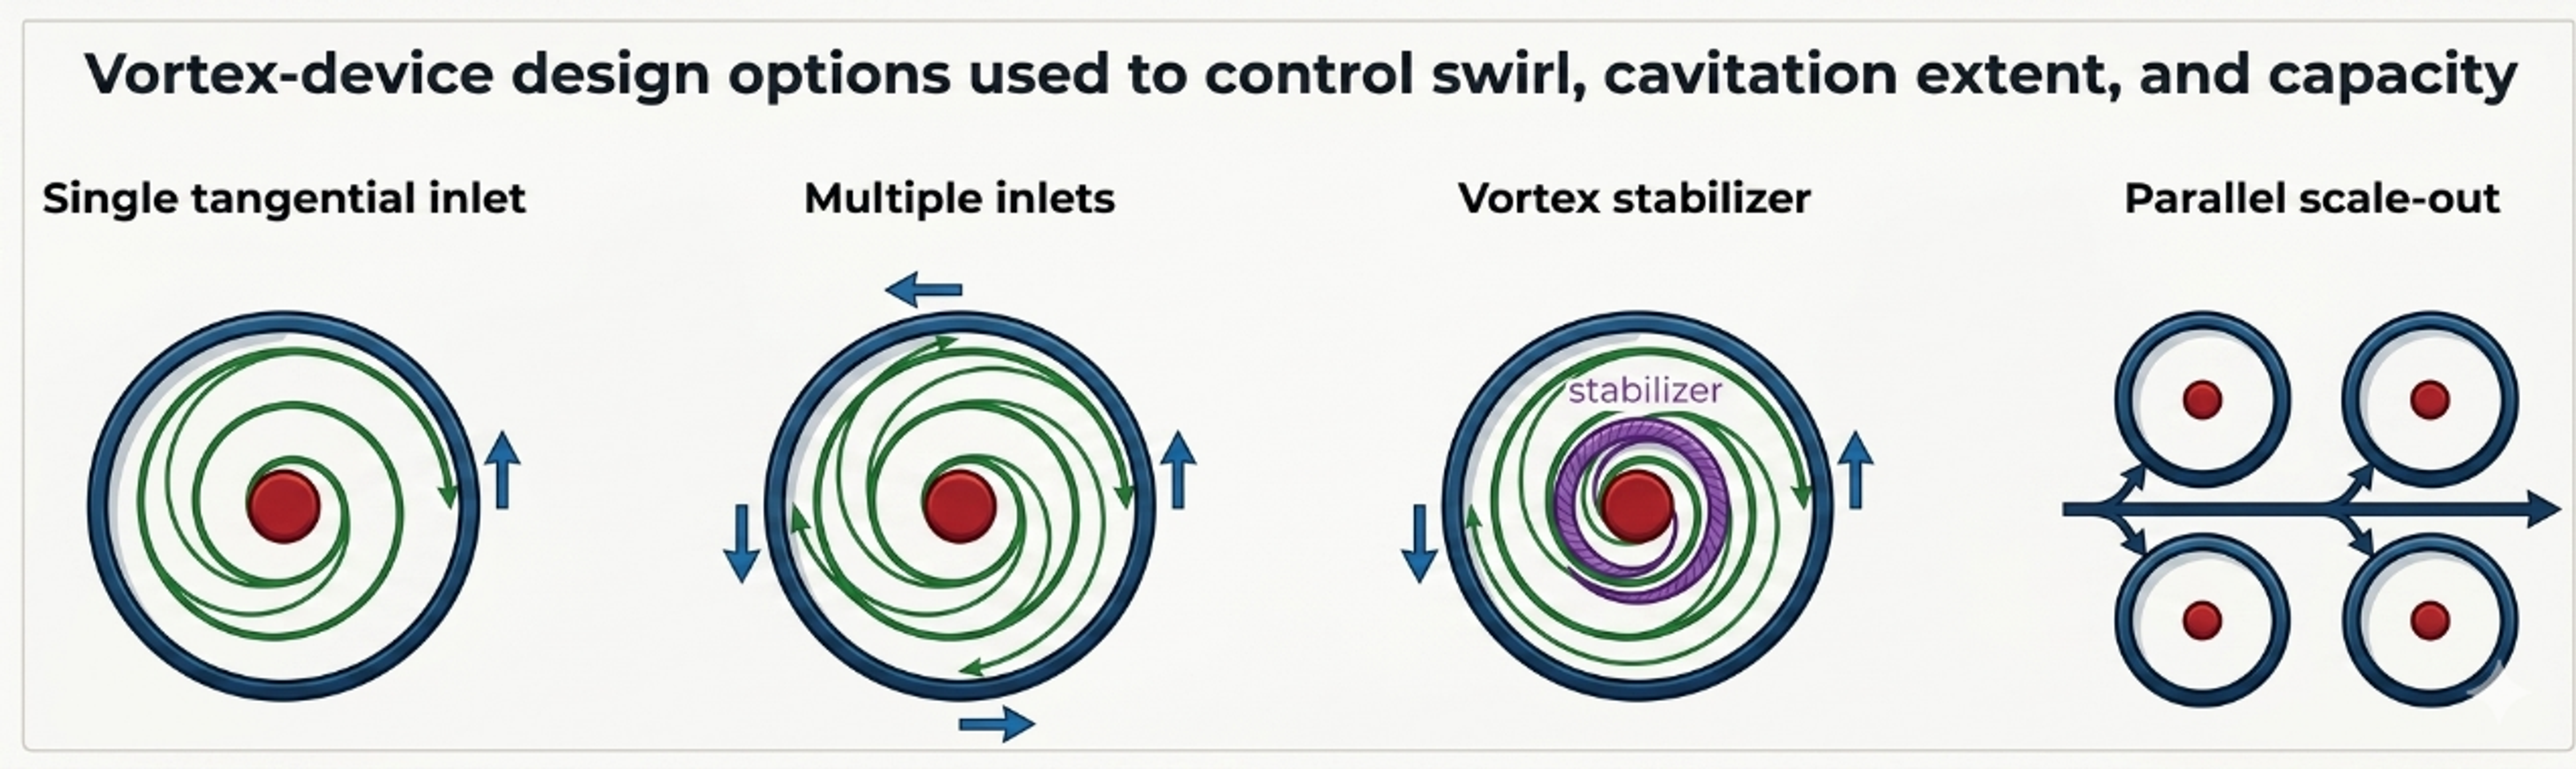
Vortex configurations include single or multiple tangential inlets,
annular entries, conical or stepped chambers, vortex diodes, axial or
tangential outlets, and staged or parallel modules [4, 7–10, 14].
The calculation comprises three stages. First, the tangential inlets and
outlet are sized for the required flow and pressure drop. Second, a
radial equilibrium model is used to screen whether circulation can
reduce the core pressure toward the vapor pressure region. Third, the
model is calibrated because real vortex flow contains a viscous core,
axial velocity, turbulent diffusion, precession, gas release, and vapor,
all of which limit the pressure depression predicted by an ideal free
vortex model.
Figure 4.1. Representative vortex cavitation configurations and geometric variables [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 4.1](#figure-4-1). Representative vortex cavitation configurations and geometric variables [32].*
### 4.1 Radial equilibrium screening model
For steady axisymmetric swirling flow with radial velocity small
relative to tangential velocity, radial equilibrium is
(4.1)
where is tangential velocity and is radius from the
axis. Outside a finite viscous core, an ideal free vortex can be
represented as:
(4.2)
where is circulation. Integrating Equation (4.1) between an
outer radius at pressure and radius gives:
(4.3)
The mathematical free vortex predicts unbounded velocity and decreasing
pressure as , which is not physical. A preliminary
device calculation therefore specifies a finite core radius and
applies Equation (4.3) only for . Inside the core, a
forced vortex or measured profile is more appropriate.
The circulation required for the calculated pressure at to reach
vapor pressure is:
(4.4)
Equation (4.4) is a useful screening criterion, but it does not predict
the resulting vapor core radius. Once , a two phase core
forms and modifies the velocity and pressure field. The criterion also
depends strongly on the assumed , which must be obtained from
measurement, validated CFD, or a correlation for the selected chamber.
### 4.2 Tangential inlet and outlet sizing
For equal tangential inlets of area , the nominal inlet
velocity is:
(4.5)
The inlet Reynolds number should use the appropriate hydraulic diameter.
Multiple inlets can improve azimuthal symmetry and distribute momentum,
but their jets may interact differently as device scale, chamber aspect
ratio, and inlet to chamber area ratio change.
A practical inlet velocity ratio is:
(4.6)
where and are nominal tangential and axial velocity
components at a defined station. is not the formal integral
swirl number used in combustor analysis; it is a reproducible
engineering ratio for a specific inlet geometry. When the inlet is
purely tangential, the downstream axial component is generated by the
outlet and internal recirculation, so it should be obtained from a mass
balance or a resolved flow field.
The chamber aspect ratio is:
(4.7)
where is chamber height or axial length and is chamber
diameter. Aspect ratio affects core residence, end wall interaction, and
the distance available for vapor growth and recovery.
A vortex device Euler number based on inlet velocity is:
(4.8)
For a geometrically similar, calibrated vortex family, flow can be
represented in the form:
(4.9)
where is an empirical capacity coefficient that contains inlet
number, inlet ratio, outlet ratio, aspect ratio, and internal losses.
Equation (4.9) is a family correlation, not a universal vortex law.
Recent scale up studies demonstrate that device scale and geometry can
change both cavitation and process response even when a global pressure
drop parameter is preserved [7–10].
### 4.3 Outlet pressure, core stability, and recovery
The outlet must remove the required flow without suppressing the core or
causing uncontrolled cavitation at an outlet edge. An undersized axial
outlet increases backpressure and can shorten the vapor core; an
oversized outlet may weaken the circulation or move recovery into
downstream piping. An outlet tube extending into the chamber can
stabilize or disturb the core depending on its diameter, insertion
depth, and edge profile.
The following pressures should be distinguished:
- , the pressure near the outer chamber radius used in a radial
equilibrium model;
- , the mean core pressure;
- , the outlet pressure measured;
- , the instantaneous local minimum from a resolved model or
high frequency measurement;
- , the pressure where cavity collapse is intended.
A vortex can continue to contain a gas rich or vapor rich core when the
measured outlet pressure is well above vapor pressure. Conversely, low
outlet pressure does not prove that the strongest collapse occurs inside
the chamber. Imaging, pressure mapping, acoustic monitoring, and erosion
inspection should be used together.
Figure 4.2. Vortex cavitation device showing tangential admission and axial core/outlet features. [14]Source: Kozyuk O.V. Device and method for creating vortex cavitation in fluids. US Patent 7,178,975 B2, 2007.
*[Figure 4.2](#figure-4-2). Vortex cavitation device showing tangential admission and axial core/outlet features. [14].*
### 4.4 Worked Example 4.1: finite core vortex screen
Design basis. A water device at 25 °C has outer model radius
mm, assumed finite core radius mm, and outer
reference pressure kPa absolute. Four circular tangential
inlets, each 4.0 mm in diameter, deliver m³/h. Water
properties are kg/m³ and kPa absolute.
Circulation is varied to show the sensitivity of the single phase radial
equilibrium model.
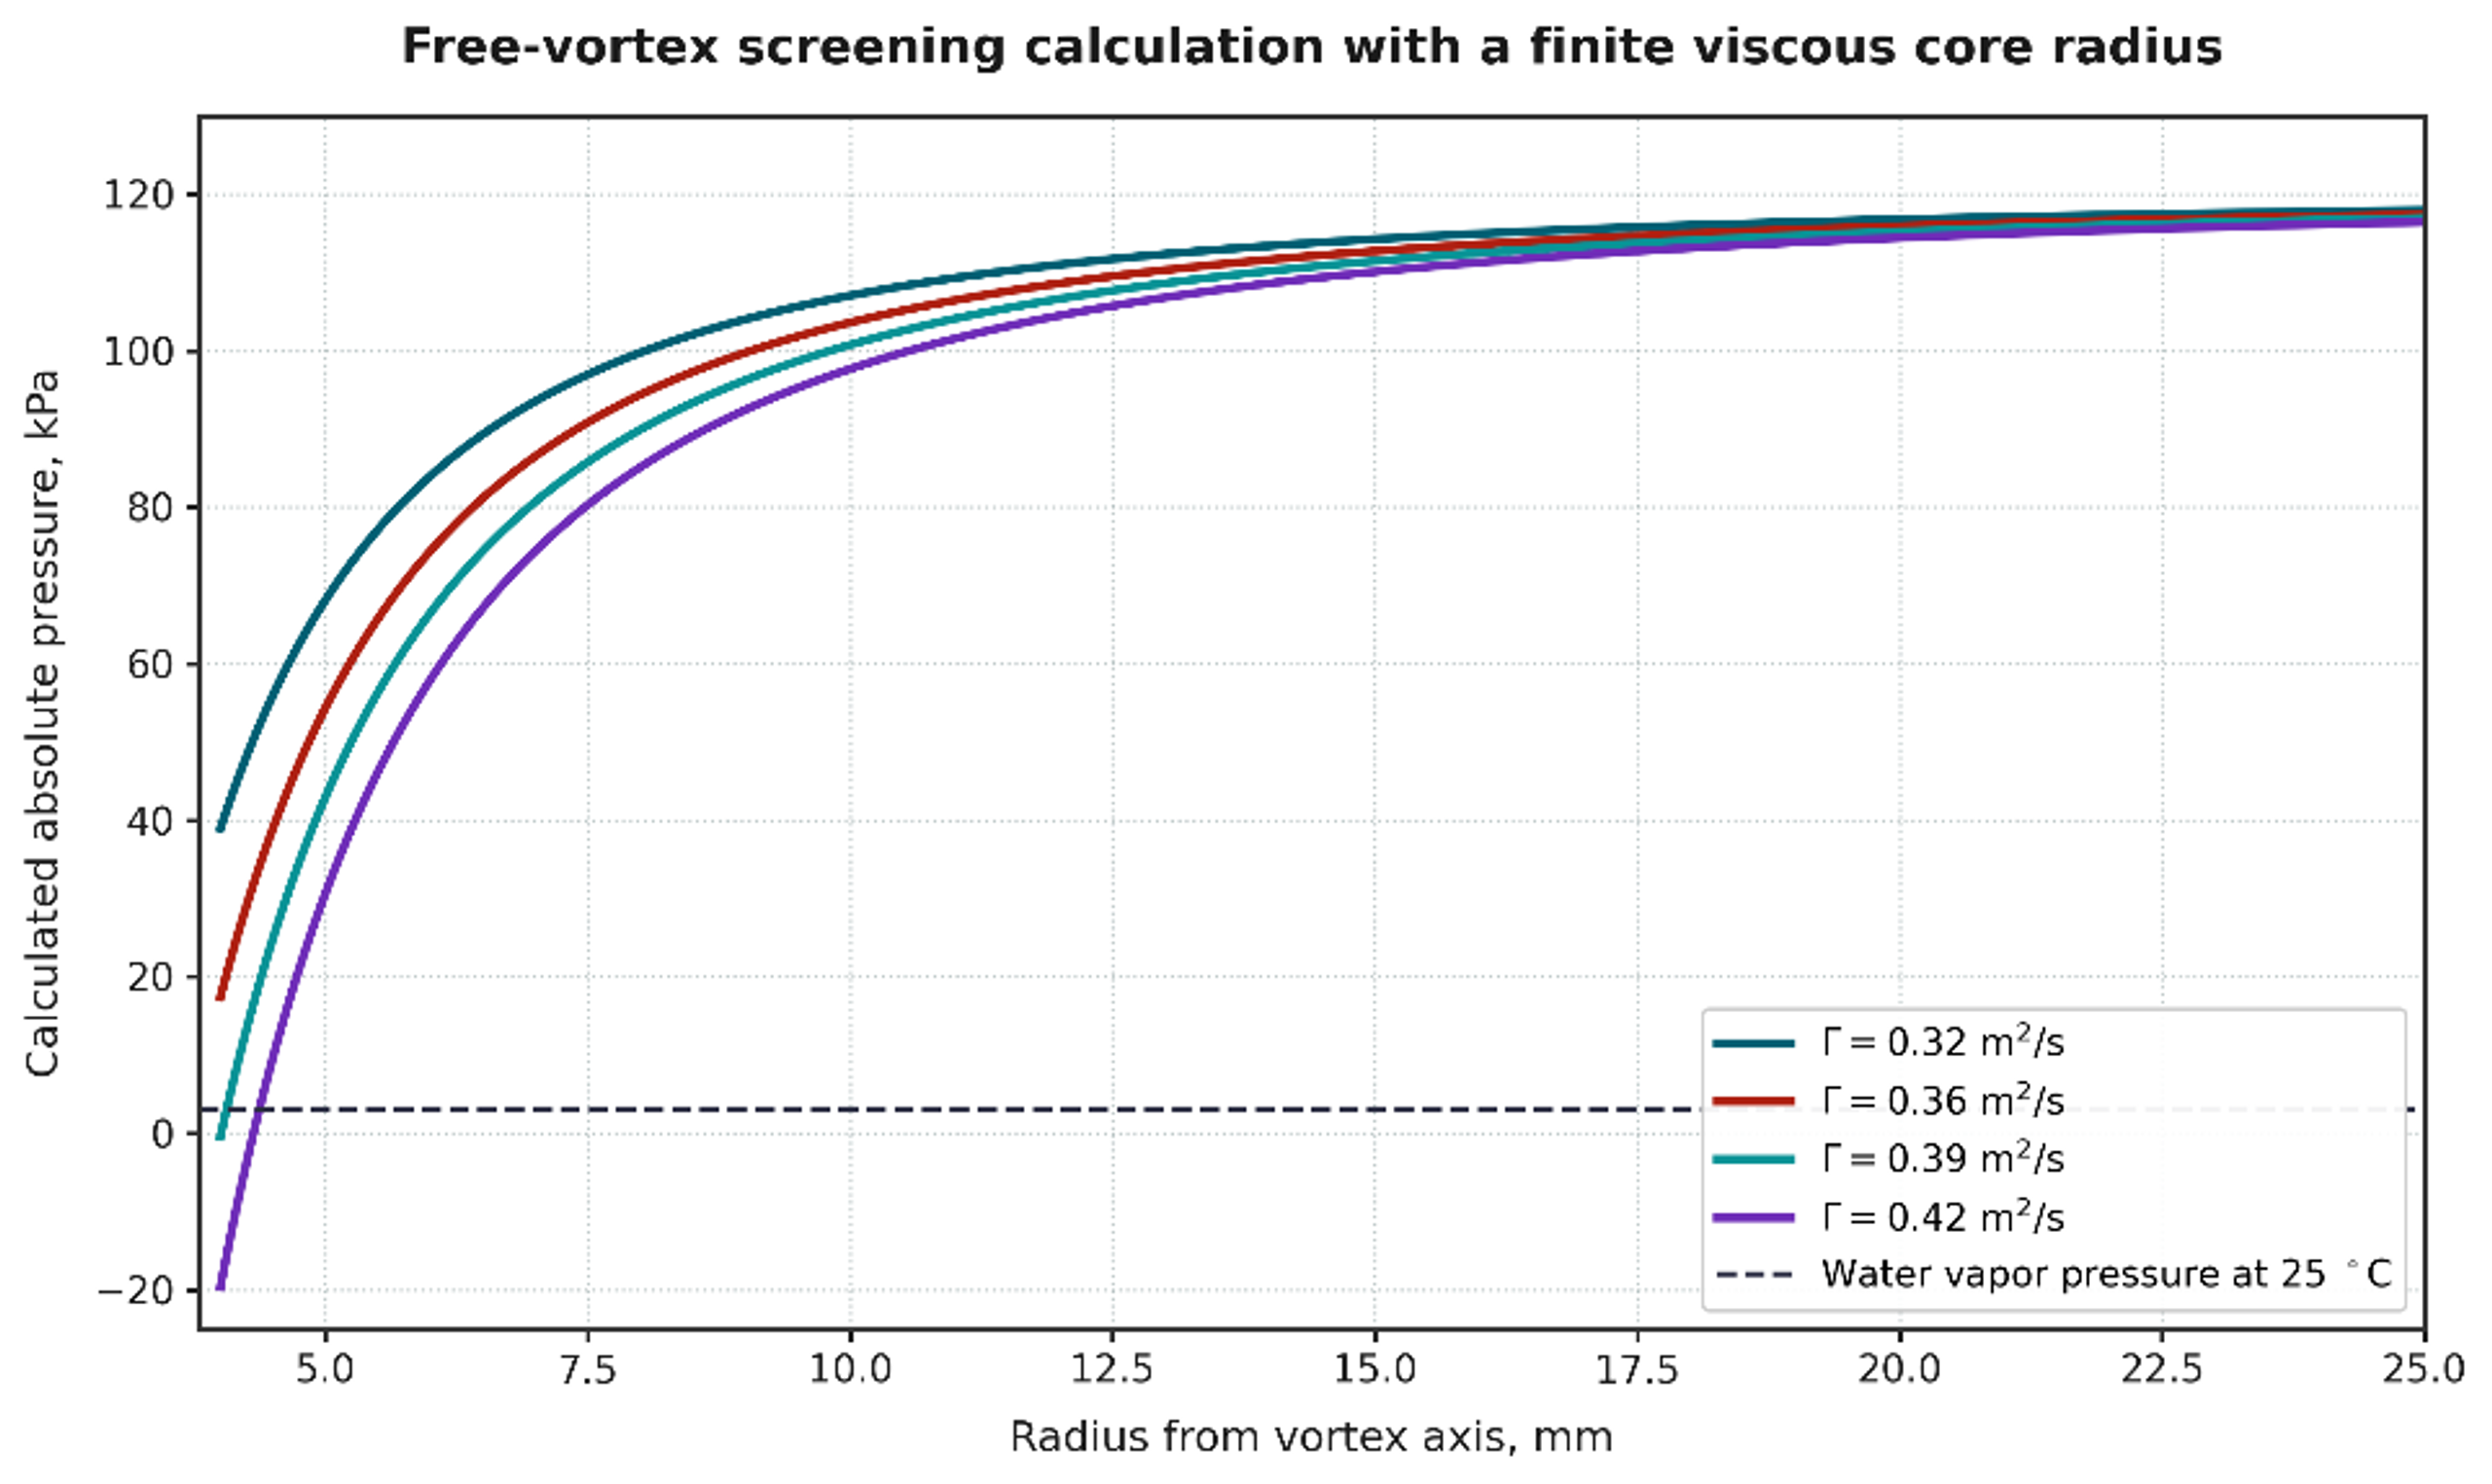
Equation (4.4) gives m²/s. Equation (4.3) gives
the following core pressures:
*Table 4.1. Worked Example 4.1 finite core results.*
| **Circulation** | **Calculated** **absolute** | **Interpretation** |
|-----------------------------------|--------------------------------------------------------------------------------|----------------------------------------------------------------|
| 0.32 m²/s | 41.3 kPa | Above vapor pressure in the single phase screen |
| 0.36 m²/s | 20.3 kPa | Strong pressure depression, but still above |
| 0.39 m²/s | 3.04 kPa | Approximately the calculated inception boundary |
| 0.42 m²/s | −15.7 kPa | Nonphysical single phase result; vapor core model is mandatory |
Equation (4.5) gives a nominal velocity of 16.58 m/s in each of the four
tangential inlets. The calculation does not determine the fraction of
inlet momentum converted into circulation. That conversion depends on
inlet orientation, wall friction, end wall flow, axial extraction, and
turbulence. A measured velocity field or validated CFD is required to
relate to .
Figure 4.3. Calculated radial pressure profiles for Worked Example 4.1. Calculation using Equations (4.1) to (4.3). Where the single phase model predicts pressure below vapor pressure, a two phase cavitation model is required [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 4.3](#figure-4-3). Calculated radial pressure profiles for Worked Example 4.1. Calculation using Equations (4.1) to (4.3). Where the single phase model predicts pressure below vapor pressure, a two phase cavitation model is required [32].*
The worked example demonstrates two important design limits. First, the
inferred core pressure is extremely sensitive to circulation and assumed
core radius. Second, a negative absolute pressure from Equation (4.3) is
not a prediction of a real negative pressure operating state. It
indicates that the single phase model has crossed its validity boundary
and must be replaced by a vapor core or multiphase model.
### 4.5 CFD and experimental calibration for vortex devices
A useful vortex CFD model should reproduce non cavitating pressure loss
before cavitation parameters are adjusted. The mesh must resolve
tangential inlets, near wall layers, outlet edges, and the core region.
Transient simulation is often required because the core can precess and
vapor clouds can shed. The selected cavitation model, nuclei density,
bubble radius, mass transfer coefficients, turbulence model, and
compressibility assumptions should be reported. Grid and time step
independence should be demonstrated for pressure drop, core size, vapor
volume, and dominant frequency, not only for a global residual [3, 4,
7].
Experimental calibration should include:
- a water flow pressure map at several backpressures;
- absolute pressure and temperature at every relevant station;
- visualization or a transparent development chamber where practicable;
- high frequency pressure or acoustic data to identify core precession
and cloud shedding;
- flow distribution among parallel modules;
- product response versus pressure drop, passes, and scale;
- erosion or witness coupons at end walls, outlet edges, and recovery
surfaces;
- repeat tests after dimensional wear to identify drift.
Studies of vortex devices for degradation and continuous emulsification
show that pressure drop, number of passes, chamber geometry, device
scale, dispersed phase fraction, and scale out arrangement affect
performance. These results support the use of calibrated device families
and parallel scale out rather than the assumption that one global
cavitation number guarantees similarity [7–10].
### 4.6 Vortex scale up and scale out
For geometric scale up, inlet area, outlet area, chamber diameter,
chamber height, and core stabilizer dimensions can be scaled by a common
factor, but the absolute boundary layer thickness, viscous core,
residence time, turbulence spectrum, and gas transport do not
necessarily remain similar. Matching and Reynolds number may
require incompatible changes in flow and pressure. In addition, a larger
chamber gives cavities more time to grow and can shift collapse toward
an end wall or outlet.
Parallel scale out preserves the validated internal geometry. The
manifold calculation should limit branch to branch flow variation,
provide an isolation valve and pressure measurement for each module, and
avoid a header pressure gradient that changes backpressure
systematically across the array. The total capacity is:
(4.10)
where is number of modules. Uniformity can be reported as the
coefficient of variation:
(4.11)
where and are the standard deviation and mean of
branch flows. The acceptable should be linked to the
sensitivity of product performance to flow and pressure drop. A manifold
that is hydraulically acceptable for ordinary heat exchange may still be
too nonuniform for a narrow cavitation operating window.
*Table 4.2. Vortex device calculation and validation checklist.*
| **Item** | **Preliminary calculation** | **Calibration or acceptance evidence** |
|-------------------|-----------------------------------------------------------------|----------------------------------------------------------------------|
| Tangential inlets | Number, area, hydraulic diameter, velocity, , pressure loss | Measured branch or inlet flow and dimensional inspection |
| Chamber | , , , hold up, nominal residence time | Pressure map, visualization, residence time or tracer test |
| Core | , , calculated pressure profile | PIV, high speed imaging, CFD, acoustic or dynamic pressure signature |
| Outlet | Area ratio, velocity, insertion depth, recovered pressure | Stable flow pressure map and verified collapse location |
| Energy | , electrical input, heat balance | Calibrated electrical meter and temperature history |
| Scale up | , , geometry ratios, residence time | Pilot comparison at same product composition |
| Scale out | Header and branch losses, , isolation | Individual branch flow or pressure confirmation |
| Integrity | End wall and outlet erosion screen | Coupons, thickness map, contamination analysis |
## 5 Calculations for Dynamic Hydrodynamic Cavitation Devices
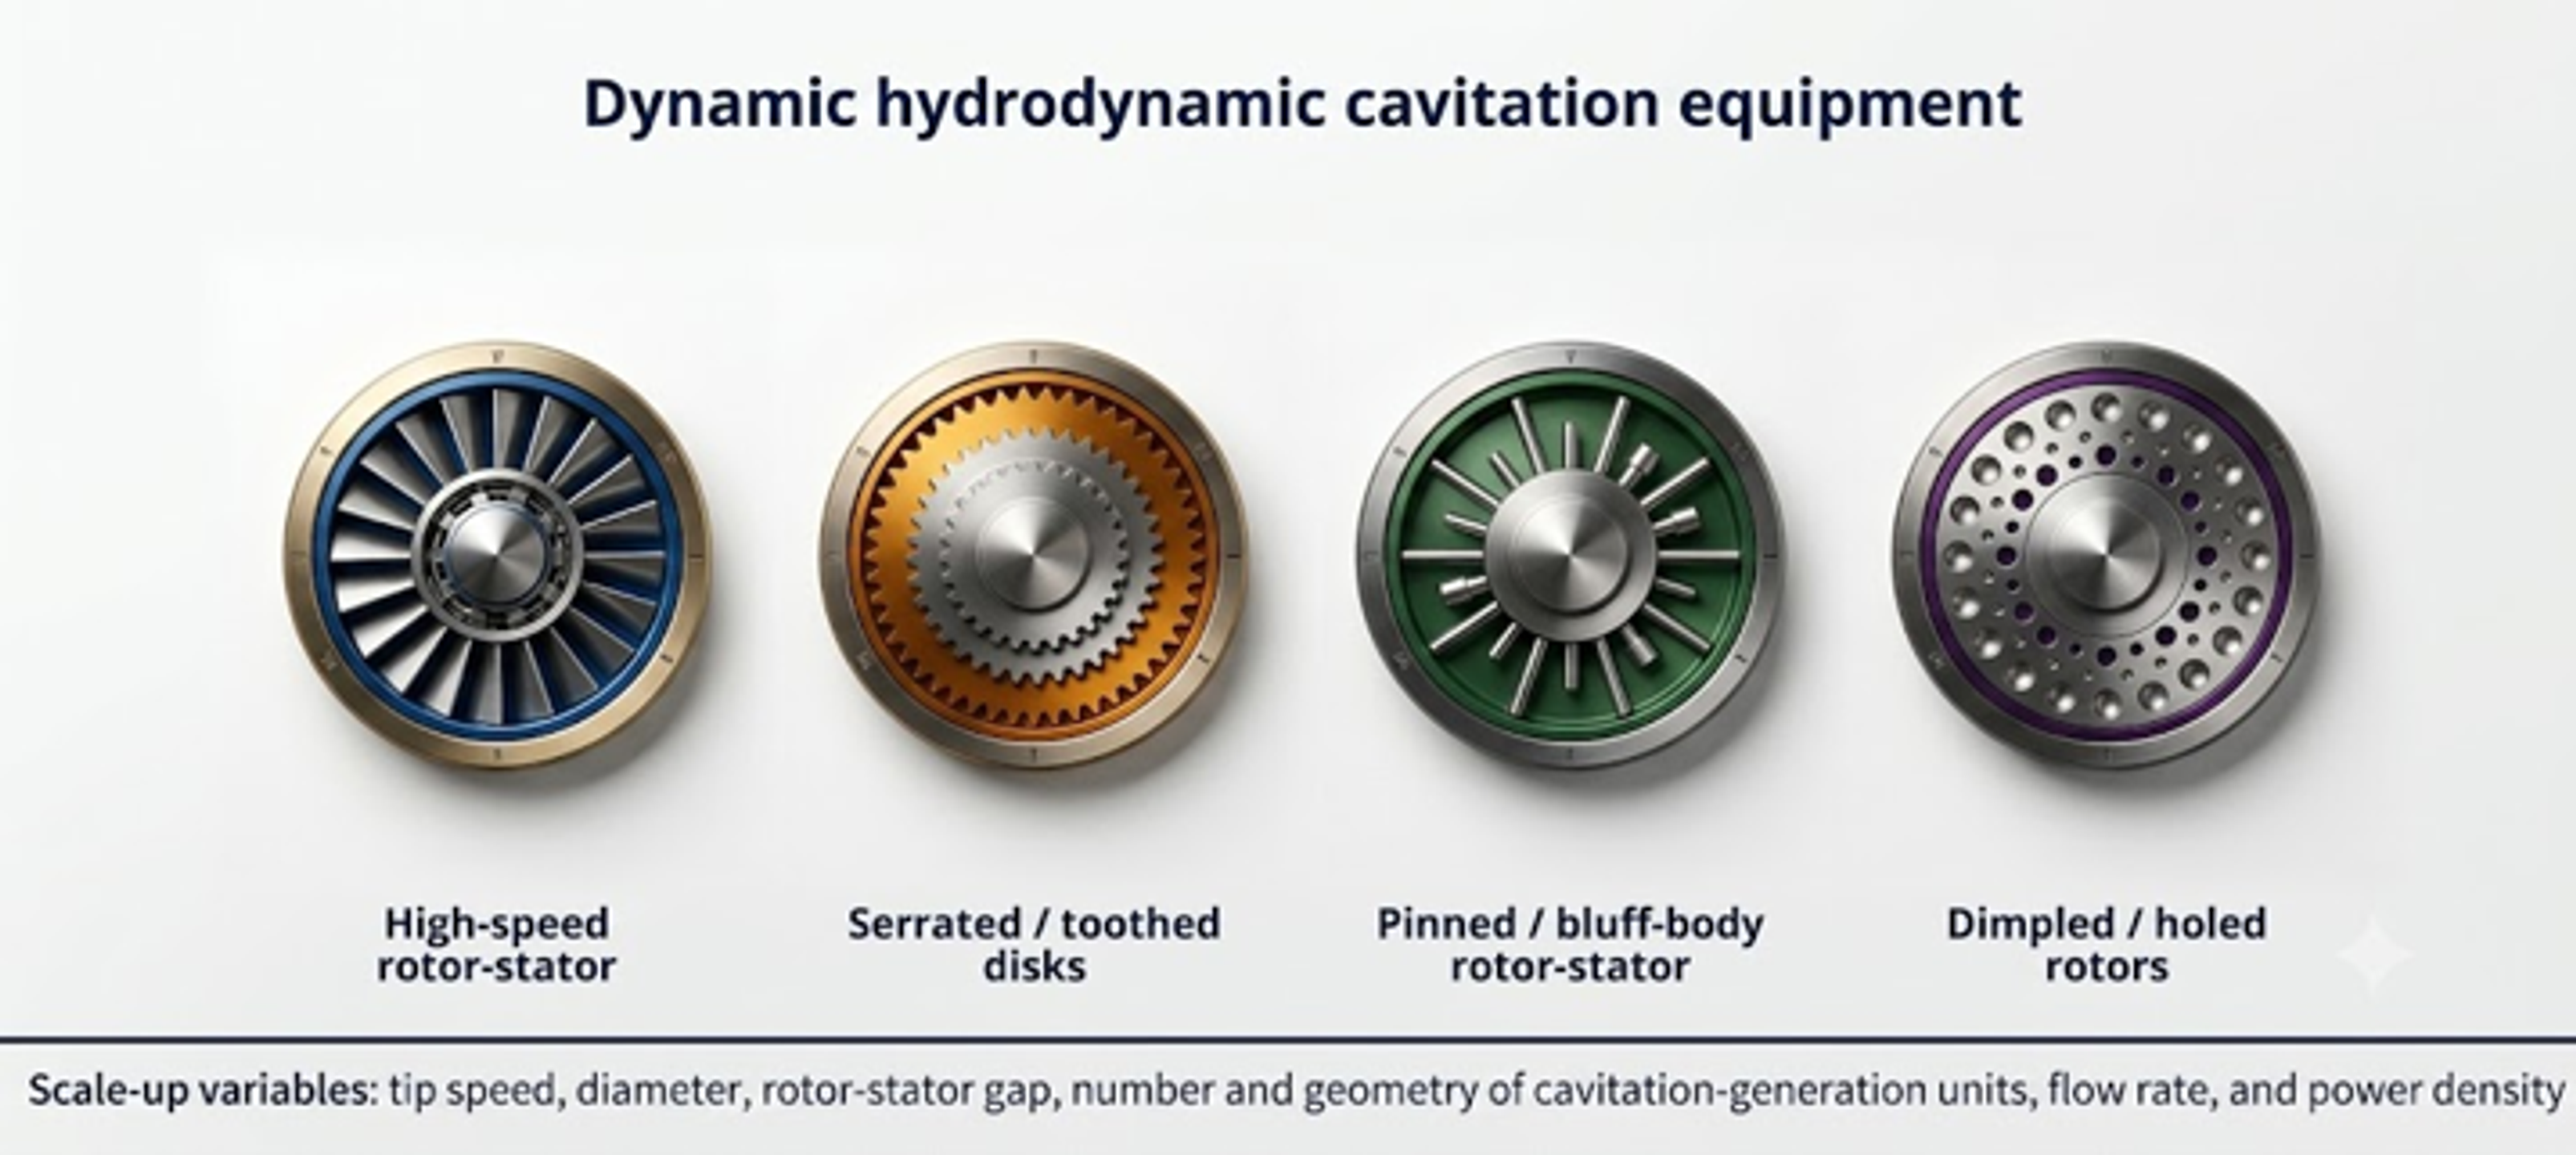
Dynamic hydrodynamic cavitation devices use rotation to generate
repeated pressure depressions, wakes, gap flow, and cavity collapse.
Principal configurations include rotor stator teeth, pins, perforated
disks, dimpled or cavity rotors, serrated disks, high speed impellers,
and rotating cylinders. Some machines combine pumping and cavitation,
whereas others require an external pump to establish axial flow through
the rotor chamber. Rotational speed provides an independent control
variable, but the design calculation must also include shaft power,
torque, clearance, rotor stress, balance, seals, bearings, vibration,
and heat generation [7, 17].
Figure 5.1. Principal dynamic hydrodynamic cavitation device families [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 5.1](#figure-5-1). Principal dynamic hydrodynamic cavitation device families [32].*
A dynamic device should not be sized by rotational speed alone. Machines
operating at the same revolutions per minute can exhibit substantially
different tip speeds, pressure fields, power demand, and cavitation
behavior because rotor diameter, cavity geometry, clearance, flow rate,
chamber pressure, and liquid properties differ. The minimum reproducible
data set should include rotor and stator drawings, diameter, axial and
radial clearances, number and geometry of repeating features, rotational
speed, shaft power or torque, chamber pressure, flow rate, temperature,
gas condition, and pressure tap locations.
### 5.1 Speed, tip velocity, and rotational Reynolds number
Rotational speed in revolutions per second is:
(5.1)
and angular velocity is:
(5.2)
For rotor diameter , tip speed is:
(5.3)
A rotational Reynolds number convenient for similar rotors is:
(5.4)
A tip speed Reynolds number can also be used,
but the definition must not be changed between data sets. Because the
two definitions differ by a factor of , an unlabelled rotational
Reynolds number can cause a substantial comparison error.
A rotor based cavitation number is:
(5.5)
where is a defined bulk or chamber absolute pressure. Equation
(5.5) is an operating index. The local pressure in a cavity, trailing
wake, stator opening, or rotor stator gap depends on the feature
geometry and unsteady interaction. A geometry specific inception
coefficient must be obtained experimentally or through validated CFD.
The tip Mach number is:
(5.6)
where is liquid sound speed. The bulk tip Mach number may be small
while local pressure waves and vapor cloud collapse remain compressible
phenomena. The quantity is useful for screening whether incompressible
mechanical flow assumptions are reasonable outside the collapse zone.
### 5.2 Power number, torque, and motor sizing
The power number is:
(5.7)
where is shaft power transferred to the fluid and mechanical
losses included within the selected boundary. Rearrangement gives:
(5.8)
The dependence makes power extremely sensitive to speed and
scale. Equation (5.8) is valid only when has been calibrated for
the same geometry, clearance, flow coefficient, Reynolds number region,
chamber pressure, gas fraction, and rheology. Extrapolation through
cavitation inception can be inaccurate because vapor changes torque and
flow structure.
Shaft torque is:
(5.9)
The motor should be selected from the maximum required torque and power
over start up, normal operation, maximum viscosity, maximum solids,
cleaning, and upset conditions. A variable frequency drive must satisfy
both continuous current and low speed cooling requirements. The shaft,
key, coupling, and gearbox should be checked against transient torque
and fatigue, not only average power.
Measured electrical power can be converted to estimated shaft power
using a calibrated motor and drive efficiency, but direct torque
measurement is preferable during development. Bearing, seal, windage,
and drive losses under no load should be measured because they can be a
substantial fraction of the total in a small laboratory unit.
### 5.3 Clearance, shear rate, and passage frequency
For a narrow rotor stator gap , the first order Couette shear
rate screen is:
(5.10)
where is relative surface velocity. The actual field includes
pressure driven flow, turbulence, leakage, entrance and exit jets, and
vapor. Equation (5.10) is useful for mechanical and rheological
screening but should not be interpreted as the volume averaged treatment
shear rate.
If identical rotor features pass a stationary reference point
per revolution, the blade or feature passage frequency is:
(5.11)
This frequency can appear in dynamic pressure, vibration, and acoustic
spectra. Sidebands or subharmonics can indicate precession, rotating
cavitation, cloud shedding, or mechanical modulation. The operating
speed should avoid coincidence among passage frequency, shaft frequency,
structural natural frequencies, and piping acoustic modes.
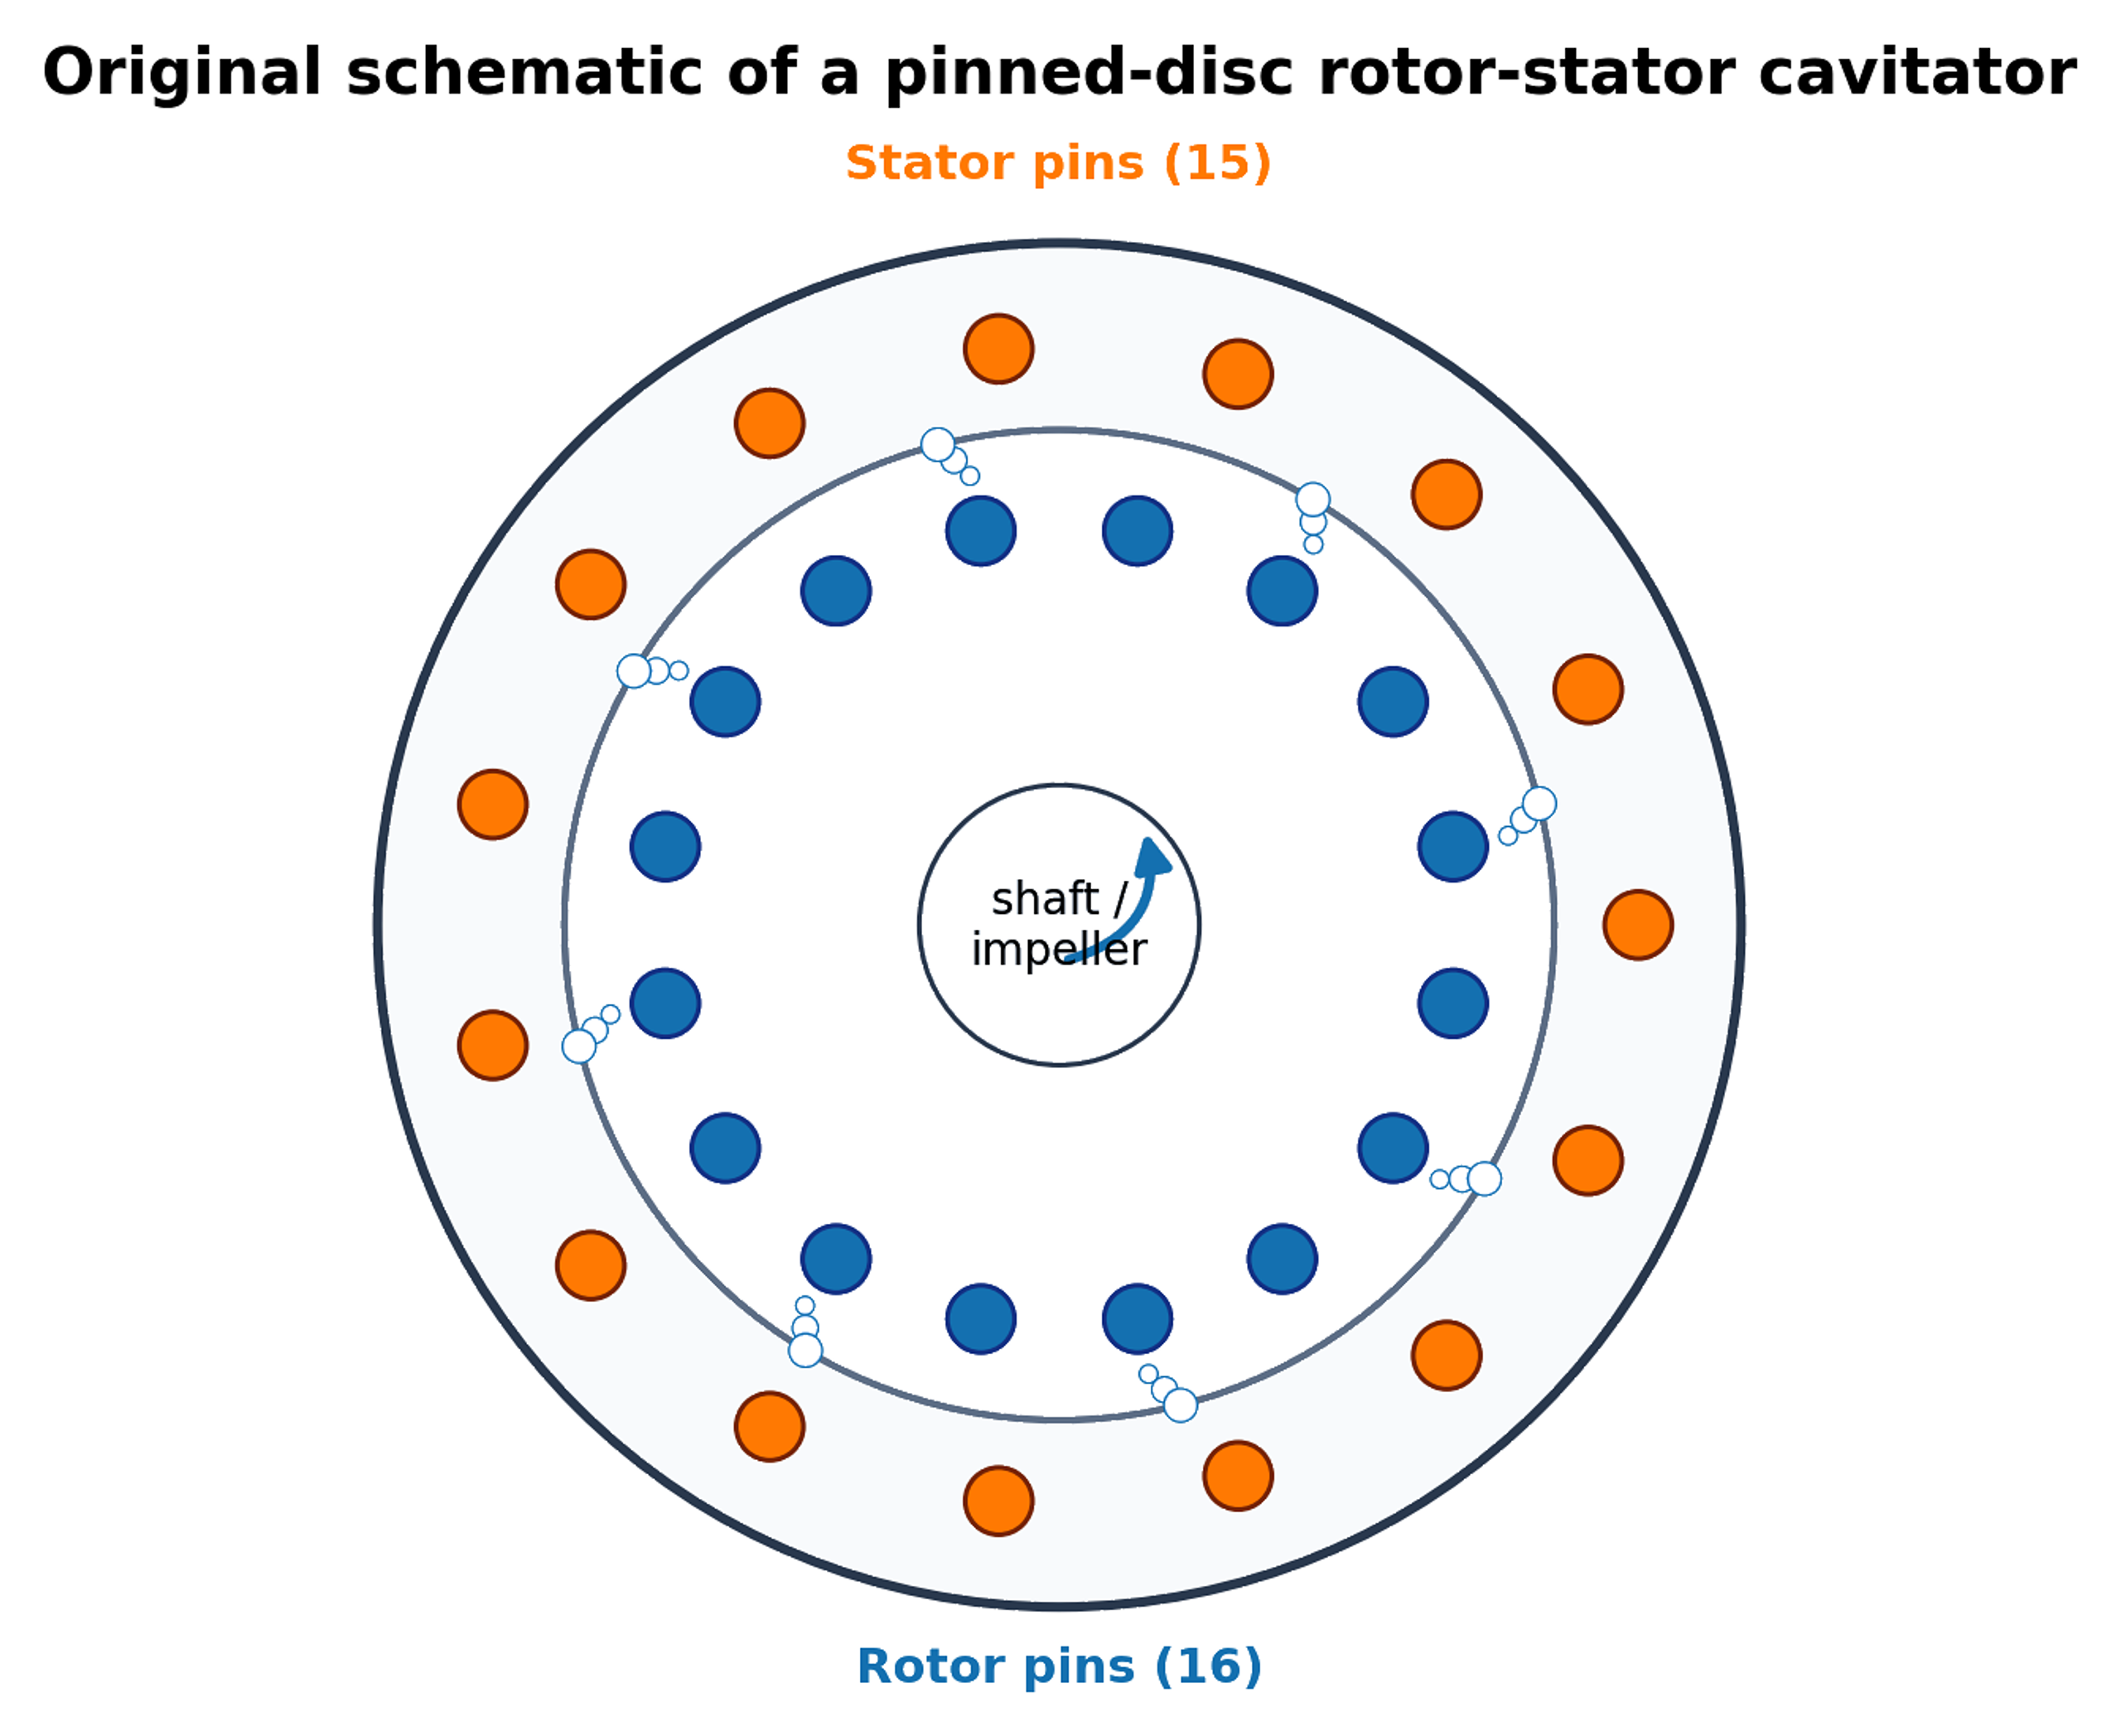
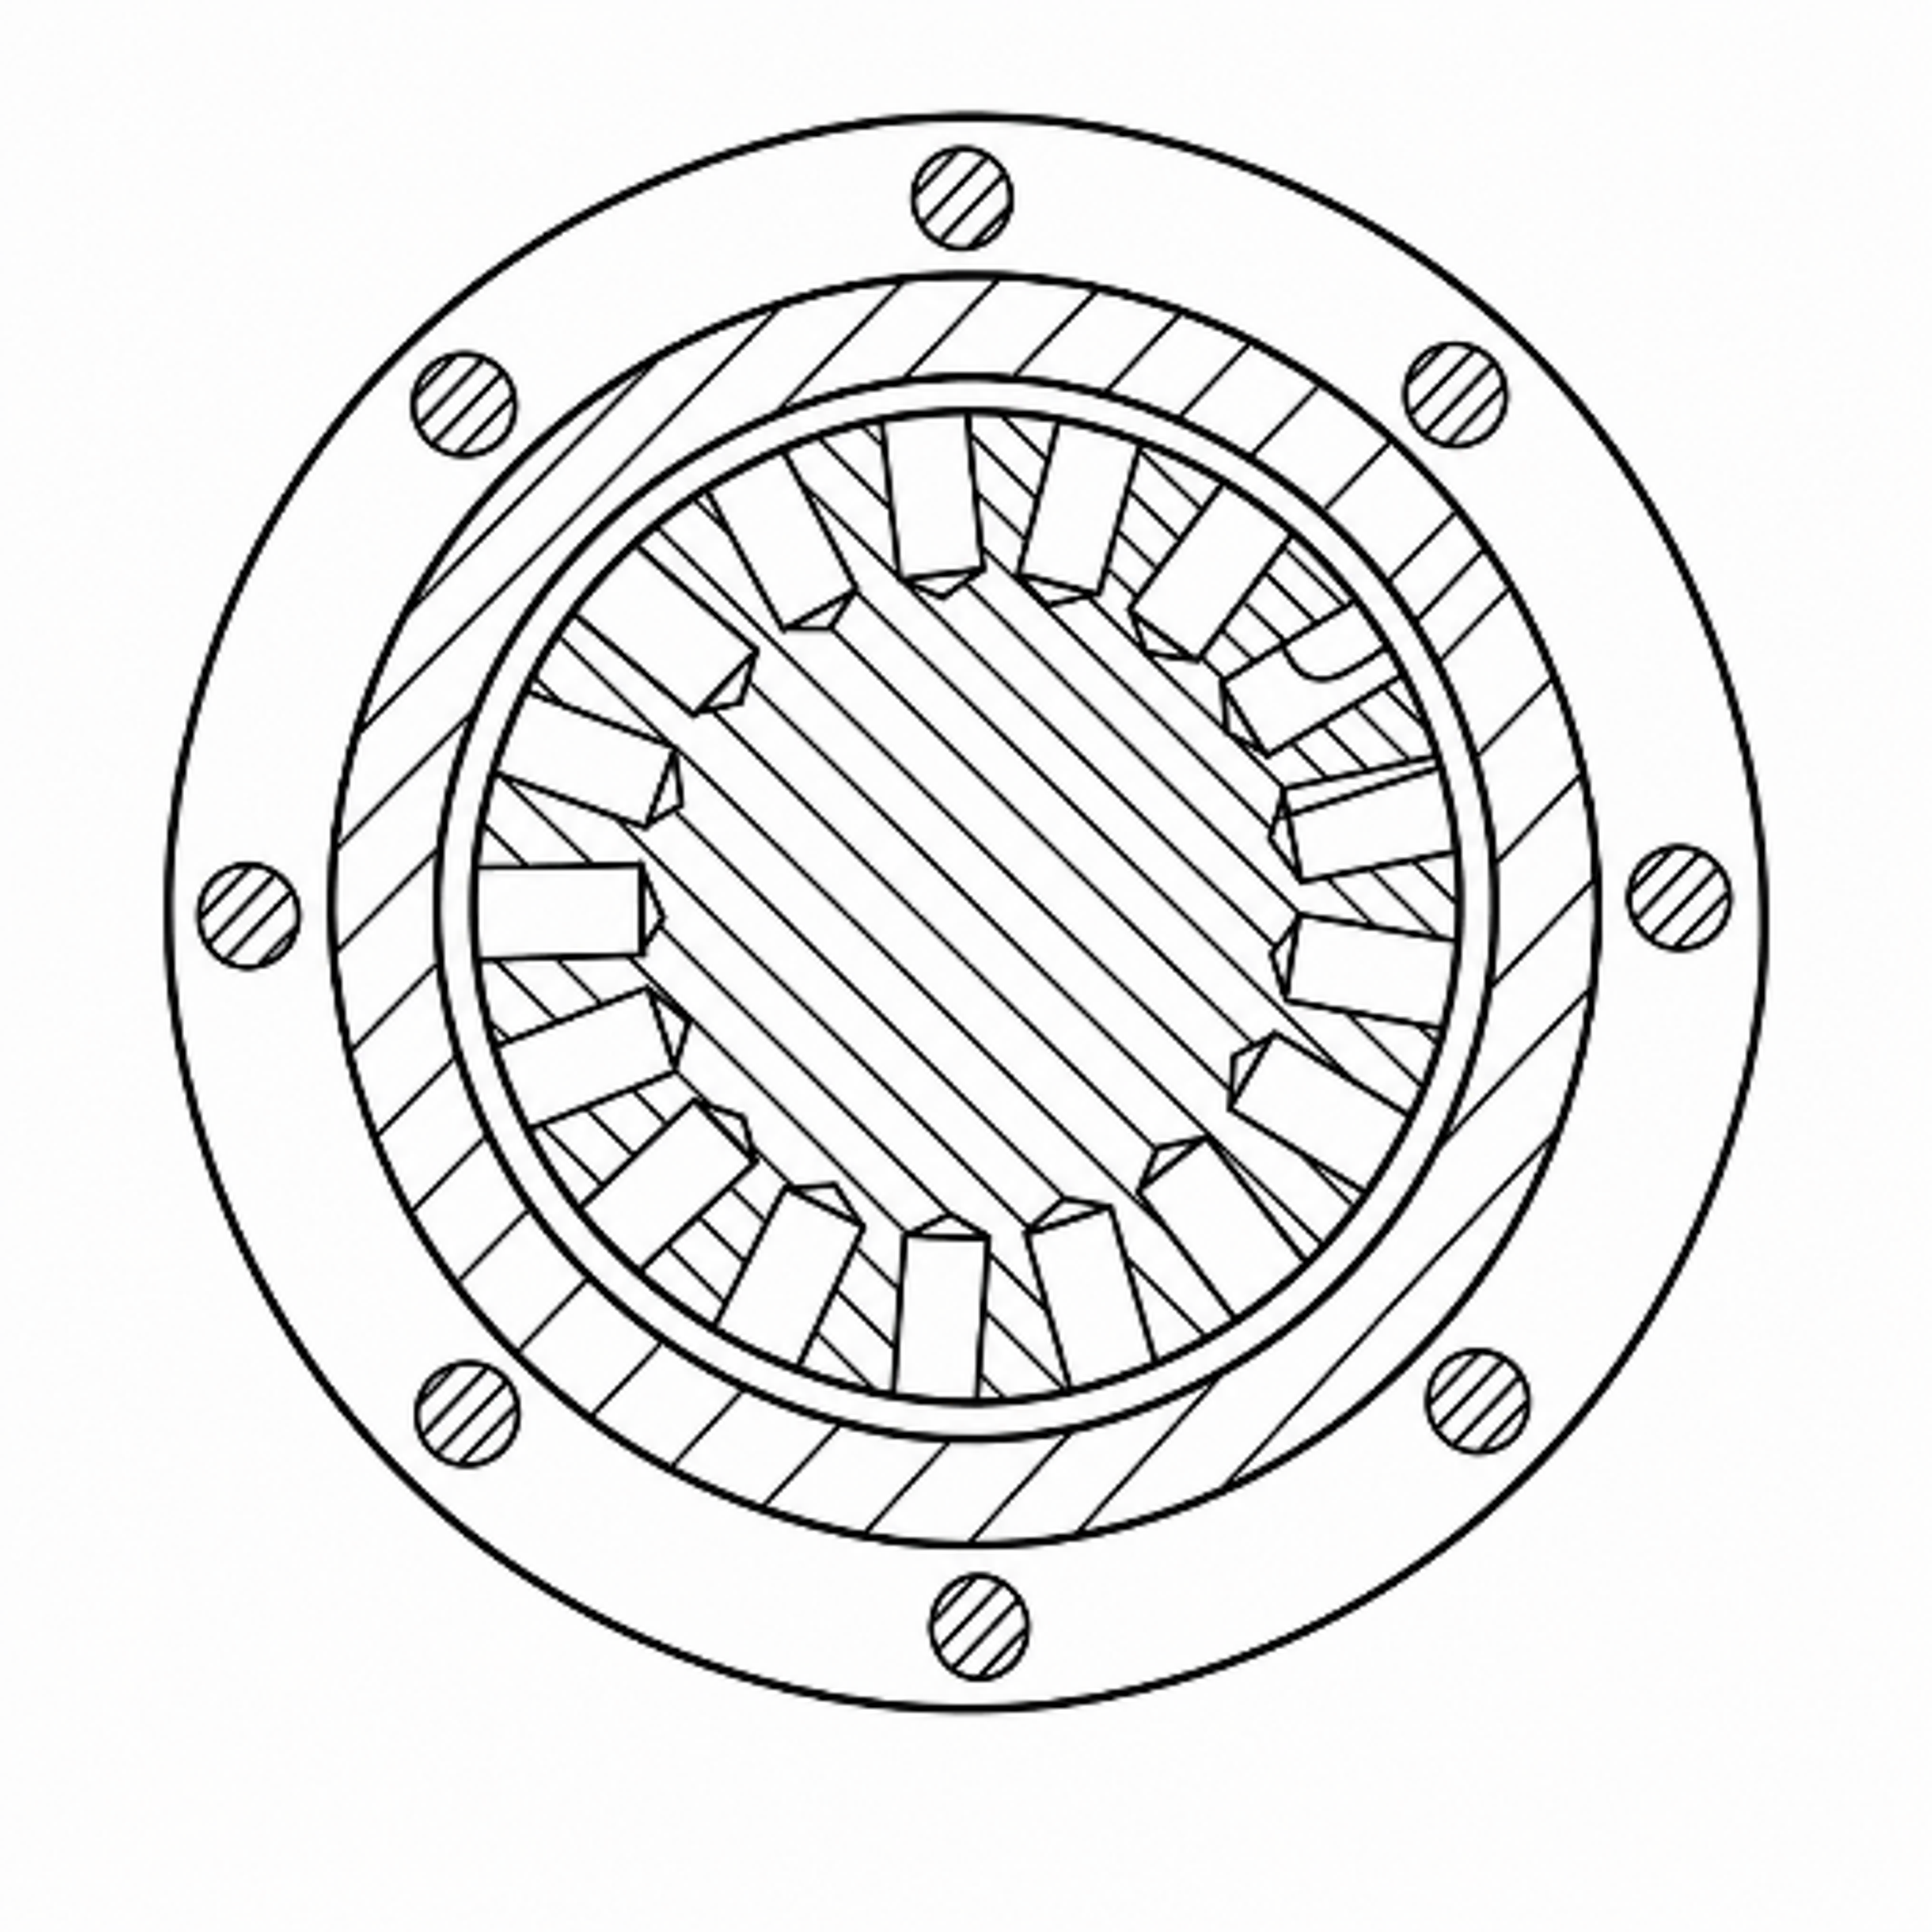
Figure 5.2. Pinned disc rotor and stator geometry and characteristic dimensions used for the worked calculation. [14, 18, 31]Sources: Kozyuk O.V., US Patent 7,178,975 B2 (2007); Christian Thoma, US Patent 7,316,501B2B1 (2004); Kozyuk O., Hydrodynamic Cavitation Technological Equipment (2026).
*[Figure 5.2](#figure-5-2). Pinned disc rotor and stator geometry and characteristic dimensions used for the worked calculation. [14, 18, 31].*
### 5.4 Flow coefficient, pressure coefficient, and energy density
A dimensionless flow coefficient is:
(5.12)
and a pressure or head coefficient is:
(5.13)
where is defined across the rotating device. Matching ,
, , , , clearance ratio ,
and feature ratios gives a more complete similarity basis than matching
tip speed alone. In practice, exact simultaneous matching may be
impossible, so pilot testing should target the most process sensitive
variables.
The mass specific shaft energy for a continuous single pass is:
(5.14)
and an active zone power density can be defined as:
(5.15)
where both the power boundary and active volume must be stated. Dividing
total motor input by the entire loop volume and dividing estimated local
dissipation by a small gap volume produce different quantities. Both can
be useful, but they must not be compared as if they were identical.
### 5.5 Worked Example 5.1: rotor stator operating point
Design basis. A rotor of diameter m operates in water at
25 °C. The selected speed is 2850 rpm, chamber pressure is 150 kPa
absolute, flow is 0.0054 m³/s, gap is 0.8 mm, and the rotor has 12
repeating features. The power number has been calibrated
from a measured shaft power near 5.5 kW for this geometry and flow
regime. Water properties are kg/m³, Pa·s,
and kPa absolute.
Equations (5.1) to (5.3) give s⁻¹, rad/s,
and m/s. Equation (5.4) gives
. Equation (5.5) gives
. The low value indicates a strong rotational
pressure scale, but it does not predict the local vapor fraction.
Equation (5.8) gives kW. Equation (5.9) gives torque
N·m. The gap shear rate screen from Equation (5.10) is
s⁻¹, and Equation (5.11) gives a feature passage
frequency of 570 Hz. Equation (5.14) gives a single pass shaft energy of
approximately 1022 J/kg. The flow coefficient is .
*Table 5.1. Worked Example 5.1 results.*
| **Quantity** | **Result** | **Interpretation** |
|----------------------------|--------------------------|-----------------------------------------------------------------------------------|
| Rotational speed | 2850 rpm; 47.5 s⁻¹ | Speed must be paired with rotor diameter |
| Tip speed | 28.35 m/s | Governs the selected rotational pressure scale |
| Rotational Reynolds number | | Based on |
| Rotor cavitation number | 0.366 | Uses chamber pressure and tip speed; geometry specific calibration still required |
| Calibrated power number | 0.208 | Applicable only to the tested geometry and regime |
| Shaft power | 5.50 kW | Excludes motor and drive losses unless calibrated otherwise |
| Shaft torque | 18.4 N·m | Basis for coupling and shaft checks, with service factor |
| Gap shear rate screen | s⁻¹ | Couette estimate, not a resolved local field |
| Passage frequency | 570 Hz | Compare with vibration and acoustic spectra |
| Flow coefficient | 0.0166 | Required for similarity comparisons |
| Single pass shaft energy | 1.02 kJ/kg | Relates energy to continuous throughput |
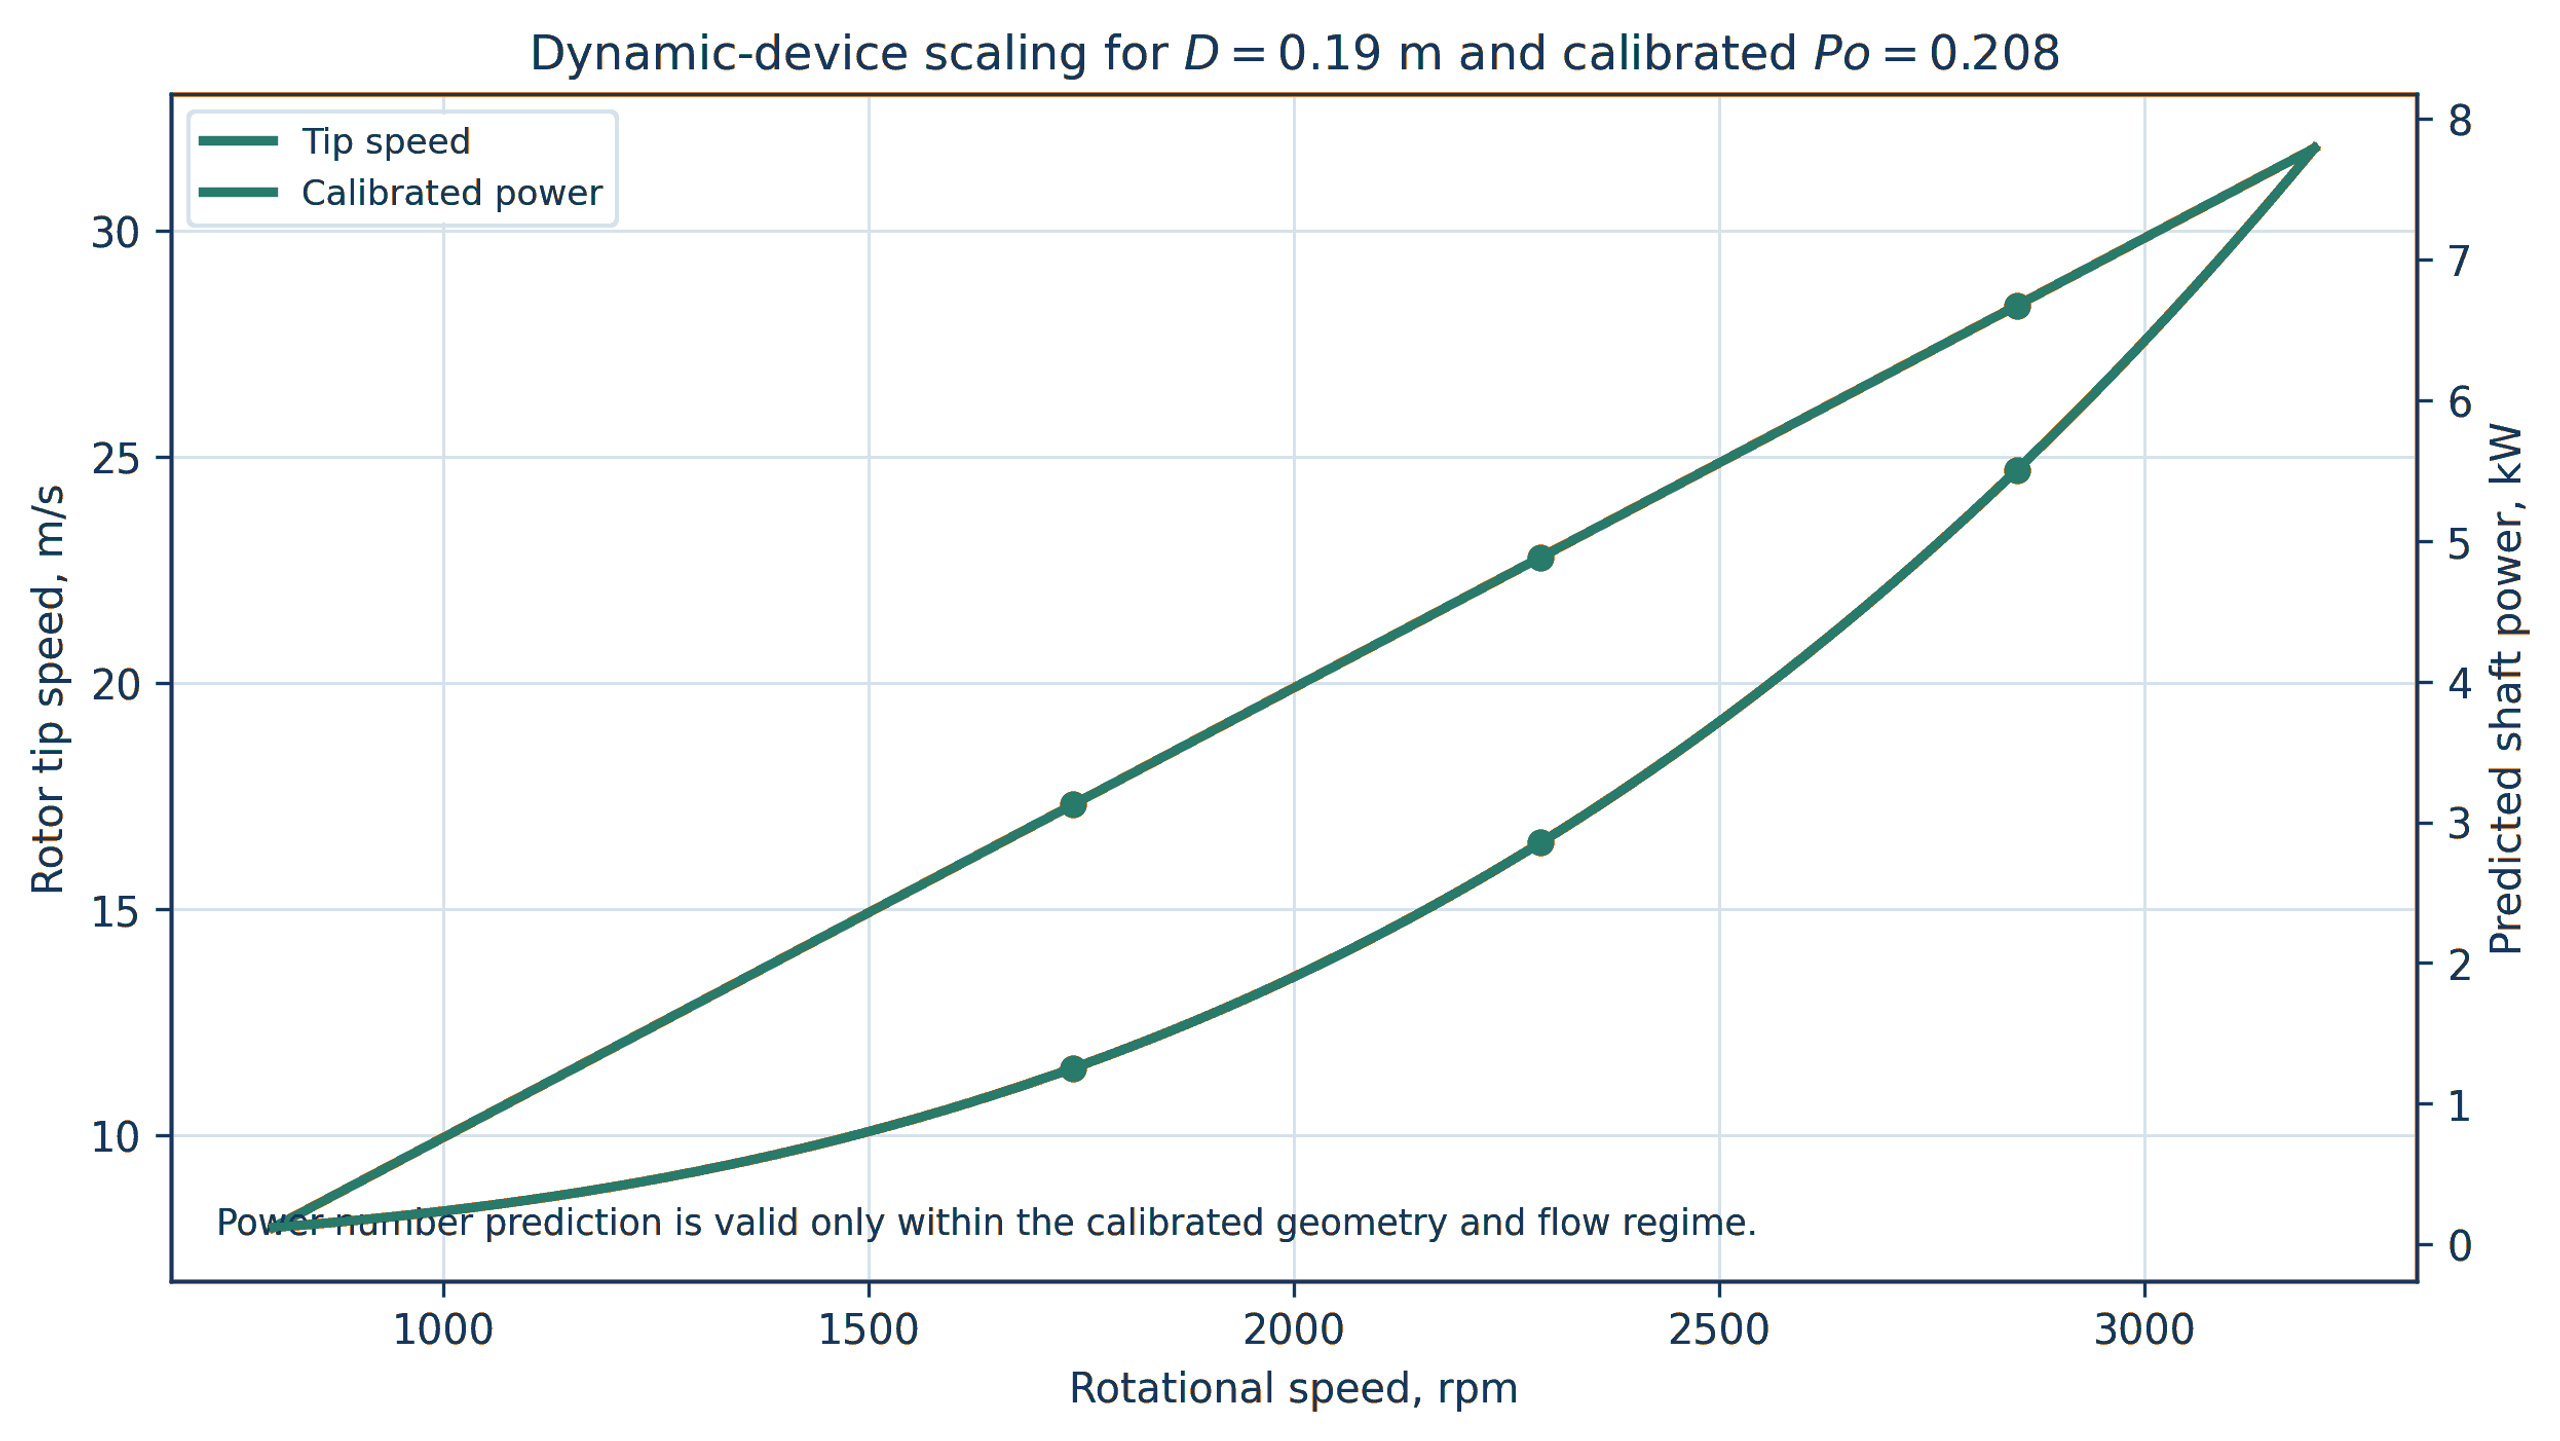
Using the same calibrated without changing geometry or flow regime
gives approximately 1.25 kW at 1740 rpm and 2.86 kW at 2290 rpm. The
cubic speed dependence is shown in [Figure 5.3](#figure-5-3). These predictions should
be checked against measured torque because can change with flow
coefficient, clearance, vapor fraction, and rheology.
Figure 5.3. Tip speed and shaft power versus speed for Worked Example 5.1 using D_r = 0.19 m and calibrated Po = 0.208. Calculation. Power number extrapolation is valid only within the calibrated geometry and flow regime [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 5.3](#figure-5-3). Tip speed and shaft power versus speed for Worked Example 5.1 using D_r = 0.19 m and calibrated Po = 0.208. Calculation. Power number extrapolation is valid only within the calibrated geometry and flow regime [32].*
### 5.6 Clearance budget and mechanical tolerance
A small clearance can increase velocity gradients and rotor stator
interaction, but it creates a mechanical tolerance problem. The minimum
running gap must exceed the combined effects of rotor and stator
manufacturing tolerance, shaft runout, bearing clearance, assembly
eccentricity, rotor deflection, pressure deformation, thermal expansion,
transient vibration, and allowable wear. A practical clearance budget
can be written:
(5.16)
where every term is a one sided radial or axial allowance defined for
the actual stack up. Statistical tolerance methods may be used for
independent manufacturing variables, but worst case combinations are
appropriate where rotor contact has severe consequences.
Thermal growth must be calculated for the rotor, shaft, housing, and
stator using their temperatures and coefficients of thermal expansion.
The rotor can heat faster than the housing during start up, while a cold
clean in place rinse can reverse the gradient. The gap should be
verified at assembly temperature, normal operation, maximum process
temperature, and cleaning transitions.
### 5.7 Rotor stress, balance, and critical speed
For a thin free ring, a first order circumferential stress screen is:
(5.17)
where is rotor material density. Real disks, pins, holes,
cavities, keys, hubs, and welds require a detailed rotating stress
solution. Stress concentration, low and high cycle fatigue, corrosion
fatigue, residual stress, overspeed, and loss of material by erosion
must be included. Finite element analysis should use the minimum
remaining section after the specified inspection interval.
Rotors should be dynamically balanced in the final assembly condition,
including pins, fasteners, coatings, and replaceable elements.
Cavitation erosion can change balance during service. Vibration
monitoring should include shaft frequency, feature passage frequency,
bearing frequencies, and broadband cavitation content. A speed sweep
should identify structural resonances before prolonged cavitating
operation.
### 5.8 Cleanability, disassembly, and wear components
A device designed for viscous, fibrous, food, pharmaceutical, or fouling
service requires access to the active geometry. Replaceable rotors,
stator rings, wear plates, and collapse inserts can reduce lifecycle
cost and prevent the pressure boundary from becoming a sacrificial
surface. Disassembly should preserve alignment and repeatable clearance.
Crevices, blind holes, gasket intrusion, and trapped pressure must be
eliminated or controlled.
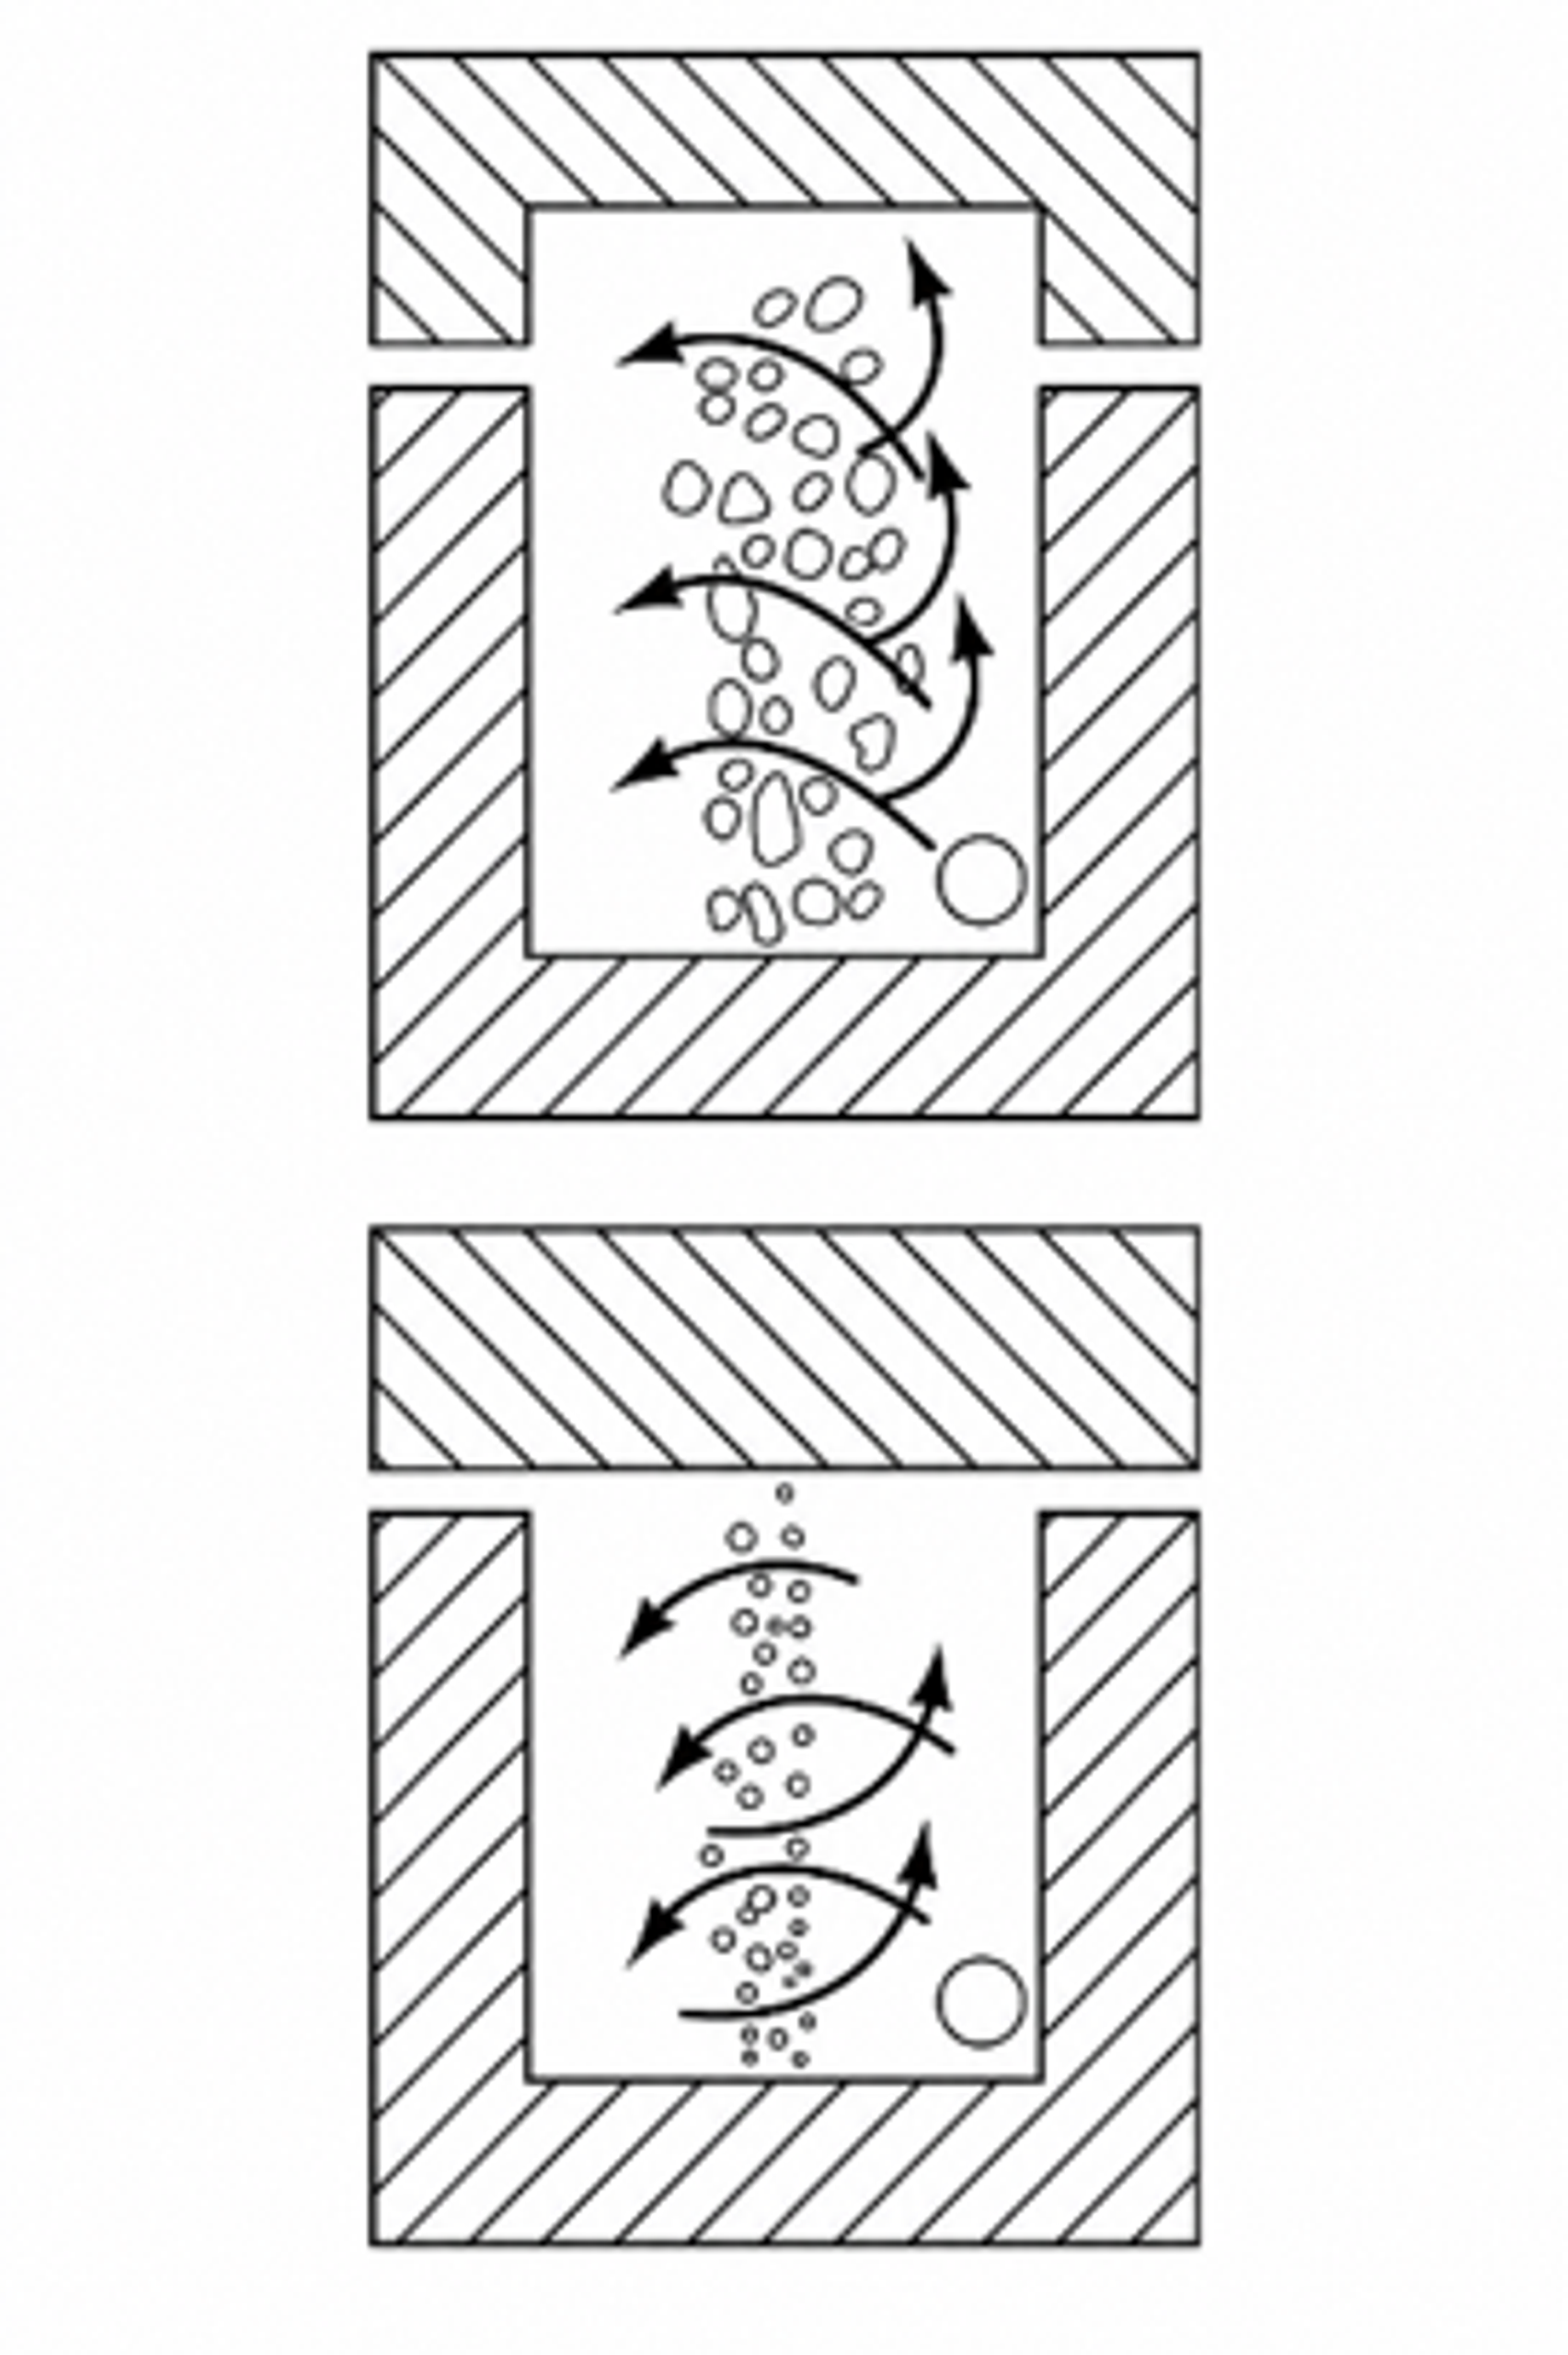
Figure 5.4. Holed rotor controlled cavitation device arranged for disassembly and cleaning. [18]Source: Christian Thoma. Apparatus and method for mixing dissimilar fluids. US Patent 7,316,501B2B1, 2004.
*[Figure 5.4](#figure-5-4). Holed rotor controlled cavitation device arranged for disassembly and cleaning. [18].*
### 5.9 Dynamic device calculation workflow
The recommended workflow is:
- Define flow, pressure, temperature, rheology, gas, solids, product
objective, and hygienic requirements.
- Select rotor diameter, feature family, number of features, chamber
volume, and preliminary clearance.
- Calculate tip speed, , , , feature passage
frequency, and mechanical clearance budget.
- Obtain a non cavitating torque and flow map over speed and flow.
- Identify cavitation inception using pressure, acoustic, vibration,
visualization, and power changes.
- Fit and any geometry specific inception or pressure coefficient
within the validated region.
- Measure product response and temperature at the same operating points.
- Complete rotor stress, shaft, bearing, seal, pressure boundary,
fatigue, overspeed, and balance calculations.
- Run an endurance test with dimensional inspection, vibration trending,
and contaminant analysis.
- Scale by a defined similarity set or preserve the validated rotor
module through parallel scale out.
*Table 5.2. Required dynamic device calculation outputs.*
| **Discipline** | **Required output** |
|-----------------|----------------------------------------------------------------------------------------------|
| Hydraulics | Flow pressure map, chamber absolute pressure, inlet and outlet losses, residence time |
| Rotation | Speed range, tip speed, , , , , passage frequency |
| Power | No load loss, shaft torque, , electrical input, specific energy, heat balance |
| Mechanical | Rotor and shaft stress, overspeed margin, critical speeds, balance grade, clearance stack up |
| Tribology | Seal face condition, bearing load, lubricant isolation, galling and rub assessment |
| Process | Product response surface, temperature history, gas condition, pass or staging dependence |
| Integrity | Erosion map, minimum remaining thickness, vibration trend, metal contamination |
| Sanitary design | Surface finish, drainability, clean in place coverage, disassembly validation |
## 6 Selection of Structural Materials
Structural material selection for a cavitation device cannot be reduced
to a single alloy ranking. The pressure boundary, cavitation generating
insert, rotor, shaft, wear plate, fastener, seal face, gasket, and
product contact surface perform different functions. Pressure retaining
walls require weldability and code allowable stress; removable inserts
require erosion resistance and dimensional stability; rotors require
fatigue strength and balance; and sanitary surfaces require corrosion
resistance, cleanability, low metal release, and controlled finish.
Assigning all functions to one material can increase cost while reducing
lifecycle performance [22–27].
The preferred design strategy first controls the hydraulic collapse
location, then assigns replaceable wear components, and only afterward
considers alloy or coating upgrades. No practical material is immune to
sufficiently aggressive cavitation. A hard surface may resist plastic
indentation but fail by brittle cracking or coating delamination. A
corrosion resistant alloy can repeatedly lose its passive film under
impact, while a tough alloy may deform and work harden but release
metal. Material selection must therefore reflect the actual chemistry,
temperature, solids, gas content, pressure history, geometry, permitted
contamination, and inspection interval [23–25].
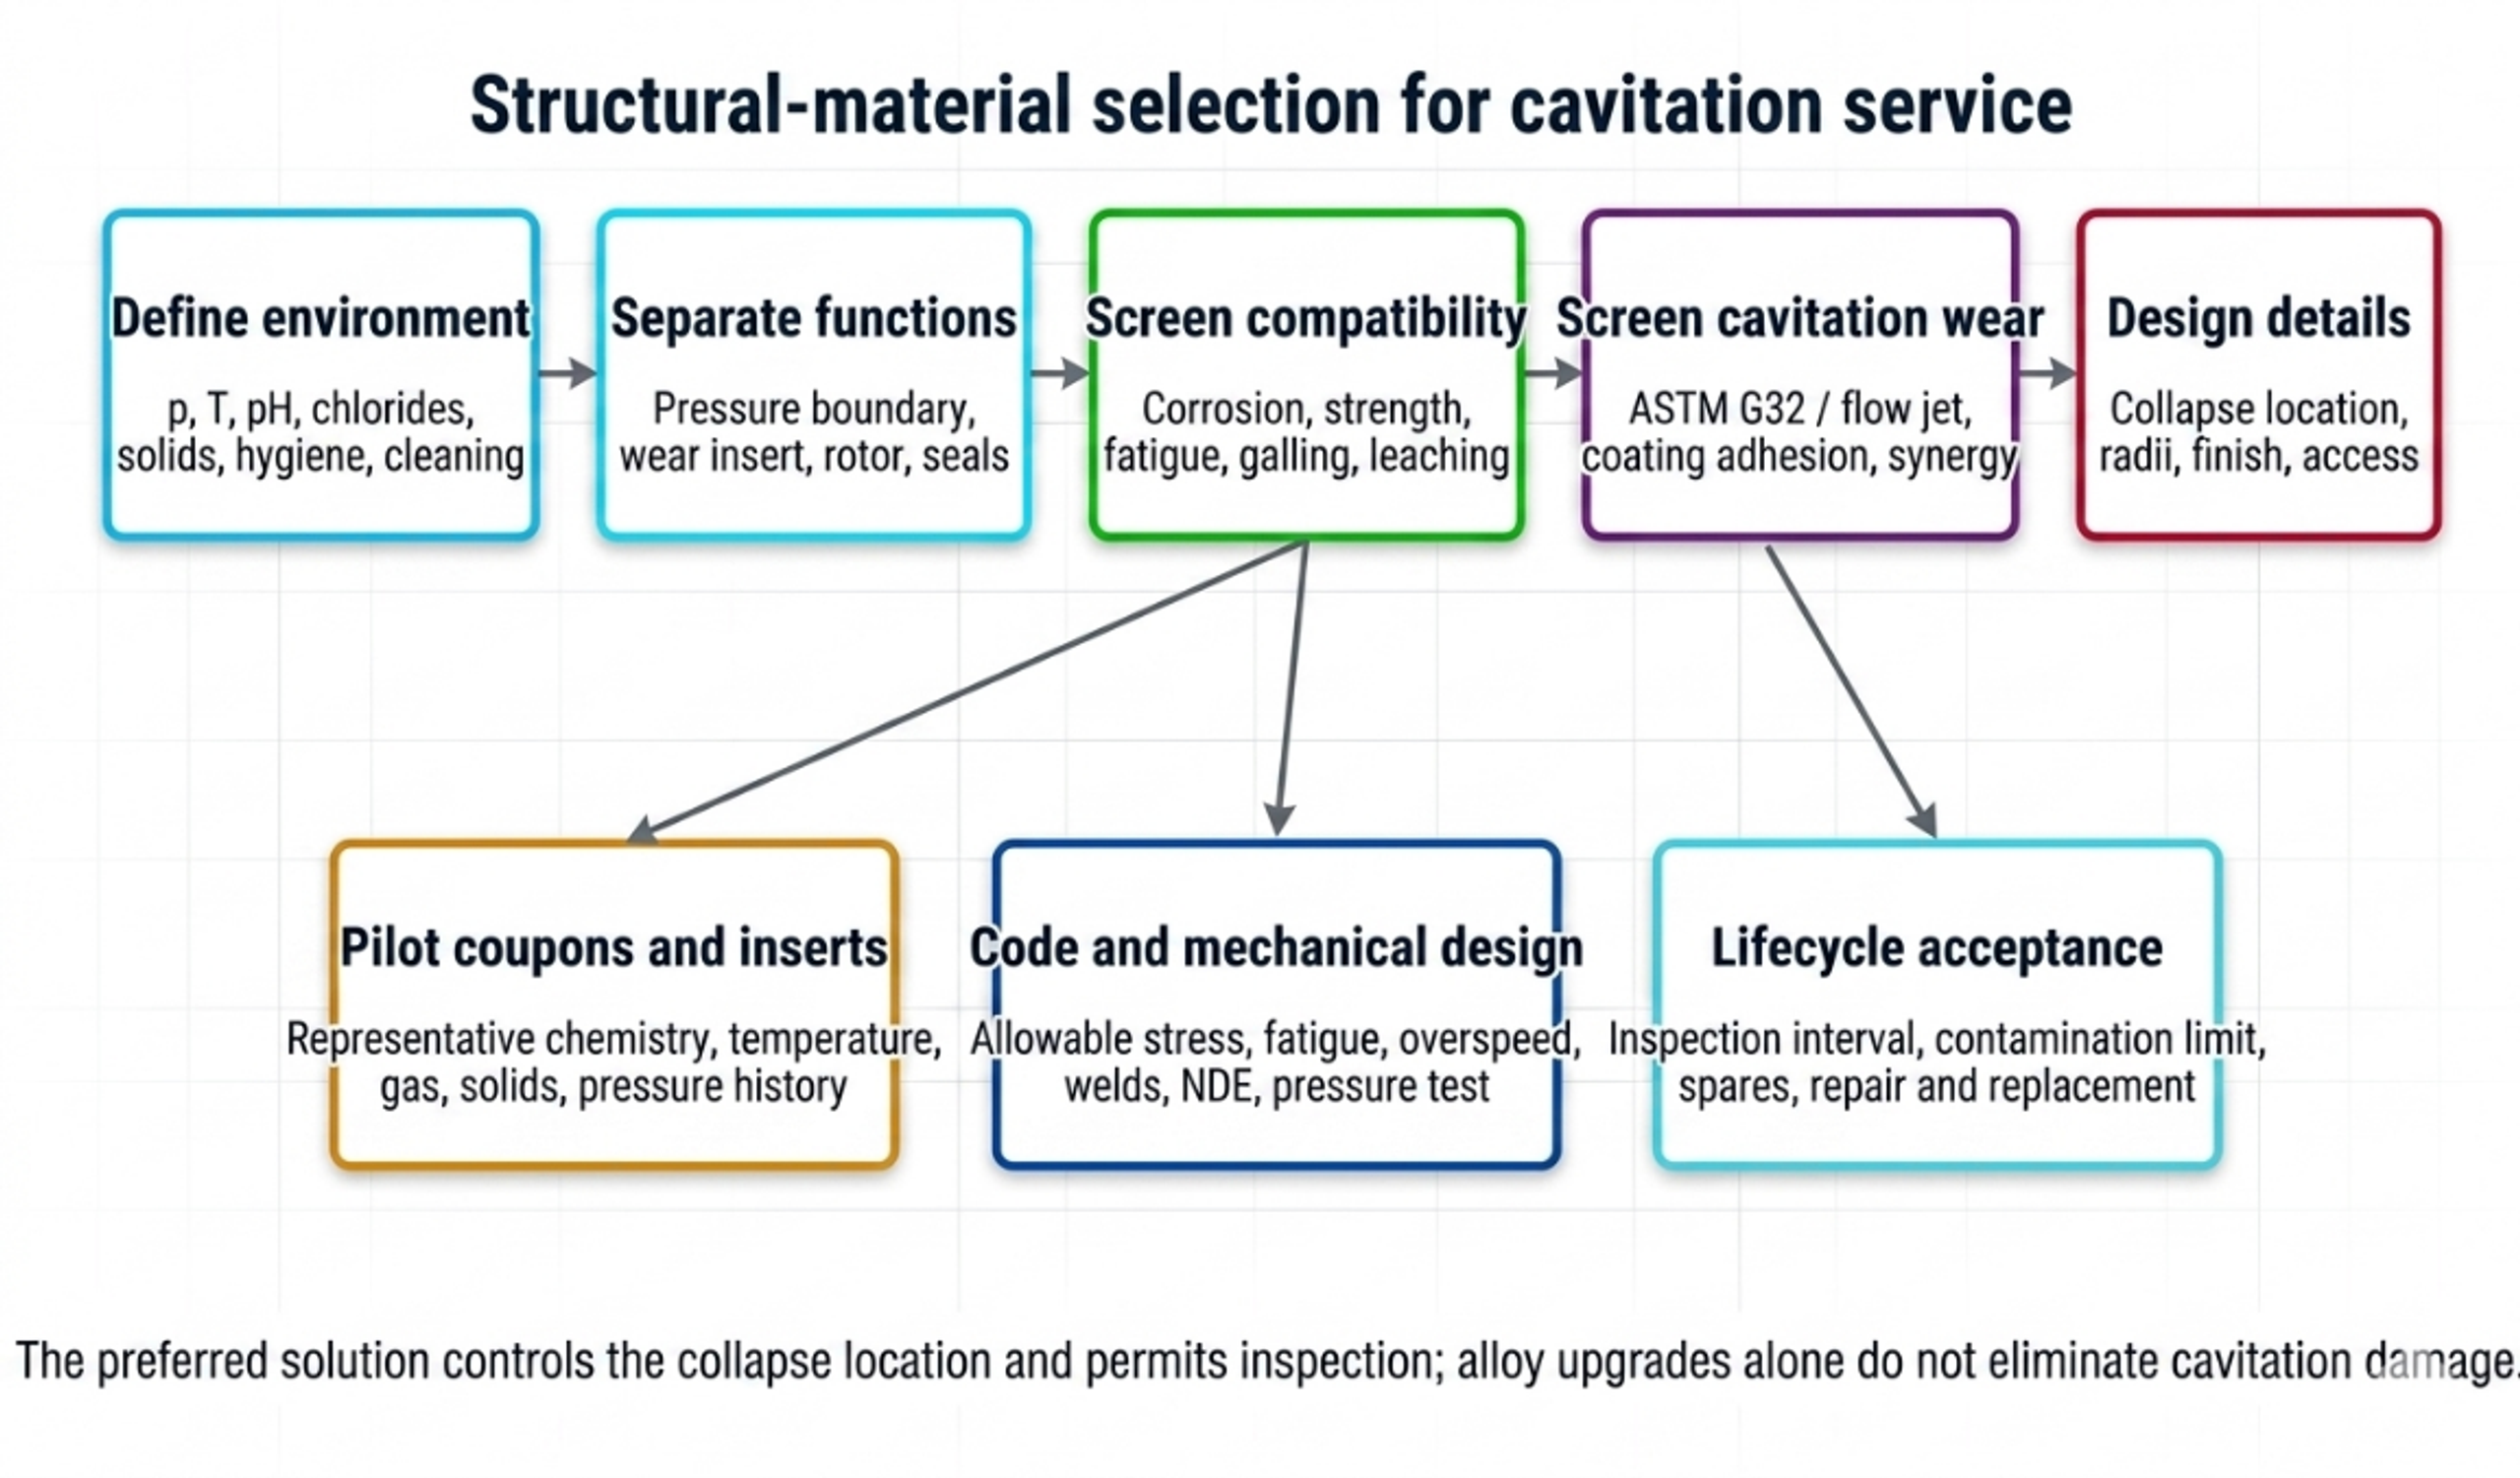
Figure 6.1. Structural material selection workflow for hydrodynamic cavitation equipment [32]Source: Kozyuk O. Hydrodynamic Cavitation. Unpublished technical manuscript and supporting data, 2026.
*[Figure 6.1](#figure-6-1). Structural material selection workflow for hydrodynamic cavitation equipment [32].*
### 6.1 Functional decomposition of the device
The calculation package should identify the material function of every
component:
**Pressure boundary:** contains maximum allowable working pressure,
relief pressure, vacuum, thermal load, and piping reaction.
**Cavitation insert or throat:** defines the hydraulic geometry and may
be intentionally replaceable.
**Collapse chamber or wear plate:** receives the highest expected
microjet and cloud collapse loading.
**Rotor and shaft:** resist centrifugal stress, torque, fatigue,
corrosion, and erosion while maintaining balance.
**Stator and clearance surfaces:** maintain geometry under pressure,
temperature, and possible rub.
**Seals, gaskets, and bearings:** remain compatible with chemistry and
temperature while preventing product contamination.
**Welds and heat affected zones:** meet pressure code, corrosion,
fatigue, and surface finish requirements.
**Instrumentation connections:** avoid crevices, dead legs, thin
diaphragms exposed to collapse, and plugged impulse lines.
A replaceable insert allows the pressure shell to be selected primarily
for code, corrosion, and fabrication, while the wear component is
selected for cavitation exposure. The insert should have positive
location, repeatable dimensions, no bypass leakage, and an inspection
datum. Its failure must not release a loose part into downstream
equipment.
### 6.2 Pressure boundary screening
For a cylindrical wall under internal pressure, a simplified thin wall
screen can be written:
(6.1)
where is design pressure, is the selected diameter basis, is
allowable stress, and is weld joint efficiency. Equation (6.1) is
only a preliminary screen. Final thickness, reinforcement, flange
rating, fatigue, external pressure, nozzle loads, weld details,
examination, testing, and material allowable must comply with the
applicable pressure vessel or piping code, such as ASME BPVC Section
VIII or ASME B31.3 [26, 27].
A practical nominal thickness expression is:
(6.2)
where is code required thickness, is corrosion
allowance, is a justified erosion allowance, is
machining or resurfacing allowance, and is the negative mill
tolerance fraction. An erosion allowance should not replace inspection
or a wear insert when cavitation attack is localized.
#### Worked structural screen
For MPa, m, MPa, and ,
Equation (6.1) gives mm. This small value illustrates
only membrane pressure demand. It is not a final wall thickness. A real
device may require substantially more thickness for code minimums,
threading, nozzles, flange loads, cyclic pressure, vibration,
manufacturing tolerance, corrosion, erosion, and rigidity needed to
preserve a small internal clearance.
### 6.3 Cavitation erosion and erosion corrosion interaction
Cavitation erosion is produced by repeated pressure pulses, microjets,
cloud collapse, and associated cyclic deformation. The incubation period
may show little measurable mass loss while subsurface fatigue
accumulates. It can be followed by an accelerating stage, a maximum
rate, and a later rate modified by roughness and the evolving flow. A
single test duration can therefore misrepresent long term behavior [23,
24].
ASTM G32 provides a vibratory apparatus method for comparative
cavitation erosion testing [23]. Its output is valuable for screening
materials, heat treatments, and coatings under controlled conditions,
but it should not be converted directly into plant service life. A
hydrodynamic device has different impact frequency, bubble cloud scale,
pressure recovery, chemistry, temperature, solids, and wall geometry.
The strongest program combines standardized comparison, a representative
flow test, and pilot inserts in the actual process.
Mean depth of erosion calculated from mass loss is:
(6.3)
where is mass loss, is solid density, and
is exposed area. The mean depth penetration rate is:
(6.4)
A combined erosion corrosion loss may be expressed conceptually as:
(6.5)
where is purely mechanical cavitation loss, is
corrosion loss without cavitation, and is the interaction
term. The interaction can be positive because impact removes passive
films and corrosion weakens the surface, but the sign and magnitude must
be measured for the actual environment [24].
For an observed approximately linear penetration rate after incubation,
a remaining life screen is:
(6.6)
where is the maximum permitted local penetration and
is measured penetration. This calculation is valid only when
the rate is stable and the measured location corresponds to the most
severe attack. Local pits or crack like defects may govern before
average depth.
### 6.4 Material property requirements
Cavitation resistance is influenced by hardness, yield strength, strain
hardening, toughness, fatigue behavior, elastic modulus, microstructure,
residual stress, phase stability, corrosion resistance, surface finish,
and defect population. No single property predicts performance across
all regimes. The desired combination is a surface that resists repeated
indentation and cracking, a substrate that supports the surface without
excessive deformation, and a chemistry that maintains passivity or
avoids rapid dissolution [24, 25].
Material screening should consider:
**Strength and fatigue:** pressure cycles, rotor stress, passage
frequency loading, and vibration.
**Toughness:** resistance to crack initiation and propagation under
repeated impact.
**Hardness and work hardening:** resistance to plastic indentation, with
attention to brittle failure.
**Corrosion:** uniform corrosion, pitting, crevice corrosion, stress
corrosion cracking, galvanic coupling, and corrosion fatigue.
**Fabrication:** weldability, heat treatment, distortion, machinability,
repair, and nondestructive examination.
**Surface condition:** roughness, inclusions, machining marks, weld
profile, coating defects, and residual stress.
**Process compatibility:** extractables, toxic metal limits, food or
pharmaceutical conformity, product discoloration, and catalyst
poisoning.
**Lifecycle:** cost, lead time, replaceability, inspection method, and
disposal or repair.
### 6.5 Candidate metallic materials
*Table 6.1. Qualitative material selection matrix for cavitation
devices.*
| **Material family** | **Potential role** | **Principal advantages** | **Principal cautions** |
|--------------------------------------------------------|-------------------------------------------------------------------|-----------------------------------------------------------------------|-------------------------------------------------------------------------------------------------------------------------|
| Carbon and low alloy steel | External pressure shell or nonhygienic benign service | Low cost, strength, weldability, code familiarity | Corrosion products, product contamination, localized erosion corrosion, coating dependence |
| 304L austenitic stainless steel | Mild sanitary or water service | Fabricability, cleanability, availability | Lower chloride pitting margin than Mo bearing grades; not immune to cavitation |
| 316L austenitic stainless steel | Common hygienic pressure boundary and wetted components | Weldability, cleanability, improved pitting resistance over 304L | Can pit or crevice corrode in hot chlorides; moderate hardness; erosion can remove passive film |
| Duplex stainless steel 2205 | Higher strength chloride service, pressure parts, selected rotors | Higher strength and chloride resistance than common austenitic grades | Phase balance and welding control; surface finishing and hygienic qualification require care |
| Super duplex or high alloy austenitic steel | Severe chloride or oxidizing aqueous service | High pitting and crevice corrosion resistance | Cost, fabrication control, availability, possible over specification if erosion dominates |
| Martensitic or precipitation hardening stainless steel | Shafts, rotors, replaceable wear parts | Higher strength and hardness after heat treatment | Lower corrosion resistance in some chemistries; heat treatment control; not automatically suitable for sanitary contact |
| Nickel base corrosion resistant alloy | Strong acids, mixed chemicals, severe corrosion | Broad corrosion resistance in selected environments | High cost, galling, density, weld procedure, chemistry specific limitations |
| Titanium alloy | Chloride rich service, low density rotor or wetted component | Low density and strong passive behavior in many chloride environments | Galling, galvanic coupling, hydrogen effects, fabrication cost; cavitation resistance remains condition dependent |
| Cobalt base or nickel base hard facing | Local replaceable wear surface | Hardness, work hardening or high temperature wear capability | Cracking, dilution, repair, cost, possible metal release restrictions |
| Copper alloy | Specialized marine or antimicrobial service | Thermal conductivity and selected seawater applications | Metal release, galvanic effects, chemistry limitations, generally unsuitable where copper contamination is unacceptable |
The table is a screening matrix, not a substitution rule. The specific
grade, product form, heat treatment, weld, surface finish, and service
chemistry determine performance. Material certificates and positive
material identification should be tied to the component drawing.
### 6.6 Coatings, surface treatments, and claddings
Coatings can increase surface hardness or corrosion resistance while
retaining a tough structural substrate. Candidate technologies include
physical vapor deposited nitrides, high velocity oxy fuel coatings, weld
overlays, laser cladding, nitriding, shot peening, and engineered
surface remelting. A recent study of CrN coated 316L illustrates that
coating architecture can improve comparative cavitation behavior, but
the result depends on adhesion, residual stress, porosity, substrate
support, and the test environment [25].
A coating qualification should include:
- substrate grade, heat treatment, and surface preparation;
- coating composition, thickness, hardness, porosity, and residual
stress;
- adhesion and edge condition;
- cavitation test before and after chemical exposure;
- thermal cycle and clean in place compatibility;
- inspection method for pinholes, cracks, and delamination;
- permitted particle or metal release;
- repair procedure and dimensional effect.
A very hard thin coating on a compliant substrate can crack when
repeated pressure pulses deform the substrate. A thick sprayed coating
can contain pores and reduce a small hydraulic clearance. Coating a
sharp orifice edge can change its radius and discharge coefficient. The
final hydraulic geometry should therefore be measured after coating.
### 6.7 Ceramics and cermets
Technical ceramics and cermets offer high hardness and corrosion
resistance but are sensitive to tensile stress, impact defects, thermal
shock, and attachment details. They are better suited to compressively
supported inserts, sleeves, nozzles, or tiles than to complex
unsupported pressure boundaries. A ceramic insert should have generous
radii, controlled interference or compliant support, and protection
against assembly impact. The consequences of fragment release must be
considered for food, pharmaceutical, turbine, membrane, and precision
downstream equipment.
Tungsten carbide and chromium carbide systems may be used as bulk
inserts or sprayed coatings, but binder chemistry and galvanic behavior
must match the process. Hardness alone does not guarantee cavitation
life because binder removal, pore attack, and brittle grain pullout can
control failure.
### 6.8 Elastomers, polymers, seals, and bearings
Elastomer selection is governed by the complete fluid mixture,
temperature, pressure, cleaning chemicals, oxidants, solvent swelling,
gas decompression, and regulatory status. EPDM, FKM, FFKM, nitrile,
silicone, and PTFE based materials have distinct compatibility
envelopes; no generic ranking is valid for all cavitation applications.
Compatibility should be confirmed using supplier data and immersion or
compression testing in the actual process and cleaning fluids.
Seals should be located away from the strongest collapse zone and
pressure pulsation where possible. A dynamic seal calculation should
include chamber pressure, shaft speed, heat generation, face loading,
flush plan, solids, gas, and dry running risk. Double mechanical seals
or barrier systems may be required when product containment, air
exclusion, or hazardous chemistry governs. Bearings should be isolated
from process liquid unless they are specifically designed as product
lubricated components.
Thermoplastics can be useful for transparent development chambers, low
pressure inserts, or corrosion isolation, but pressure rating, creep,
solvent compatibility, temperature, ultraviolet exposure, and brittle
fracture must be checked. A transparent chamber used for visualization
should have a protective enclosure and a defined service life.
### 6.9 Hygienic and cleanable construction
Food and pharmaceutical devices should use cleanable geometry,
compatible product contact materials, controlled surface finish,
drainability, and validated cleaning. Inline rotor stator equipment may
be evaluated against applicable 3-A requirements, but the owner remains
responsible for the complete installation, including piping, seals,
instrumentation, and cleaning cycle [22].
Important design details include:
- continuous welds with controlled penetration and ground or polished
product surfaces where required;
- no gasket intrusion into the flow path;
- elimination of dead legs and unvented high points;
- drainable housings and sample ports;
- accessible or validated internal cavities;
- surface finish measurement after fabrication and repair;
- avoidance of threaded product contact joints unless specifically
accepted;
- material and elastomer traceability;
- verification that wear debris cannot exceed product contamination
limits.
Cavitation can increase cleaning action locally but does not prove that
every surface receives chemical concentration, temperature, velocity,
and time sufficient for cleaning. A clean in place study should use
riboflavin, conductivity, temperature mapping, swabs, microbiology, or
another validated method appropriate to the process.
### 6.10 Welds, residual stress, and fabrication quality
Weld toes, undercut, incomplete penetration, porosity, inclusions,
abrupt section changes, and rough repairs can become preferred sites for
cavitation attack or corrosion. Welding also changes microstructure and
residual stress. Pressure boundary welds require qualified procedures,
welder qualification, examination, and code acceptance. Wetted welds may
require grinding, polishing, passivation, pickling, or electropolishing
depending on alloy and service.
For duplex stainless steels, heat input and interpass temperature affect
phase balance and corrosion performance. For precipitation hardening or
martensitic grades, welding and postweld heat treatment can alter
strength and corrosion resistance. For hardfacing and cladding, dilution
and cracking must be controlled. Fabrication records should therefore be
part of the material selection calculation package, not a separate
purchasing detail.
### 6.11 Inspection, monitoring, and lifecycle acceptance
Inspection should concentrate on predicted collapse zones and high
stress regions. A post fabrication baseline should include dimensional
measurement, surface photography, mass of removable inserts, ultrasonic
thickness where applicable, rotor balance, vibration, and surface
finish. Initial follow up intervals should be conservative and may be
extended only after a stable wear trend has been demonstrated.
*Table 6.2. Inspection methods by component and damage mechanism.*
| **Component or concern** | **Baseline measurement** | **In service indicator** | **Outage inspection** |
|--------------------------|----------------------------------------|--------------------------------------|----------------------------------------------------|
| Orifice or throat | Diameter, edge radius, curve | Drift in flow pressure relation | Optical metrology, replica, mass or profile loss |
| Collapse chamber | Thickness map, surface photograph | Metal concentration, acoustic change | UT grid, 3D scan, dye penetrant where appropriate |
| Rotor | Dimensions, balance, runout, vibration | Vibration and power trend | NDE, mass, balance, crack and erosion inspection |
| Stator and pins | Clearance and feature geometry | Torque or pressure drift | Coordinate measurement, surface inspection |
| Coating | Thickness, adhesion, defect map | Metal or particle release | Microscopy, holiday or adhesion test as applicable |
| Pressure shell | Code examination and pressure test | Leak, strain, pressure cycle count | UT, surface NDE, weld examination |
| Seal and bearings | Leakage, temperature, vibration | Trend alarms | Face, sleeve, bearing and lubricant inspection |
An acceptance criterion should specify maximum dimensional change,
maximum local penetration, maximum vibration, allowable metal
concentration, minimum remaining pressure thickness, rotor balance
tolerance, and product quality limits. Replacement should be based on
the governing criterion rather than waiting for leakage or catastrophic
loss of geometry.
### 6.12 Material selection decision record
The material decision should be recorded in a table that connects
service environment, failure mode, selected material, protective
feature, inspection, and spare strategy.
*Table 6.3. Example material decision record.*
| **Component** | **Service and dominant risk** | **Selected construction** | **Design control** | **Verification** |
|------------------|----------------------------------------------------|-----------------------------------------------------------------------|----------------------------------------------------------|--------------------------------------------------------|
| Pressure housing | Internal pressure, chloride bearing aqueous liquid | Code listed corrosion resistant alloy | Code thickness, corrosion allowance, qualified welds | Material certificates, NDE, pressure test, UT baseline |
| Orifice insert | High local velocity and edge erosion | Hardened or coated replaceable insert compatible with product | Positive location, minimum ligament, measured final edge | Flow calibration, dimensional inspection, spare insert |
| Collapse liner | Cloud collapse and metal release limit | Replaceable corrosion resistant wear sleeve | Move collapse away from pressure shell | Mass and 3D profile at defined intervals |
| Rotor | Centrifugal stress, fatigue, cavitation, balance | High strength corrosion resistant alloy with qualified heat treatment | Overspeed and fatigue analysis, generous radii | Material traceability, NDE, balance, vibration trend |
| Stator | Gap integrity and erosion | Tough corrosion resistant alloy or replaceable ring | Clearance budget and anti-galling pair | Gap measurement and contact inspection |
| Seal | Chemistry, speed, gas, cleaning | Supplier qualified face and elastomer combination | Flush or barrier plan, temperature monitoring | Leak test, compatibility record, planned replacement |
The decision record should be revised when process chemistry, cleaning
agent, operating temperature, pressure, speed, solids, or allowable
contamination changes. A successful material in a water trial cannot be
assumed suitable for a chloride, oxidant, acid, caustic, solvent, or
abrasive slurry without additional evidence.
## 7 Integrated Design, Scale Up, and Commissioning Procedure
The calculation of a cavitation device should culminate in an integrated
operating envelope rather than a single design point. Flow, inlet
pressure, backpressure, temperature, speed, gas content, viscosity,
solids loading, and number of passes interact. The acceptable operating
region is the intersection of cavitation performance, product response,
power, temperature, mechanical integrity, cleanability, and material
loss constraints.
### 7.1 Calculation sequence
A complete design sequence is as follows:
**Define the process objective.** State the required transformation and
quantitative acceptance variables, including distributions rather than
only averages where relevant.
**Define the feed envelope.** Tabulate density, viscosity or rheology,
vapor pressure, gas condition, solids, surface tension, corrosive
species, and temperature at minimum, normal, and maximum conditions.
**Define the system boundary.** Identify whether power is hydraulic,
shaft, or electrical; whether energy is reported per pass, per batch,
per unit mass, or per product output; and whether the pump is included.
**Select the cavitation mechanism.** Choose a restriction, Venturi,
wake, multistage arrangement, vortex chamber, or dynamic rotor according
to flow, passage size, control range, cleanability, and maintenance.
Complete the preliminary hydraulic calculation. Determine areas,
velocities, , , , pressure profile, , residence
time, power, and expected recovery location.
**Complete the mechanical screen.** Calculate pressure boundary demand,
rotor stress where applicable, clearance, torque, supports, thermal
growth, and pressure cycle or speed cycle requirements.
**Allocate materials by function.** Separate pressure boundary, wear
insert, collapse liner, rotor, stator, seal, and product contact
requirements.
Calibrate the equipment coefficients. Measure , recovery
coefficient, , , and other geometry specific quantities on
the actual or a rigorously similar unit.
**Map cavitation and process response.** Vary pressure drop or speed,
flow, backpressure, temperature, gas, and passes. Record both hydraulic
state and product response.
**Validate the uncertain model.** Use CFD, visualization, dynamic
pressure, acoustic data, tracer tests, or wear coupons according to the
unresolved design question.
**Run an endurance test.** Confirm power, temperature, vibration,
erosion, corrosion, fouling, cleanability, and product contamination.
**Freeze the operating envelope and inspection interval.** Define
controls, alarms, dimensional limits, spare parts, and recalibration
after wear or maintenance.
### 7.2 Operating map
A useful operating map contains, at minimum, flow on one axis and
pressure drop or rotational speed on the other. Contours or labels
identify:
- no or weak cavitation;
- inception and intermittent cavities;
- developed useful operating region;
- connected or supercavitating region where collapse may be displaced;
- excessive temperature rise;
- power or torque limit;
- vibration or noise limit;
- product quality acceptance region;
- erosion or contamination limit.
The optimum operating condition is application specific. The largest
visible vapor cloud does not necessarily correspond to maximum reaction
rate, breakup, disinfection, or energy efficiency. A stable connected
cavity can reduce the number of discrete collapse events, whereas
excessive backpressure can suppress useful cavity growth. The operating
map should therefore be defined by the measured process objective
[2–10].
### 7.3 Heat balance
Most mechanical and hydraulic energy eventually appears as heat unless
it leaves as pressure energy, shaft work, chemical free energy, phase
change, acoustic radiation, or kinetic energy. The approximate adiabatic
temperature rise over a treatment is:
(7.1)
where is mass specific energy converted to internal energy and
is specific heat capacity. For water, 1 kJ/kg corresponds to
approximately 0.24 K if all energy becomes sensible heat. In a
recirculation loop, cumulative temperature rise changes vapor pressure
and viscosity and can move the device into a different cavitation
regime. Temperature must therefore be controlled or incorporated into
the operating map.
For a steady cooled loop, the required heat removal rate is
approximately:
(7.2)
where represents desired enthalpy carried by
product and represents other energy leaving the boundary.
In most nonthermal applications, the cooling duty is close to net
electrical input after external motor and drive losses are accounted
for.
### 7.4 Pump and system matching for static devices
The operating point of a pump driven cavitator is the intersection of
the pump curve and system curve. For a system with static head and
approximately quadratic losses,
(7.3)
where includes the cavitator, piping, valves, heat exchanger,
and fittings at the stated fluid properties. A variable frequency drive
changes the pump curve and can provide flow control, but reducing speed
also changes available pressure. A downstream control valve can set
backpressure, yet it must not become an uncontrolled cavitation source.
The pump suction calculation should use the lowest liquid level, highest
temperature, greatest suction line loss, and maximum gas condition. The
process device is intended to cavitate; the pump inlet is not. Pump
cavitation changes flow, pressure, vibration, and power and invalidates
the device calculation.
### 7.5 Acceptance calculations
The design acceptance report should reconcile measured and calculated
quantities. A normalized deviation is:
(7.4)
for each quantity , such as flow, pressure drop, shaft power,
electrical power, temperature rise, or product response. Acceptance
limits should reflect measurement uncertainty and model purpose. A 3%
flow deviation may be important for a narrow multihole operating point,
while a larger deviation may be acceptable in an early concept screen.
*Table 7.1. Integrated calculation and commissioning record.*
| **Topic** | **Calculated or specified value** | **Measured value** | **Uncertainty** | **Acceptance criterion** | **Status** |
|-----------------------------------------|-----------------------------------|--------------------|-----------------|--------------------------|------------|
| Flow rate and turndown | | | | | |
| Inlet and outlet absolute pressure | | | | | |
| Pressure drop or rotor speed | | | | | |
| Minimum pressure or inception indicator | | | | | |
| Hydraulic, shaft, and electrical power | | | | | |
| Specific energy | | | | | |
| Temperature rise and cooling duty | | | | | |
| Product quality attributes | | | | | |
| Vibration or acoustic signature | | | | | |
| Dimensional wear and metal release | | | | | |
| Cleaning and drainability | | | | | |
### 7.6 Summary of worked calculations
*Table 7.2. Comparison of the four examples worked.*
| **Device** | **Primary design variable** | **Calculated operating result** | **Principal calibration need** |
|--------------------|---------------------------------------------------|----------------------------------------------------------------------------------|-----------------------------------------------------------------------|
| Eight hole orifice | Total open area from , , and | Eight 3.81 mm holes; 15.21 m/s nominal jet; 0.417 kW hydraulic power | Actual , vena contracta pressure, jet interaction and erosion |
| Venturi | Throat area from target minimum pressure | 10.86 mm ideal throat at 10 m³/h; diffuser length 0.092 to 0.280 m for 12° to 4° | Two phase throat pressure, diffuser recovery and cavity length |
| Vortex chamber | Circulation and finite core radius | m²/s for the selected radii and pressure | Relation between inlet momentum and circulation; vapor core model |
| Rotor stator | Tip speed and calibrated power number | 28.35 m/s; 5.50 kW; 18.4 N·m; 570 Hz passage frequency | , local pressure, clearance effects, vapor fraction and endurance |
## 8 Conclusions
Hydrodynamic cavitation device design requires a hierarchy of models.
Continuity, energy balance, dimensionless groups, and calibrated
coefficients provide transparent preliminary sizing and establish flow
area, velocity, pressure drop, power, residence time, and mechanical
demand. These calculations do not independently predict cavity cloud
structure, collapse distribution, process conversion, or service life.
For static flow through devices, total open area is only the initial
geometric parameter. Hole number, thickness, edge condition, ligament,
downstream chamber geometry, pressure tap location, and recovery
behavior determine the active pressure history. Venturi calculations
must include throat length and diffuser recovery in addition to throat
diameter. Multistage devices require stage by stage pressure accounting
rather than an assumed equal loss distribution.
For vortex devices, radial equilibrium explains how tangential velocity
produces a low pressure core, but the free vortex model must be limited
by a finite core and replaced by a two phase model once the calculated
pressure reaches vapor pressure. Circulation, core radius, outlet
geometry, aspect ratio, and device scale require calibration. Parallel
scale out can preserve a validated core structure more reliably than
simple geometric enlargement.
For dynamic devices, tip speed, rotational Reynolds number, rotor
cavitation number, flow coefficient, power number, clearance ratio, and
feature passage frequency form a coupled similarity set. Because power
is strongly dependent on speed and diameter, a calibrated power number
should not be transferred to a new geometry or flow regime without
verification. Rotor stress, fatigue, thermal growth, balance, vibration,
seals, and wear are integral design variables.
Structural material selection should separate pressure containment from
cavitation wear. A durable design intentionally locates collapse,
provides replaceable inserts or liners, preserves cleanable geometry,
and establishes inspection and contamination limits. ASTM G32 and
coating studies support comparative screening, but plant service life
must be established by representative flow testing and pilot inspection.
Final pressure vessel and piping design must comply with the applicable
codes.
A validated design is therefore an operating envelope supported by
measured flow, absolute pressure, power, temperature, cavity signature,
product response, and equipment condition. Cavitation number is one
coordinate within that envelope rather than a complete design criterion.
## Nomenclature
Unless otherwise stated, quantities are expressed in SI units.
Subscripts identify the relevant station, component, or reference
condition.
| **Symbol** | **Definition** | **SI unit or status** |
|--------------------------------------------------------------------------|----------------------------------------------------------------------|-----------------------------------------|
| | Cross sectional area | m² |
| | Projected bluff body area | m² |
| | Exposed erosion test area | m² |
| | Area of one tangential inlet | m² |
| | Total open area of an orifice or multihole insert | m² |
| | Pipe cross sectional area | m² |
| | Venturi throat area | m² |
| | Vena contracta area | m² |
| | Chamber aspect ratio | dimensionless |
| | Bluff body blockage ratio | dimensionless |
| | Contraction coefficient | dimensionless |
| | Discharge coefficient | dimensionless |
| | Pressure recovery coefficient | dimensionless |
| | Pressure drop cavitation index defined by Equation (2.9) | dimensionless |
| | Coefficient of variation of parallel module flow | dimensionless |
| | Speed of sound in liquid | m/s |
| | Specific heat capacity | J/(kg·K) |
| | Corrosion allowance | m |
| | Erosion allowance | m |
| | Machining or resurfacing allowance | m |
| , | Stated characteristic or chamber diameter | m |
| , | Upstream and downstream diameters | m |
| | Hydraulic diameter | m |
| | Pipe internal diameter | m |
| | Rotor diameter | m |
| | Bluff body characteristic dimension | m |
| | Equivalent circular diameter of total open area | m |
| | Diameter of one orifice hole | m |
| | Venturi throat diameter | m |
| | Weld joint efficiency in pressure wall screen | dimensionless |
| | Euler number or pressure loss coefficient | dimensionless |
| | Vortex device Euler number | dimensionless |
| | Mass specific electrical energy | J/kg or kWh/t |
| | Single pass hydraulic specific energy | J/kg |
| | Single pass shaft specific energy | J/kg |
| | Wake shedding frequency | Hz |
| | Rotor feature passage frequency | Hz |
| | Gravitational acceleration | m/s² |
| | Rotor stator clearance | m |
| | Minimum required running clearance | m |
| | Vortex chamber height or axial length | m |
| | Irreversible head loss | m |
| | Pump head added within the control volume | m |
| | Maximum permitted local penetration | m |
| | Measured local penetration | m |
| | System curve coefficient | Pa·s²/m⁶ for the form in Equation (7.3) |
| | Calibrated vortex device capacity coefficient | dimensionless for the stated form |
| | Estimated convective collapse distance | m |
| | Diffuser length | m |
| | Restriction t -target standoff or stage spacing | m |
| | Rotor tip Mach number | dimensionless |
| | Mean depth of erosion | m |
| | Negative mill tolerance fraction used in nominal thickness selection | dimensionless |
| | Mass of liquid or product assigned to a treatment energy | kg |
| | Mass flow rate | kg/s |
| | Mean depth penetration rate | m/s or mm/h |
| | Number of equal orifice holes | integer |
| | Number of tangential inlets | integer |
| | Number of parallel modules | integer |
| | Number of cavitation stages | integer |
| | Nominal loop turnovers | dimensionless |
| | Rotational speed | rpm |
| | Rotational speed | s⁻¹ |
| | Absolute static pressure unless otherwise stated | Pa |
| , | Upstream and downstream absolute pressures | Pa |
| | Absolute pressure | Pa |
| | Local atmospheric pressure | Pa |
| | Defined chamber or bulk pressure for rotor calculation | Pa |
| | Vortex core pressure | Pa |
| | Gauge pressure | Pa |
| | Local minimum pressure | Pa |
| | Outer radius reference pressure in vortex model | Pa |
| | Pressure in intended recovery region | Pa |
| | Venturi throat pressure | Pa |
| | Vapor pressure at local temperature | Pa |
| | Power assigned to the active cavitation volume | W |
| | Electrical input power | W |
| | Hydraulic power | W |
| | Shaft power | W |
| | Other power leaving the selected heat balance boundary | W |
| | Wetted perimeter | m |
| | Power number | dimensionless |
| | Volumetric flow rate | m³/s |
| | Flow through parallel module | m³/s |
| | Total flow through parallel modules | m³/s |
| | Heat removal rate | W |
| | Initial cavity radius in collapse time screen | m |
| | Reynolds number | dimensionless |
| | Orifice hole Reynolds number | dimensionless |
| | Rotational Reynolds number | dimensionless |
| | Radius from vortex axis | m |
| | Finite vortex core radius | m |
| | Outer radius used in vortex pressure model | m |
| | Allowable material stress in pressure wall screen | Pa |
| | Strouhal number | dimensionless |
| | Defined tangential to axial velocity ratio | dimensionless |
| | Standard deviation of parallel branch flows | m³/s |
| | Shaft torque | N·m |
| | Time | s |
| | Rayleigh inertial collapse time | s |
| | Code required pressure thickness | m |
| | Selected nominal thickness | m |
| | Plate or insert thickness | m |
| | Screened remaining service time | s or h |
| | Simplified pressure wall thickness | m |
| | Product specific enthalpy change across the heat balance boundary | J/kg |
| | Rotor tip speed | m/s |
| , | Standard uncertainty of result or input | units of the associated quantity |
| , | Mean velocity | m/s |
| , | Mean velocity at stations 1 and 2 | m/s |
| | Defined active cavitation volume | m³ |
| | Representative convection velocity in collapse distance estimate | m/s |
| | Device hold up volume | m³ |
| | Tangential inlet velocity | m/s |
| | Nominal jet velocity based on physical open area | m/s |
| | Loop or tank liquid volume | m³ |
| | Venturi throat velocity | m/s |
| | Vena contracta velocity | m/s |
| | Tangential velocity | m/s |
| | Mean flow among parallel branches | m³/s |
| | Weber number | dimensionless |
| | Mechanical cavitation loss | mass, depth, or rate as stated |
| | Corrosion loss without cavitation | mass, depth, or rate as stated |
| | Erosion corrosion interaction term | mass, depth, or rate as stated |
| | Total combined material loss | mass, depth, or rate as stated |
| | Elevation | m |
| | Number of repeating rotor features | integer |
### Greek Letters
| **Greek letter** | **Name** | **Definition** | **SI unit or status** |
|--------------------------|----------------|--------------------------------------------------------|------------------------------|
| | alpha | Kinetic energy correction factor | dimensionless |
| | beta | Equivalent open diameter to pipe diameter ratio | dimensionless |
| | beta | Venturi throat to inlet diameter ratio | dimensionless |
| | gamma, capital | Vortex circulation | m²/s |
| | gamma, capital | Circulation at the finite core vapor pressure screen | m²/s |
| | gamma | Surface or interfacial tension | N/m |
| | gamma dot | Approximate rotor stator gap shear rate | s⁻¹ |
| | delta, capital | Finite difference or change in the associated quantity | units of associated quantity |
| | delta | Normalized measured to calculated deviation | % |
| | epsilon | Defined active zone power density | W/m³ |
| | eta | Drive or transmission efficiency | dimensionless |
| | eta | Motor efficiency | dimensionless |
| | eta | Pump efficiency | dimensionless |
| | theta | Diffuser half angle | rad or degrees |
| | mu | Dynamic viscosity | Pa·s |
| | rho | Liquid density | kg/m³ |
| | rho | Solid or rotor material density | kg/m³ |
| | sigma | Cavitation number | dimensionless |
| | sigma | Rotor based cavitation number | dimensionless |
| | sigma | Circumferential stress in thin ring screen | Pa |
| | tau | Nominal device residence time | s |
| | phi | Rotor flow coefficient | dimensionless |
| | phi | Total open area fraction | dimensionless |
| | psi | Rotor pressure or head coefficient | dimensionless |
| | omega | Angular velocity | rad/s |
## Bibliography
[1] Brennen CE. Cavitation and Bubble Dynamics. New York: Oxford
University Press; 1995.
[2] Panda D, Saharan VK, Manickam S. Controlled hydrodynamic
cavitation: a review of recent advances and perspectives for greener
processing. Processes. 2020;8(2):220. doi: 10.3390/pr8020220.
[3] Ranade VV. Modeling of hydrodynamic cavitation reactors:
reflections on present status and path forward. ACS Engineering Au.
2022;2(6):461-476. doi: 10.1021/acsengineeringau.2c00025.
[4] Simpson A, Ranade VV. 110th anniversary: comparison of cavitation
devices based on linear and swirling flows: hydrodynamic
characteristics. Industrial & Engineering Chemistry Research.
2019;58(31):14488-14509. doi: 10.1021/acs.iecr.9b02757.
[5] Sarvothaman VP, Simpson A, Ranade VV. Comparison of hydrodynamic
cavitation devices based on linear and swirling flows: degradation of
dichloroaniline in water. Industrial & Engineering Chemistry Research.
2020;59(30):13841-13847. doi: 10.1021/acs.iecr.0c02125.
[6] Tang P, Juárez JM, Li H. Investigation on the effect of structural
parameters on cavitation characteristics for the Venturi tube using the
CFD method. Water. 2019;11(10):2194. doi: 10.3390/w11102194.
[7] Blagojević M, Rak G, Bizjan B, Kolbl Repinc S. A review on rotary
generators of hydrodynamic cavitation for wastewater treatment and
enhancement of anaerobic digestion. Processes. 2023;11:514. doi:
10.3390/pr11020514.
[8] Thaker AH, Ranade VV. Emulsions using a vortex based cavitation
device: influence of number of passes, pressure drop, and device scale
on droplet size distributions. Industrial & Engineering Chemistry
Research. 2023;62(45):18837-18851. doi: 10.1021/acs.iecr.2c03714.
[9] Gode A, Kourousis K, Ranade VV. Vortex based cavitation devices
for continuous emulsification: influence of device design, scale up, and
scale out. Industrial & Engineering Chemistry Research.
2026;65(15):8081-8101. doi: 10.1021/acs.iecr.6c00278.
[10] Pandey DK, Kumar R, Ranade VV. A simplified droplet breakage
model to simulate continuous emulsification by hydrodynamic cavitation.
ACS Omega. 2026;11(10):16248-16258. doi: 10.1021/acsomega.5c11513.
[11] Kozyuk OV. Method of obtaining a free disperse system in liquid
and device for effecting the same. US Patent 5,810,052. 1998.
[12] Kozyuk OV. Device and method for creating hydrodynamic cavitation
in fluids. US Patent 6,502,979 B1. 2003.
[13] Kozyuk OV. Device and method for creating hydrodynamic cavitation
in fluids. US Patent 7,338,551B2. 2005.
[14] Kozyuk OV. Device and method for creating vortex cavitation in
fluids. US Patent 7,178,975 B2. 2007.
[15] International Organization for Standardization. ISO 5167-1:2022.
Measurement of fluid flow by means of pressure differential devices
inserted in circular cross section conduits running full, Part 1:
General principles and requirements. Geneva: ISO; 2022.
[16] International Organization for Standardization. ISO 5167-2:2022.
Measurement of fluid flow by means of pressure differential devices
inserted in circular cross section conduits running full, Part 2:
Orifice plates. Geneva: ISO; 2022.
[17] Thanekar P, Gogate PR. Application of hydrodynamic cavitation
reactors for treatment of wastewater containing organic pollutants:
intensification using hybrid approaches. Fluids. 2018;3(4):98. doi:
10.3390/fluids3040098.
[18] Christian Thoma. Apparatus and method for mixing dissimilar
fluids. US Patent 7,316,501B2B1. 2004.
[19] SPX FLOW. The APV Cavitator. Product Bulletin 5004-12_2015-US.
Issued February 2016. Supplied promotional brochure.
[20] Hydro Dynamics, Inc. ShockWave Power Reactor product line and
controlled cavitation technology. Vendor product information. Accessed
27 July 2026.
[21] Arisdyne Systems. CFC Controlled Flow Cavitation technology and
commercial equipment. Vendor product information. Accessed 27 July 2026.
[22] 3-A Sanitary Standards, Inc. 3-A Sanitary Standard 36-01: Inline
Rotor Stator Mixers. McLean, Virginia: 3-A SSI. Accessed 27 July 2026.
[23] ASTM International. ASTM G32-16(2021)e1. Standard Test Method for
Cavitation Erosion Using Vibratory Apparatus. West Conshohocken,
Pennsylvania: ASTM International; 2021.
[24] Krella AK. Degradation and protection of materials from
cavitation erosion: a review. Materials. 2023;16(5):2058. doi:
10.3390/ma16052058.
[25] Maurin A. Numerical analysis of cavitation erosion in 316L steel
with CrN PVD coating. Materials. 2024;17(17):4397. doi:
10.3390/ma17174397.
[26] American Society of Mechanical Engineers. ASME B31.3-2024:
Process Piping. New York: ASME; 2024.
[27] American Society of Mechanical Engineers. ASME Boiler and
Pressure Vessel Code, Section VIII, Division 1. 2025 edition. New York:
ASME; 2025.
[28] Michel FC Jr, Kozyuk O. Hydrodynamic cavitation processing. In:
Letcher TM, Scott JL, Patterson DA, editors. Chemical Processes for a
Sustainable Future. Cambridge: Royal Society of Chemistry; 2015. p.
84-142. doi: 10.1039/BK9781849739757-00084.
[29] Fedotkin IM, Kozyuk OV. Cavitation reactor. Soviet Inventor
Certificate SU 1211361 A. 1986.
[30] Kozyuk OV. Use of hydrodynamic cavitation for emulsifying and
homogenizing processes. American Laboratory. 1999;31:6-8.
[31] Kozyuk O. Hydrodynamic Cavitation Technological Equipment. A
selection of images of laboratory and industrial equipment is provided.
2026.
[32] Kozyuk O. Hydrodynamic Cavitation. [Unpublished technical
manuscript and supporting data] 2026.